2026 Annual Workshop
The Clover Lab Annual Workshop 2025-2026 was held in Huizhou, China, from June 23rd to June 25th, 2026.
Workshop Committee
Program Committee Xi WU Zixin TANG Zhelin YANG | Organization Committee Yuchen YAN Xueqian ZHAI |
Program
| June 23 (Tuesday) | |
| 12:00-18:00 | Check In |
| 18:00-20:00 | Dinner |
| June 24 (Wednesday) | |
| 9:00-9:30 | Welcome Remarks Organization Committee |
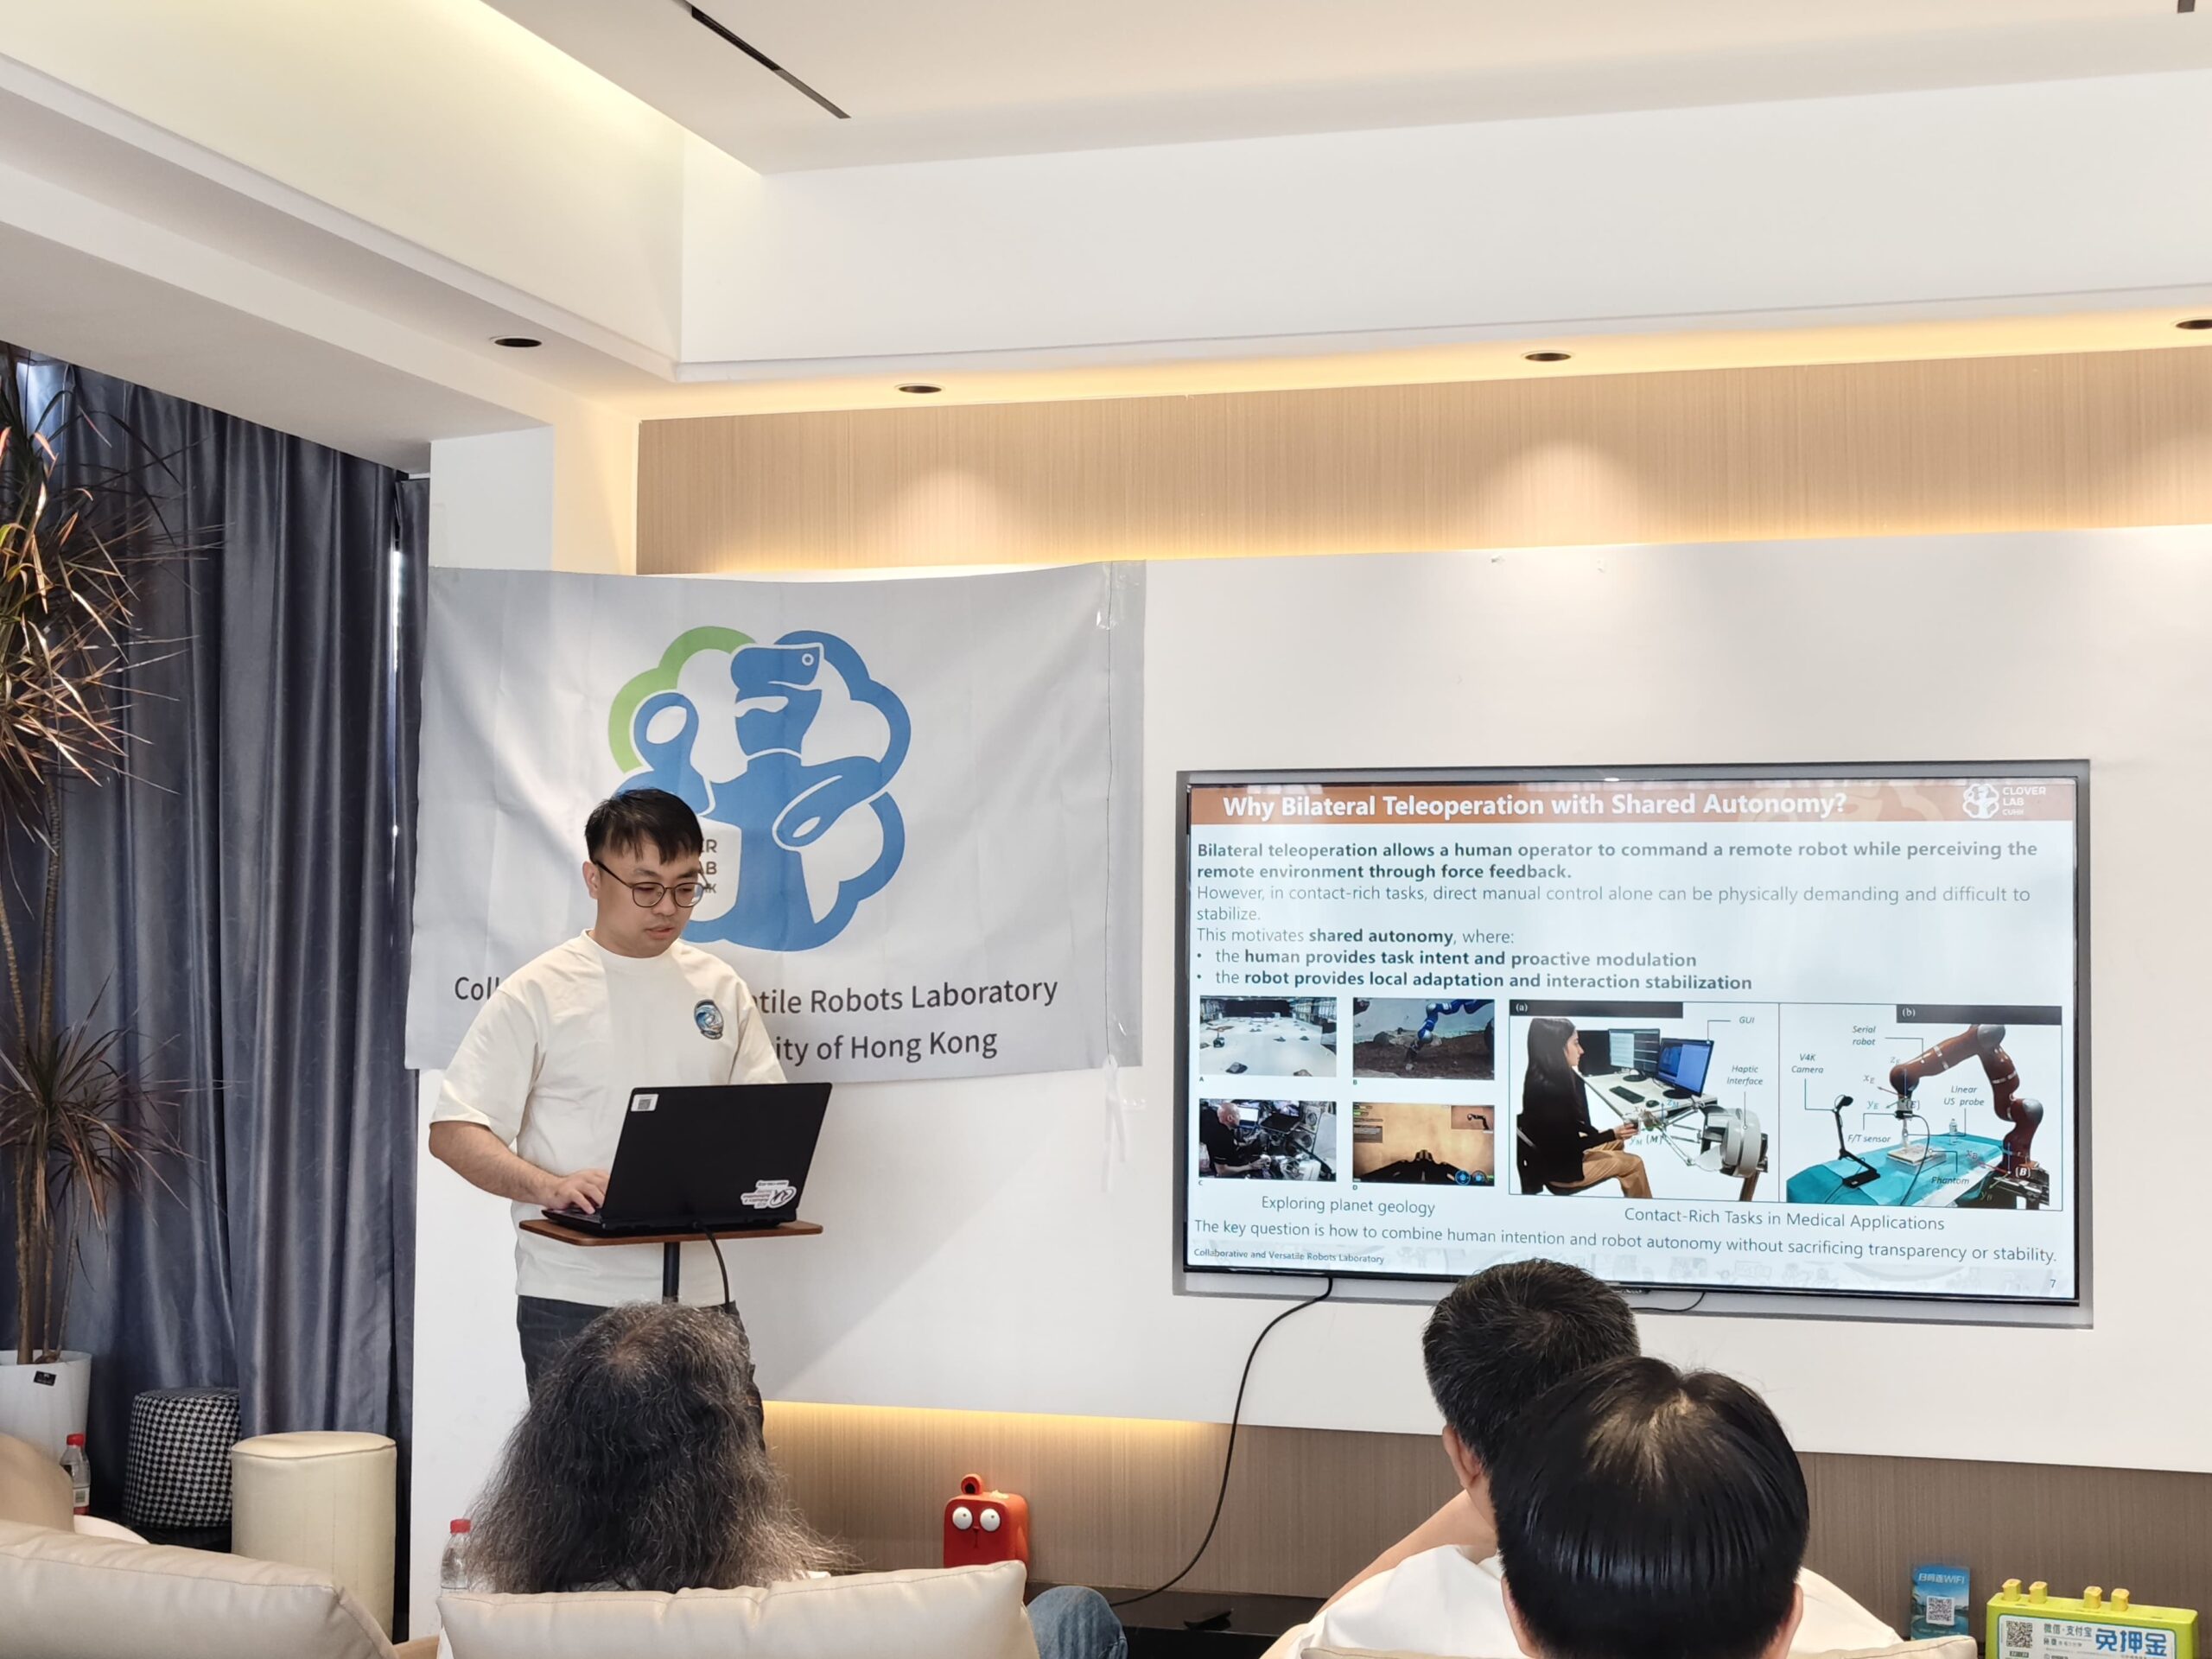
| 9:30-9:45 | Dr. Tao TENG Shared Control/Autonomy: Bilateral Teleoperation under Uncertainty and Interaction Safety |
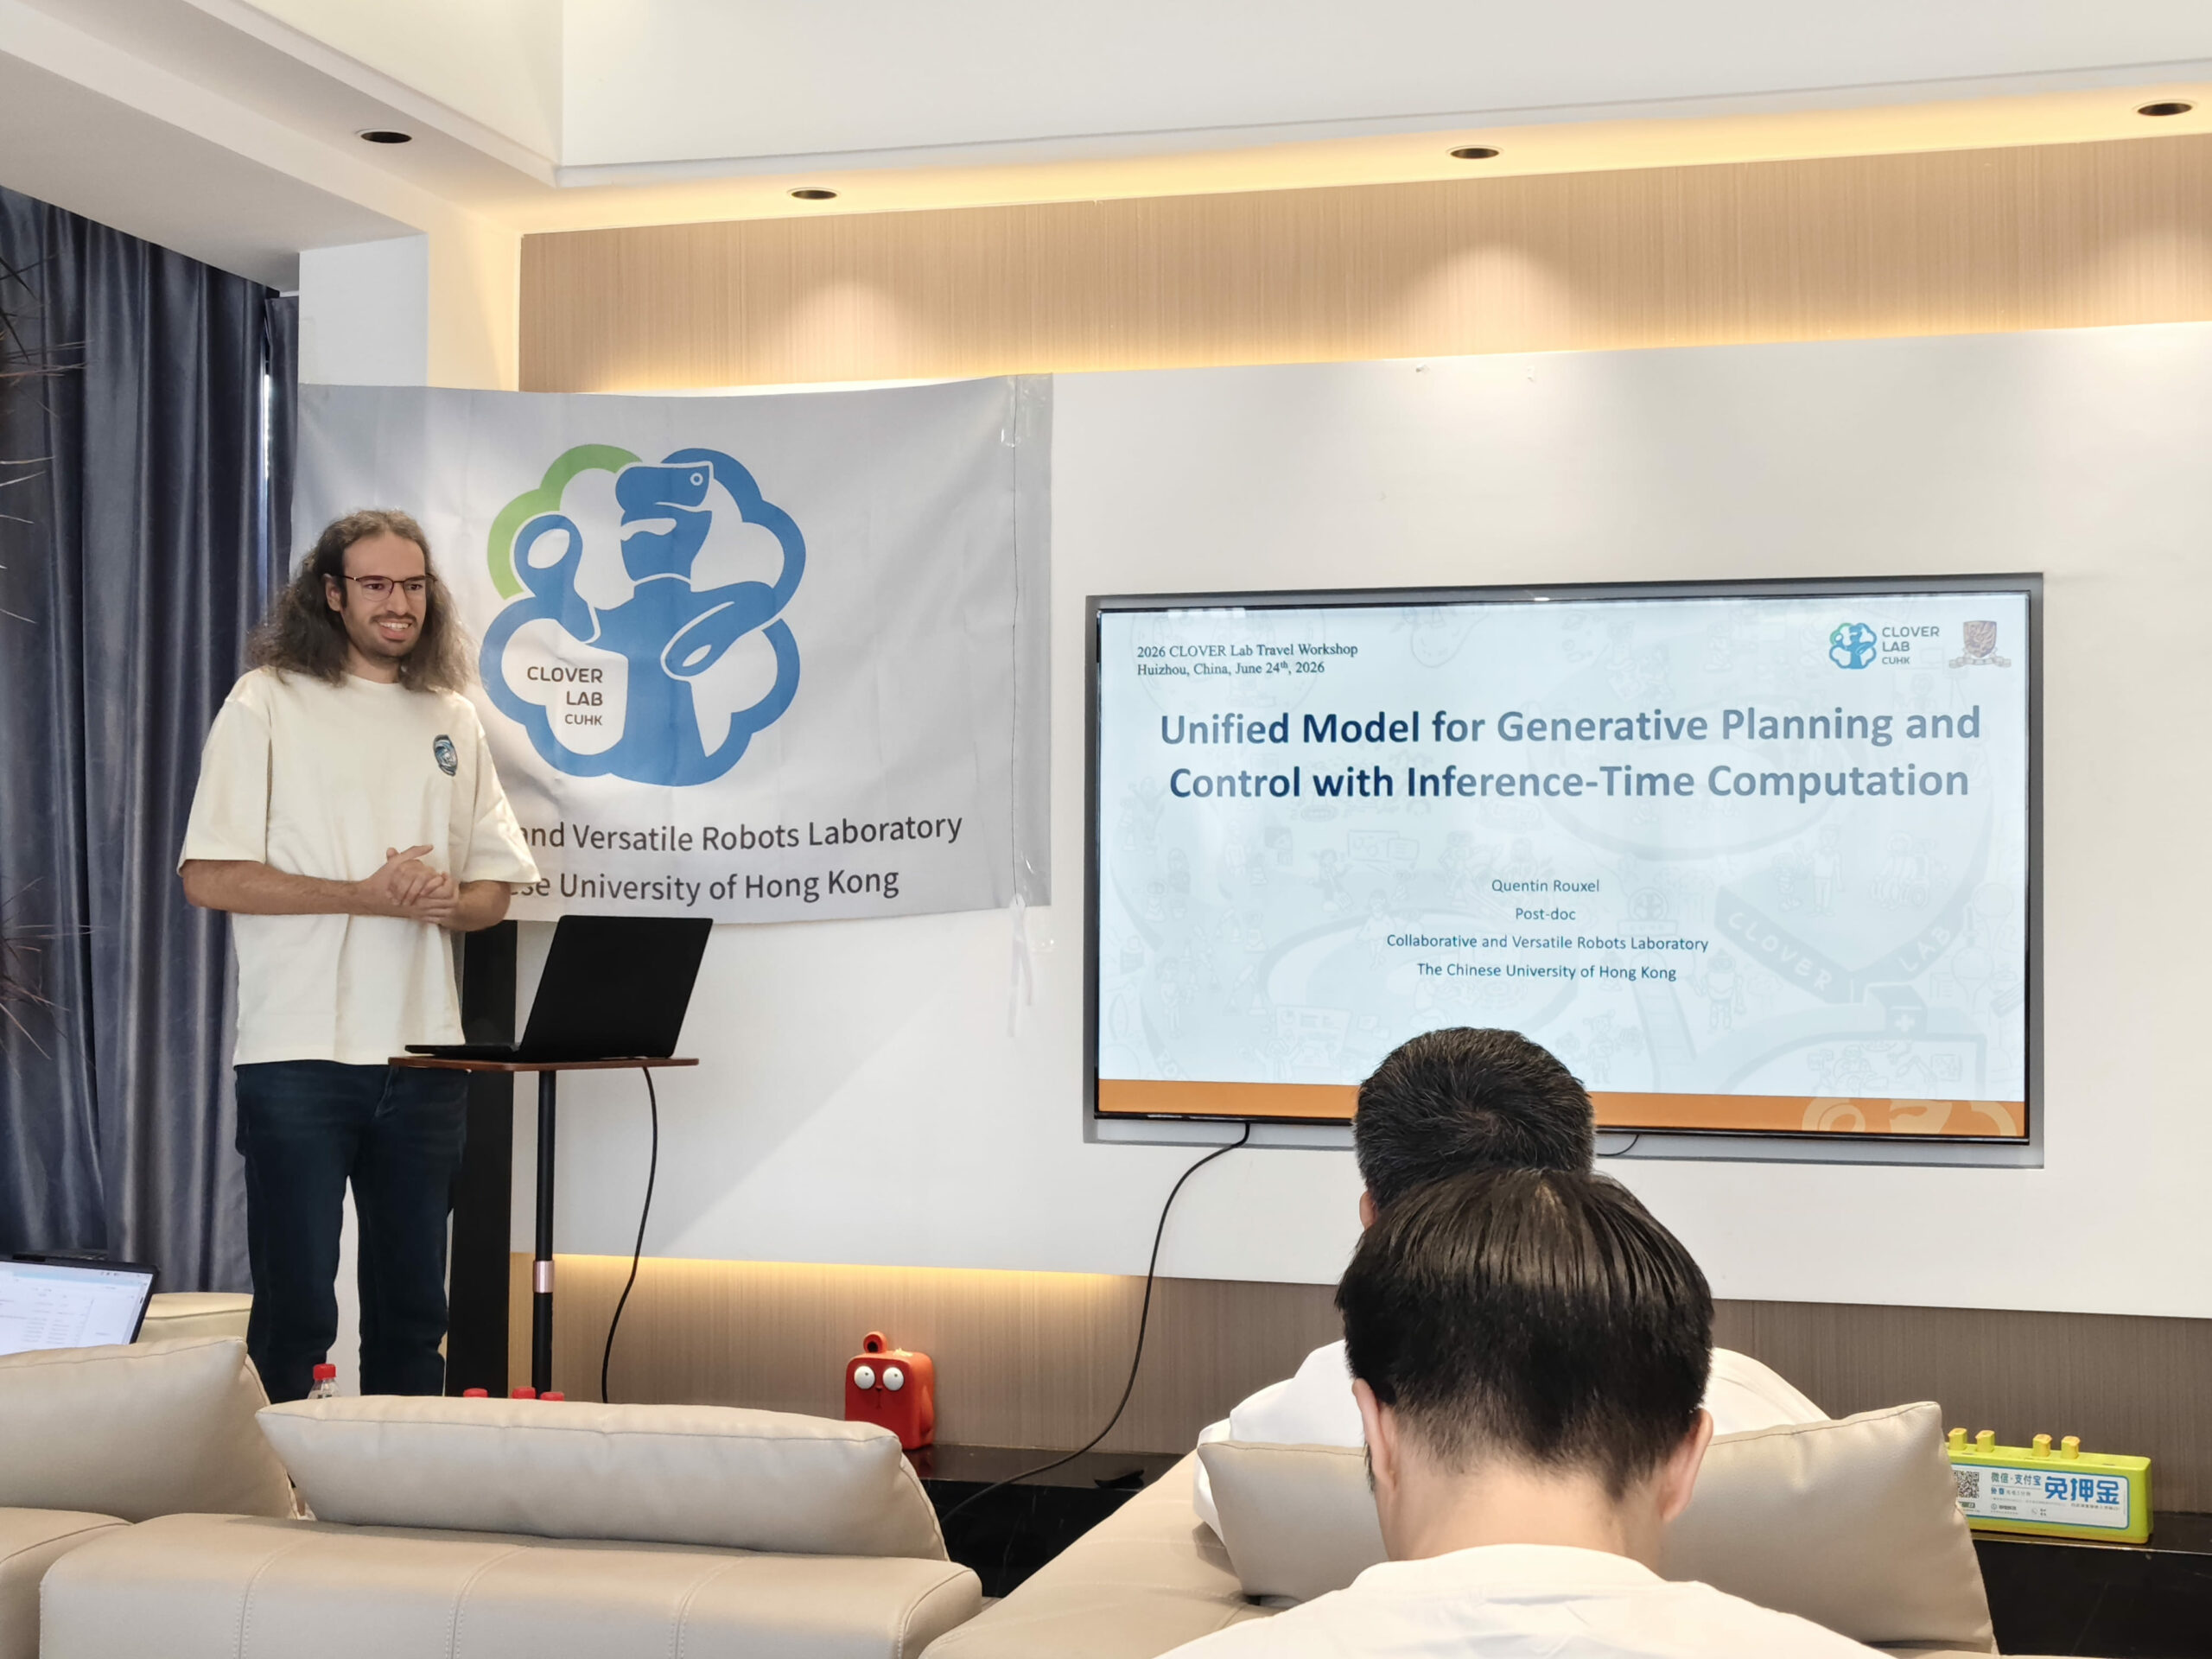
| 9:45-10:00 | Dr. Quentin ROUXEL Unified Model for Generative Planning and Control with Inference-Time Computation |
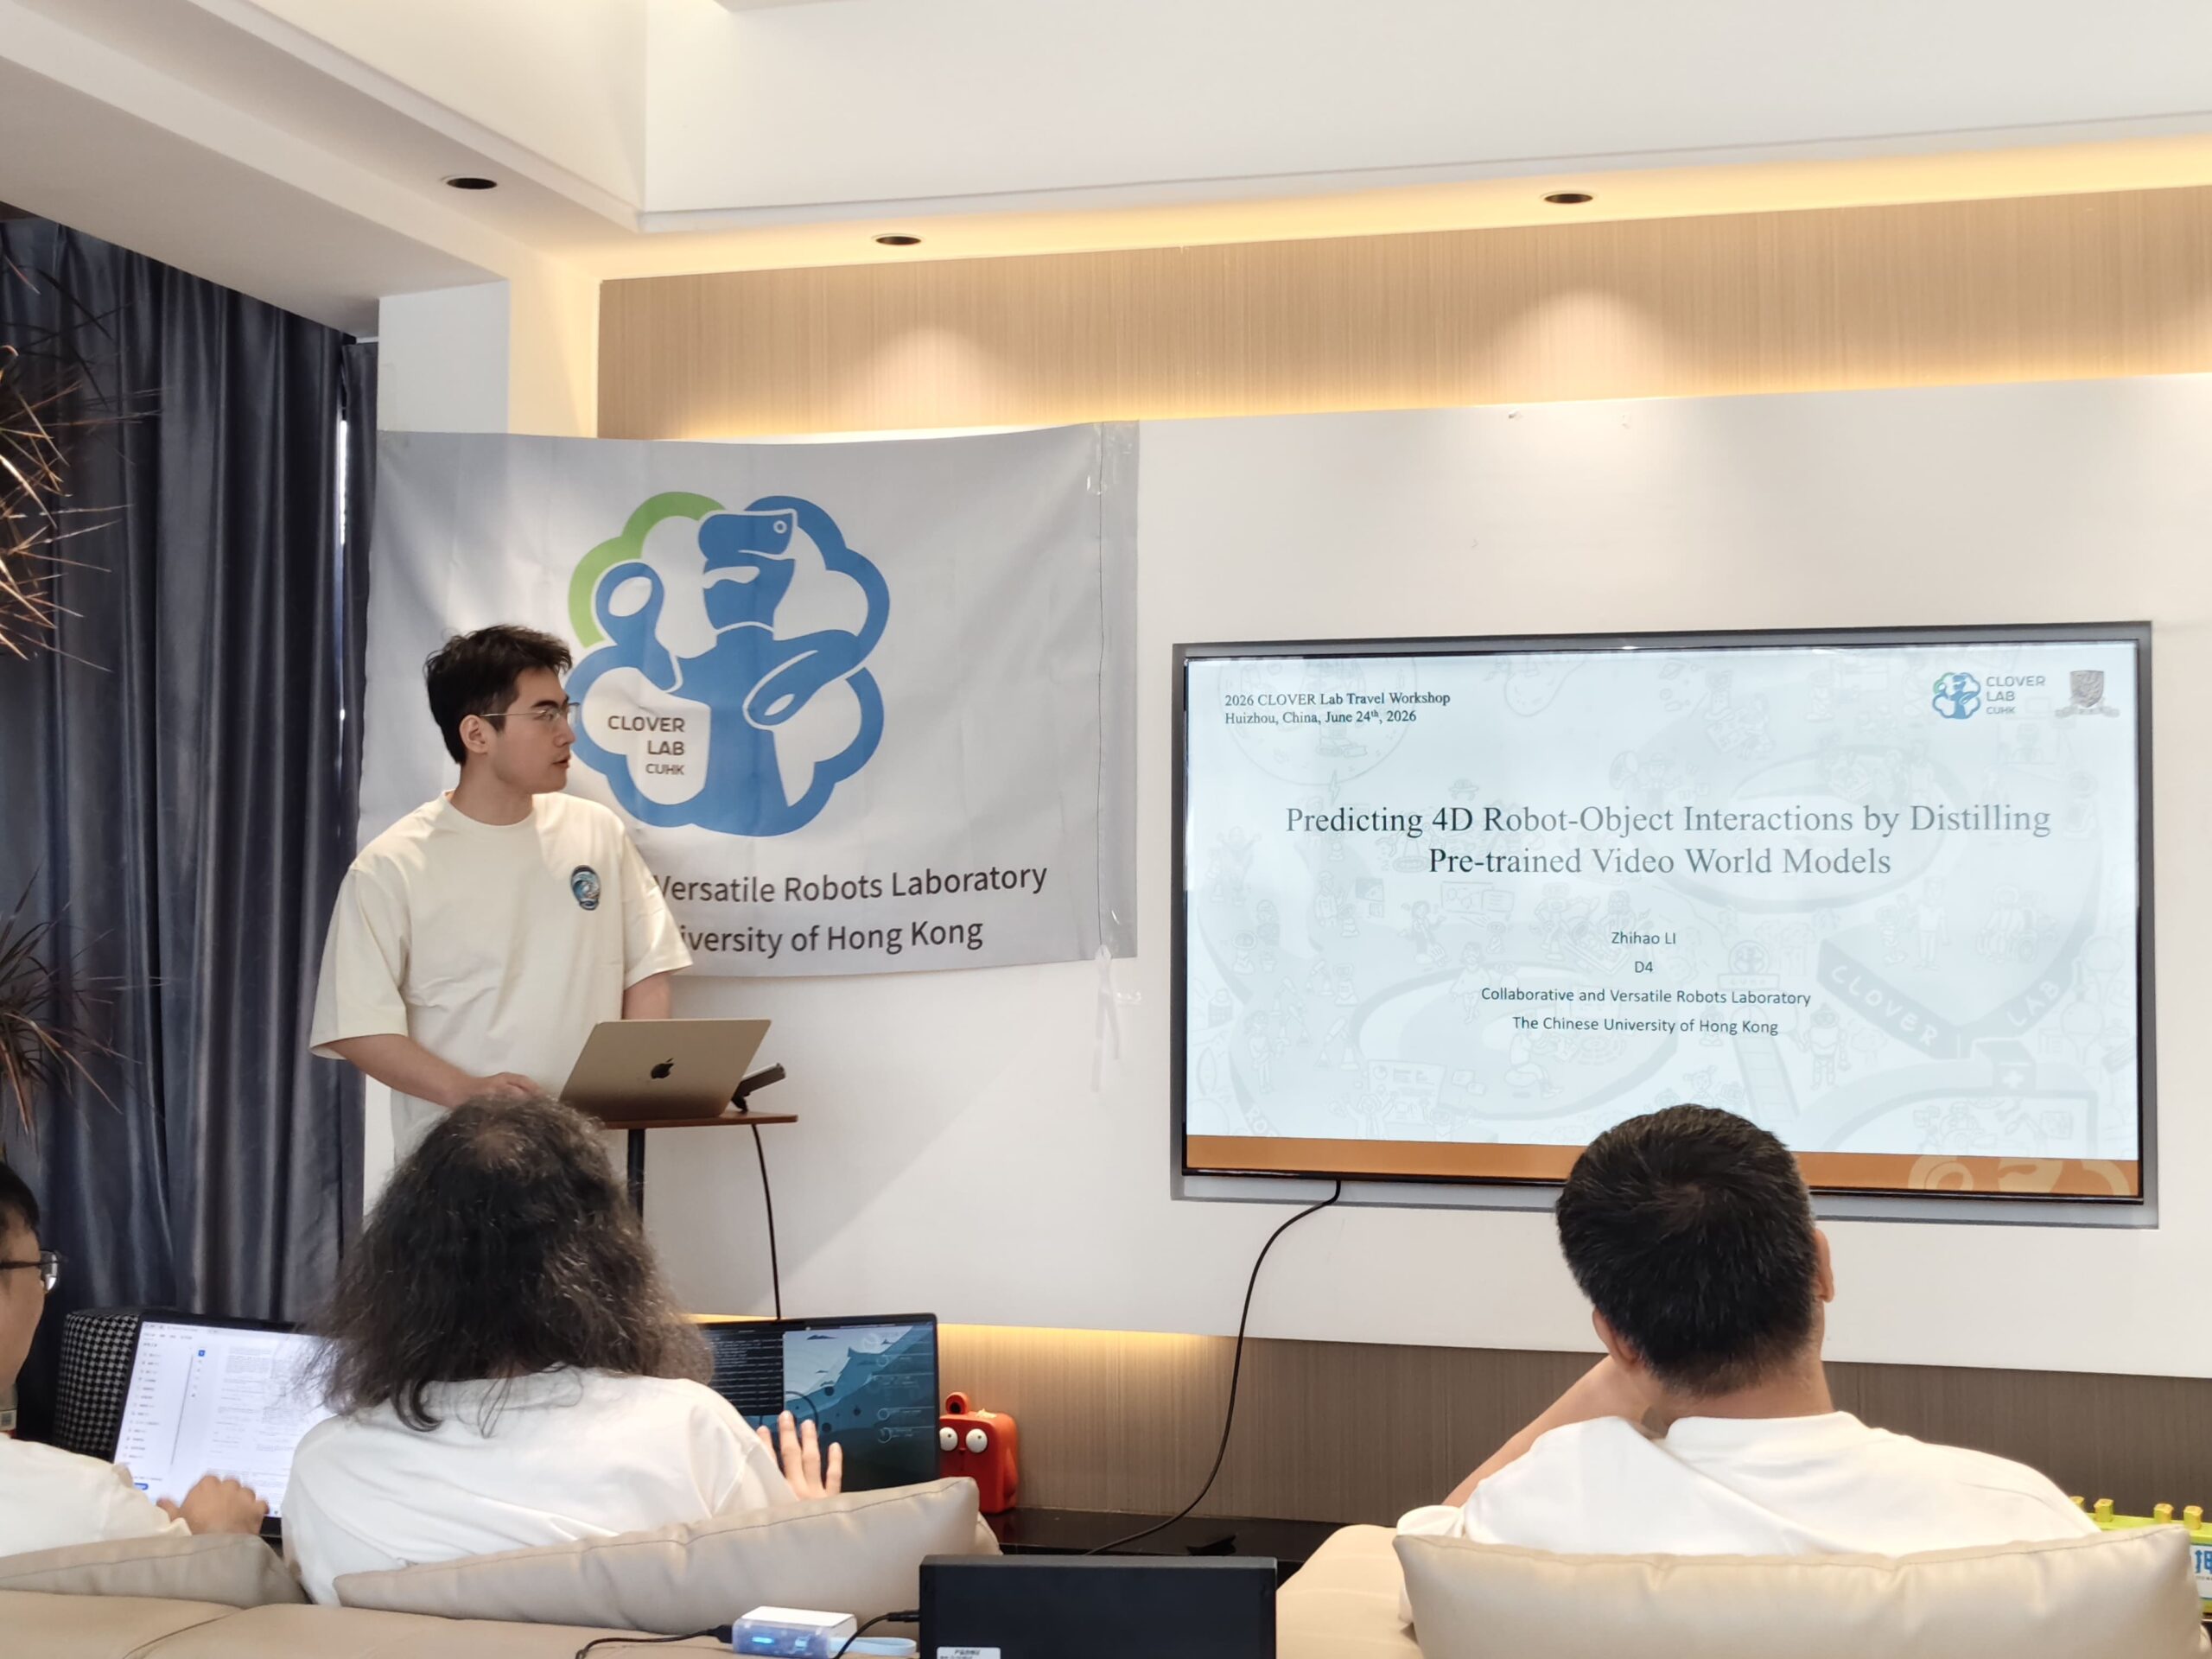
| 10:00-10:15 | Zhihao LI Predicting 4D Robot-Object Interactions by Distilling Pre-trained Video World Models |
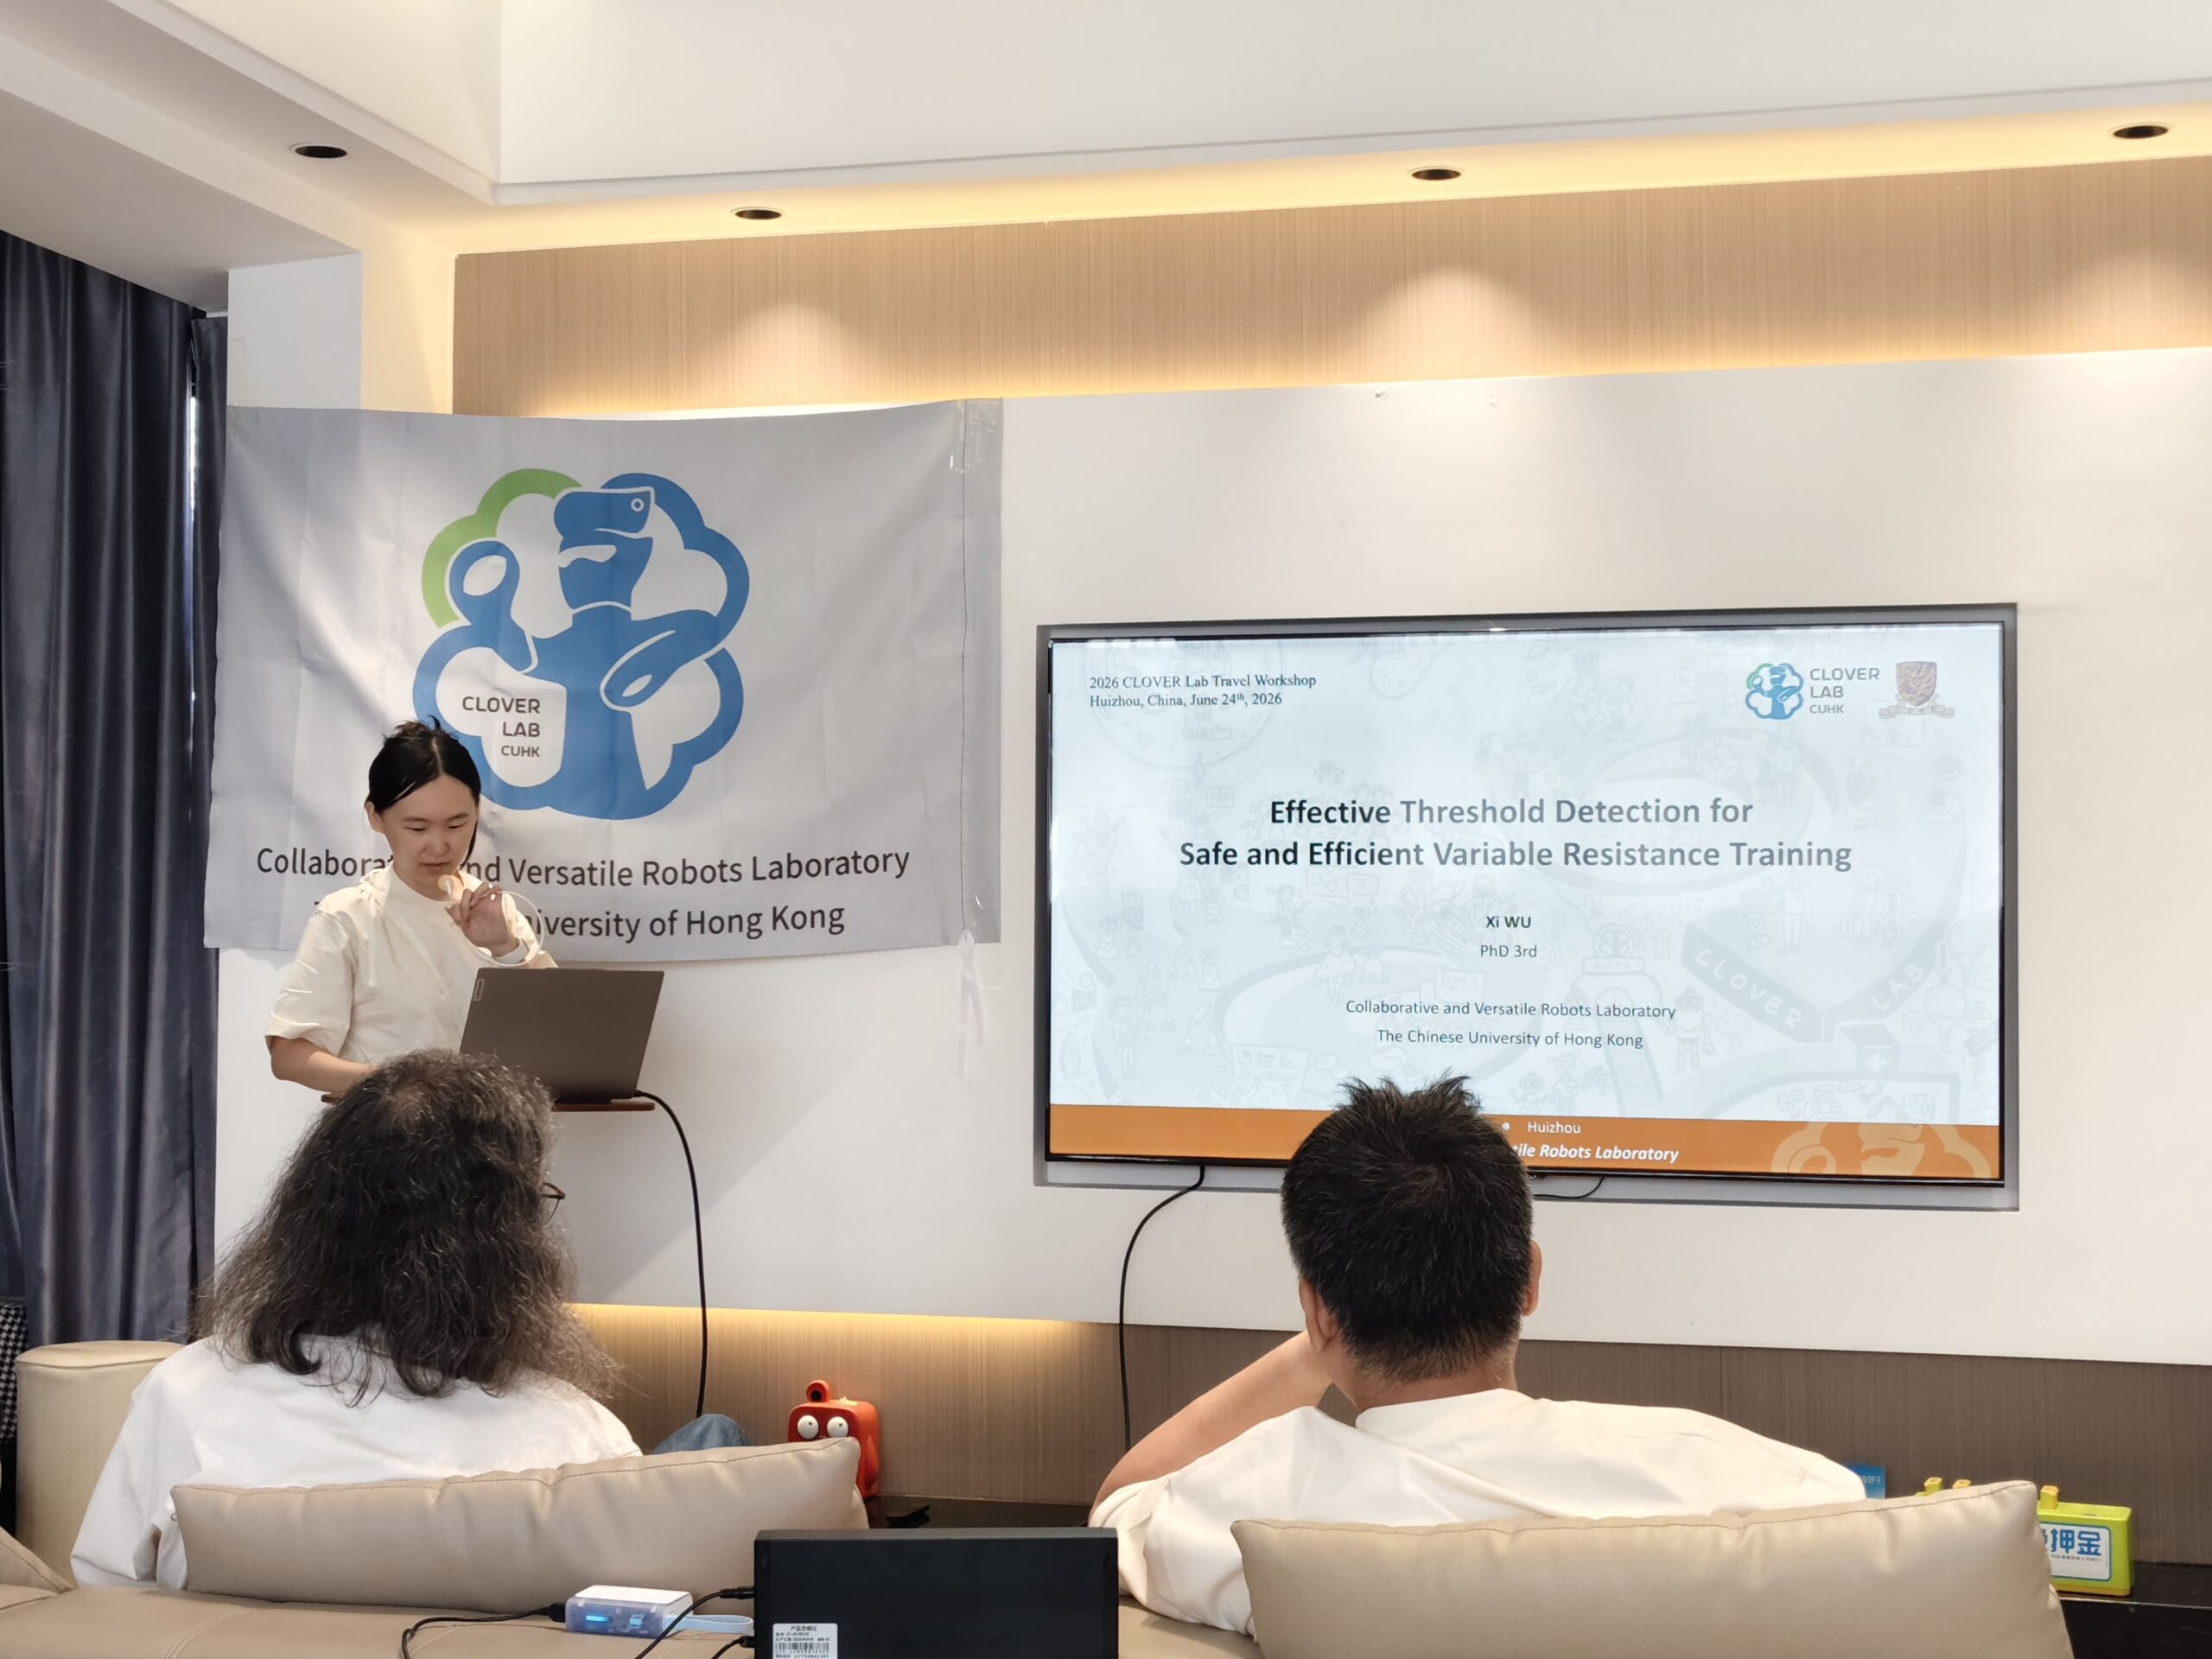
| 10:15-10:30 | Xi WU Effective Threshold Detection for Safe and Efficient Variable Resistance Training |
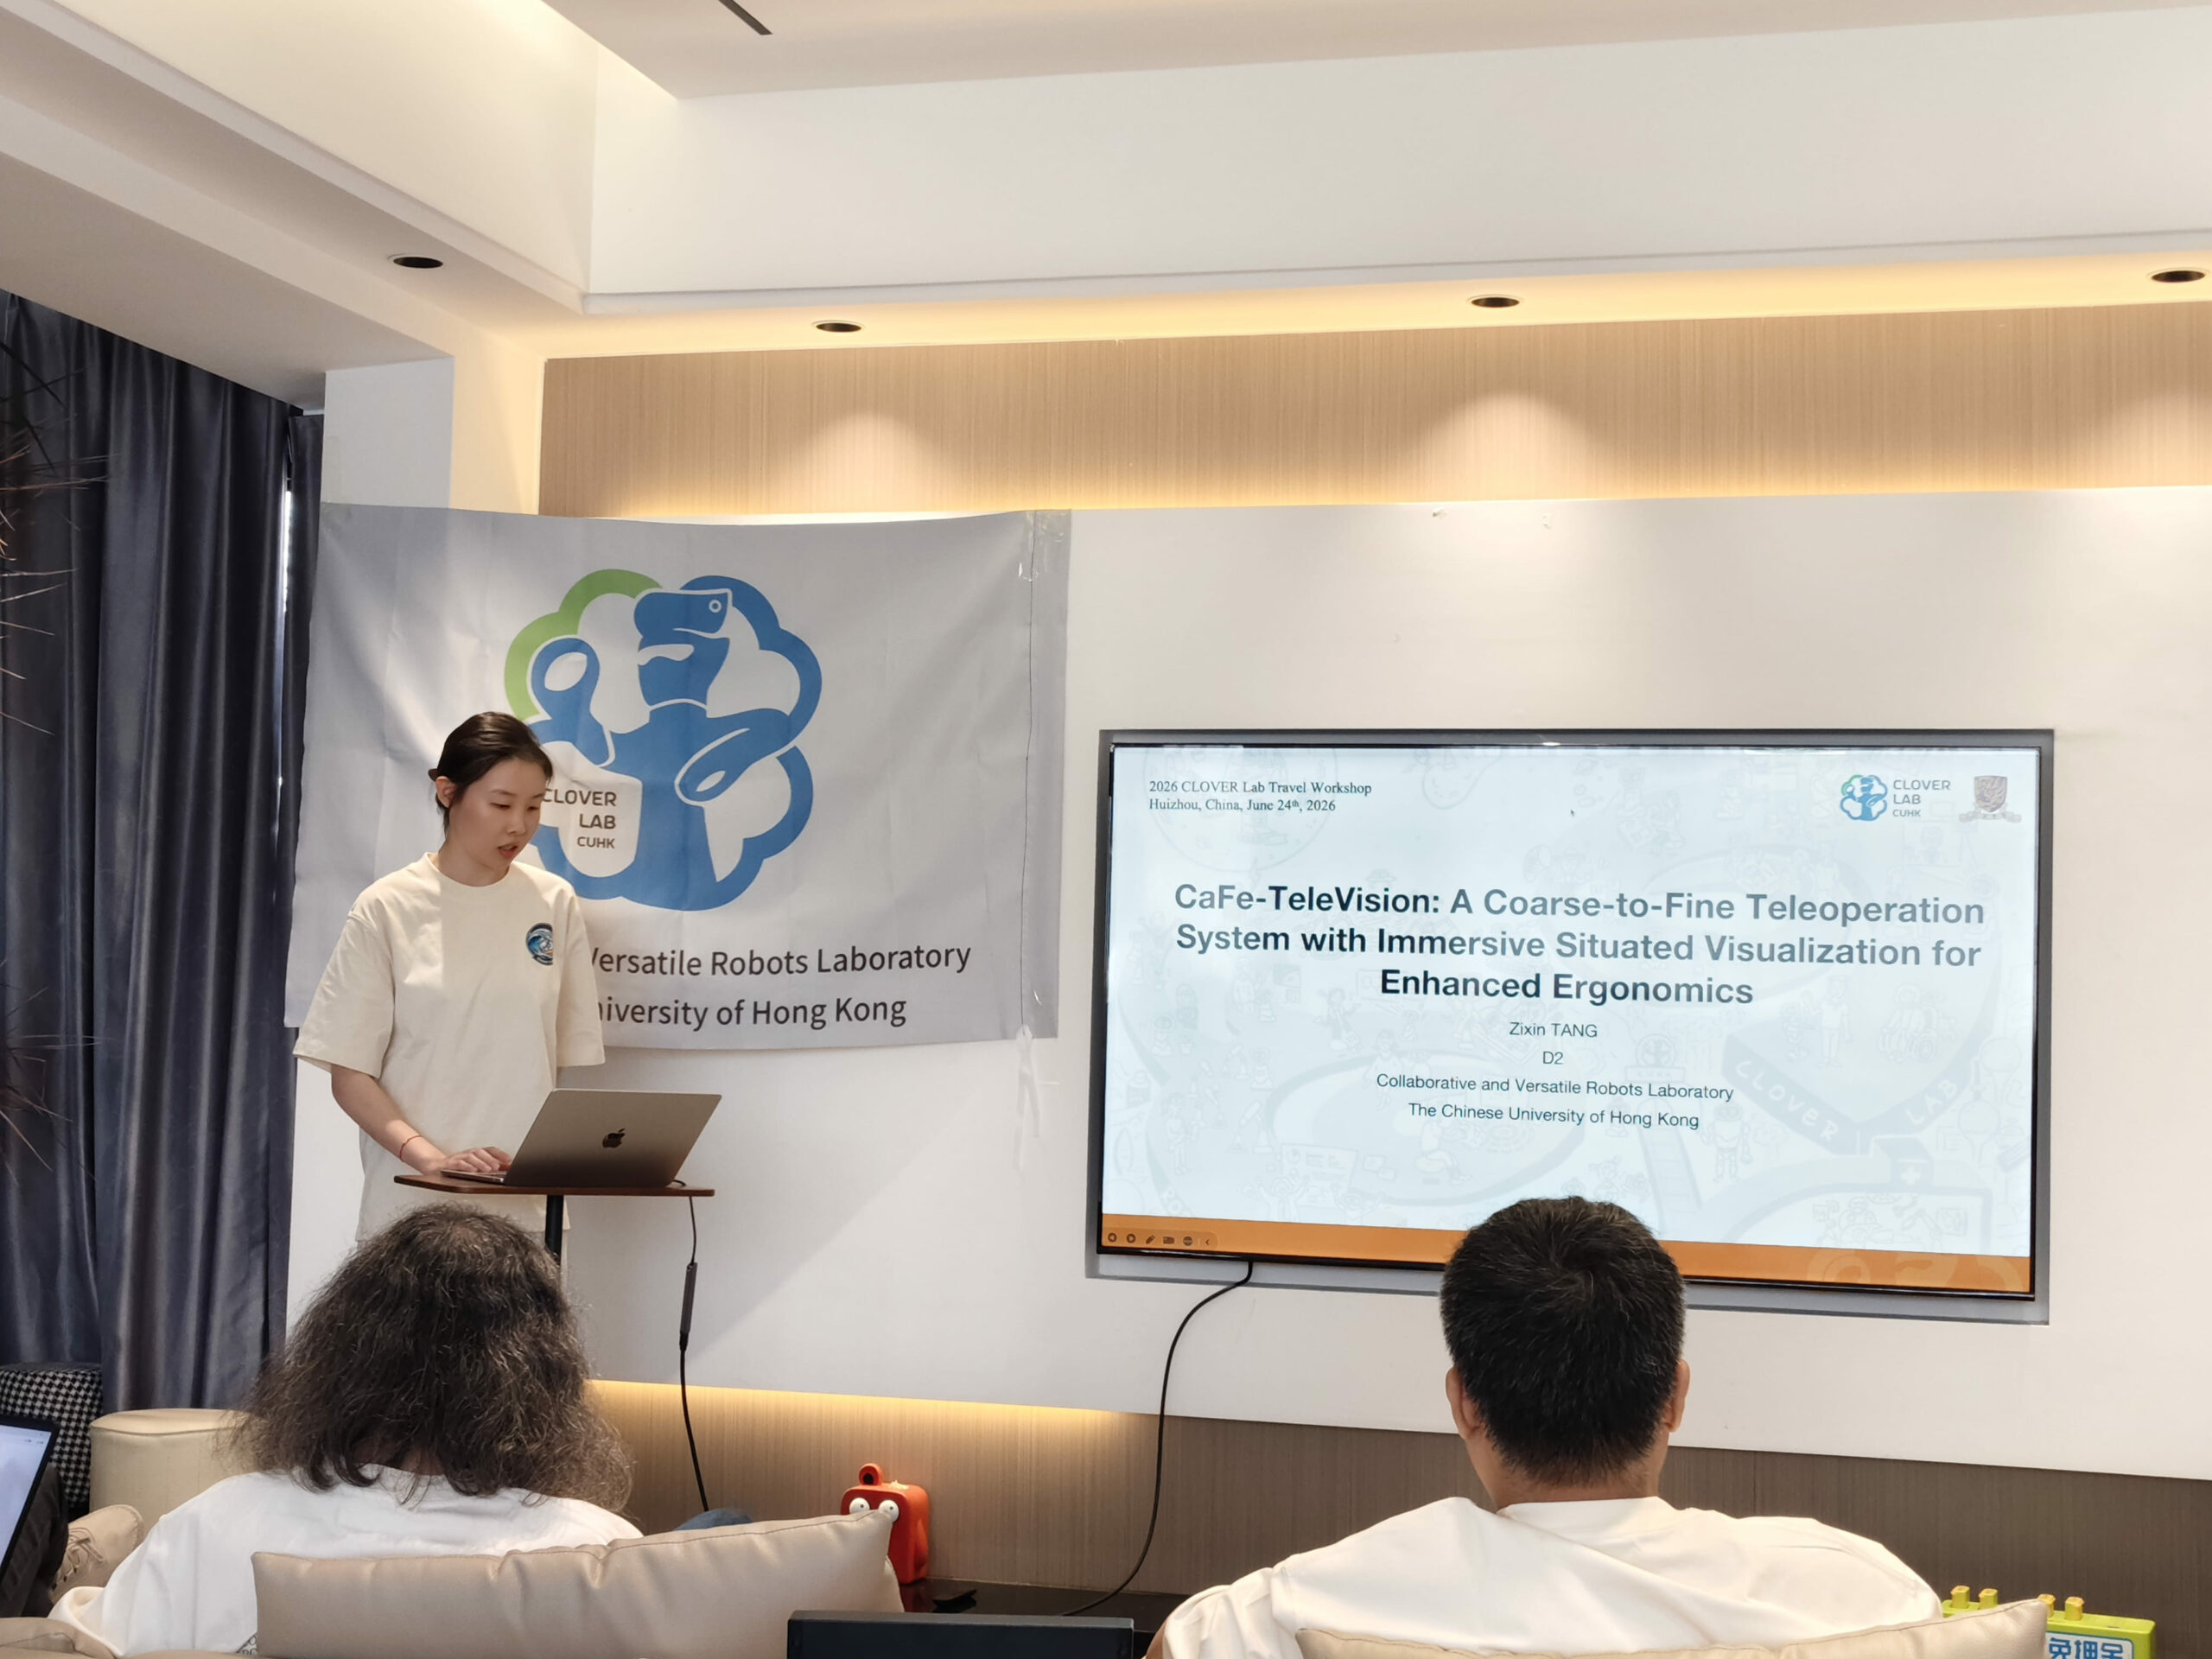
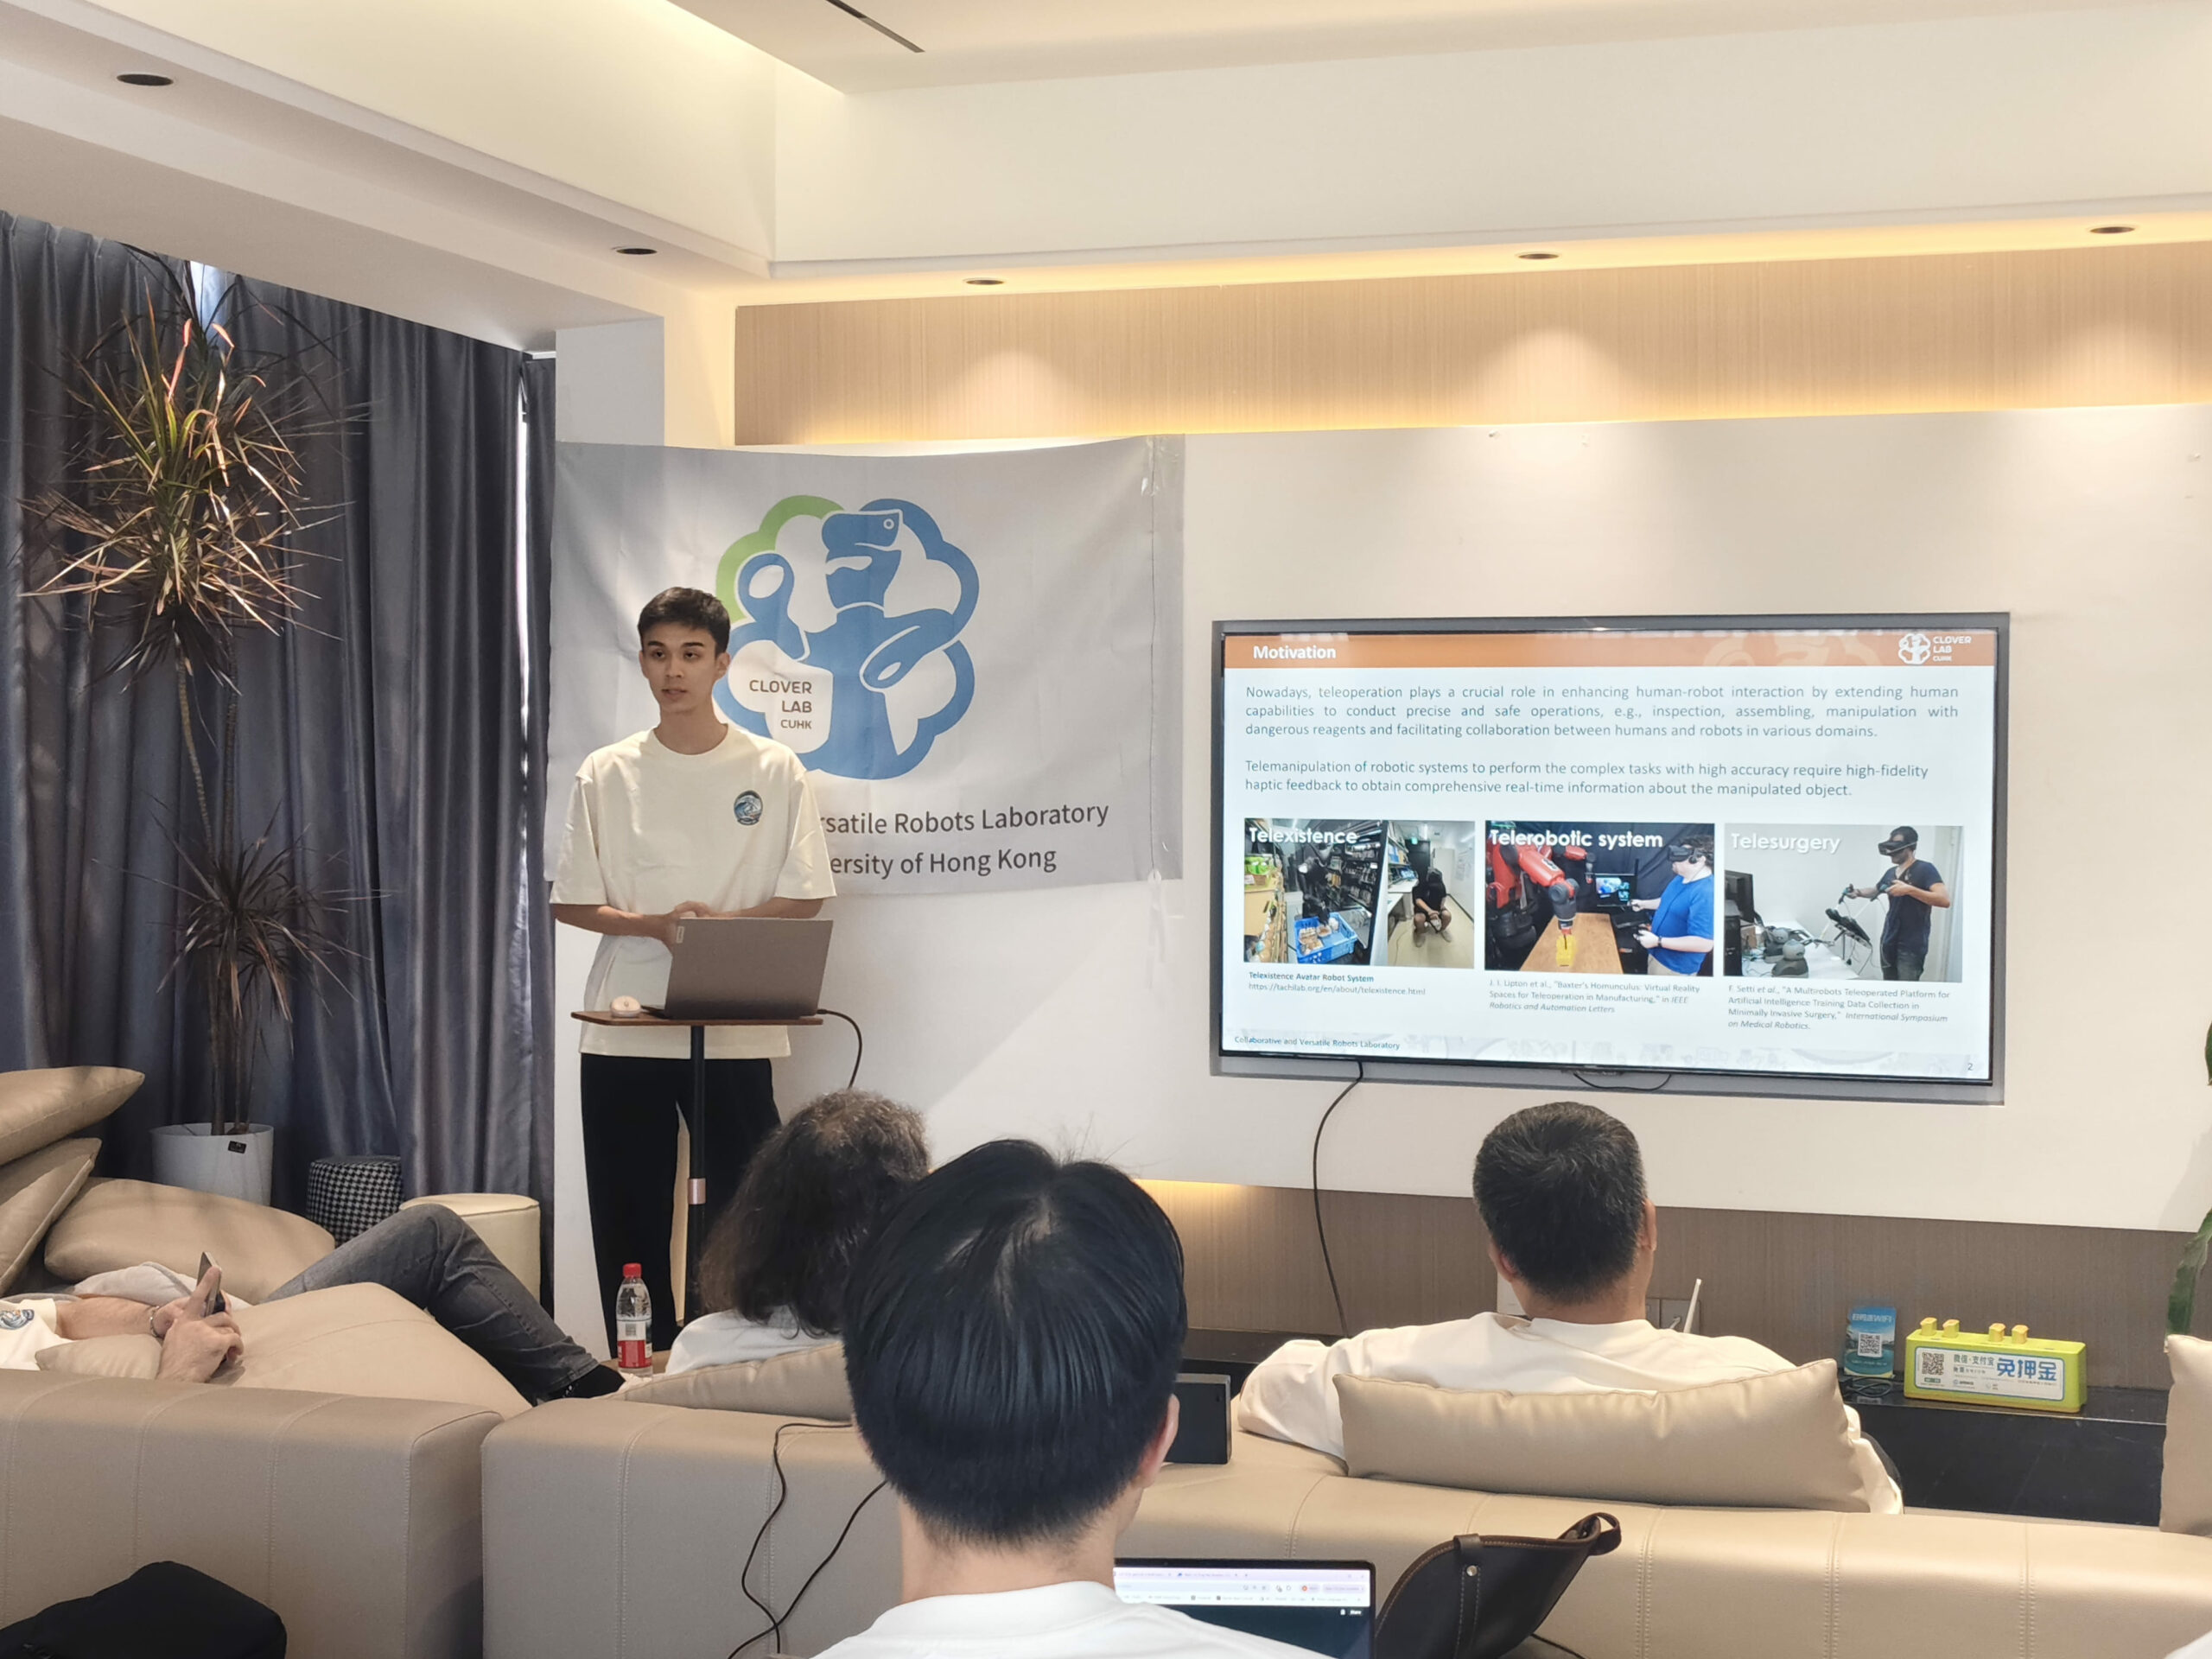
| 10:30-10:45 | Zixin TANG CaFe-TeleVision: A Coarse-to-Fine Teleoperation System with Immersive Situated Visualization for Enhanced Ergonomics |
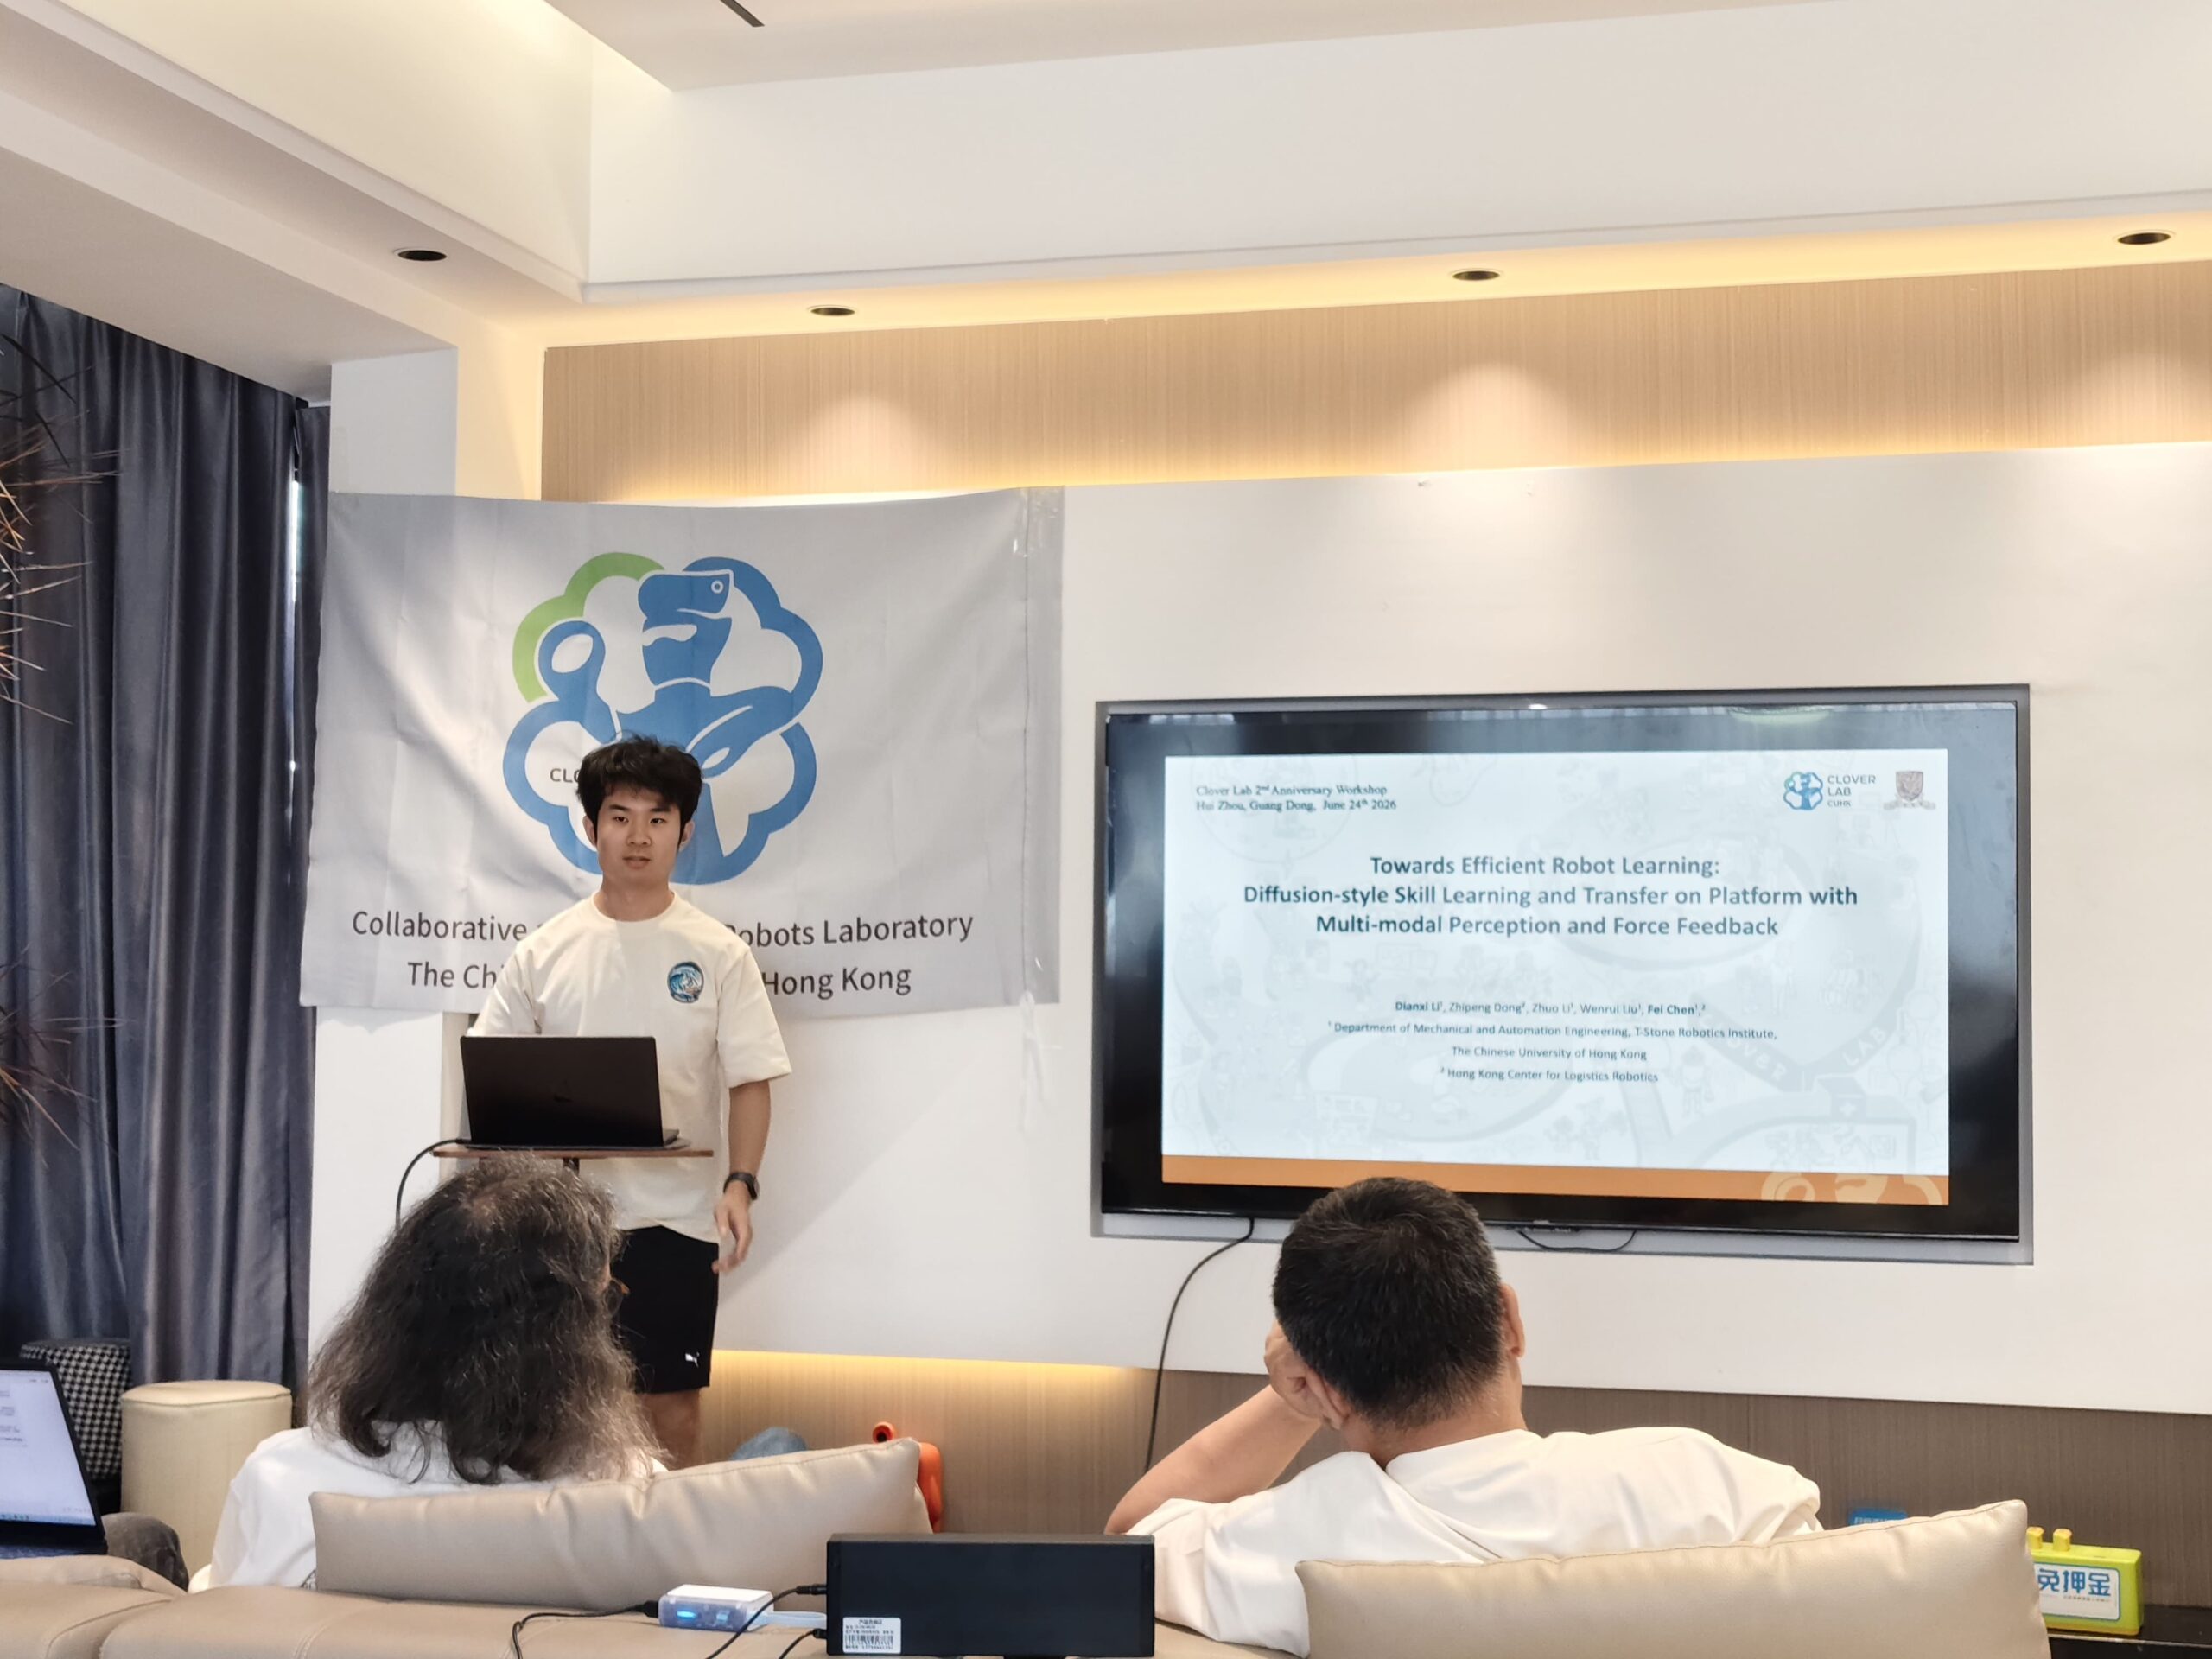
| 10:45-11:00 | Dianxi LI Towards Efficient Robot Learning: Diffusion-style Skill Learning and Transfer on Platform with Multi-modal Perception and Force Feedback |
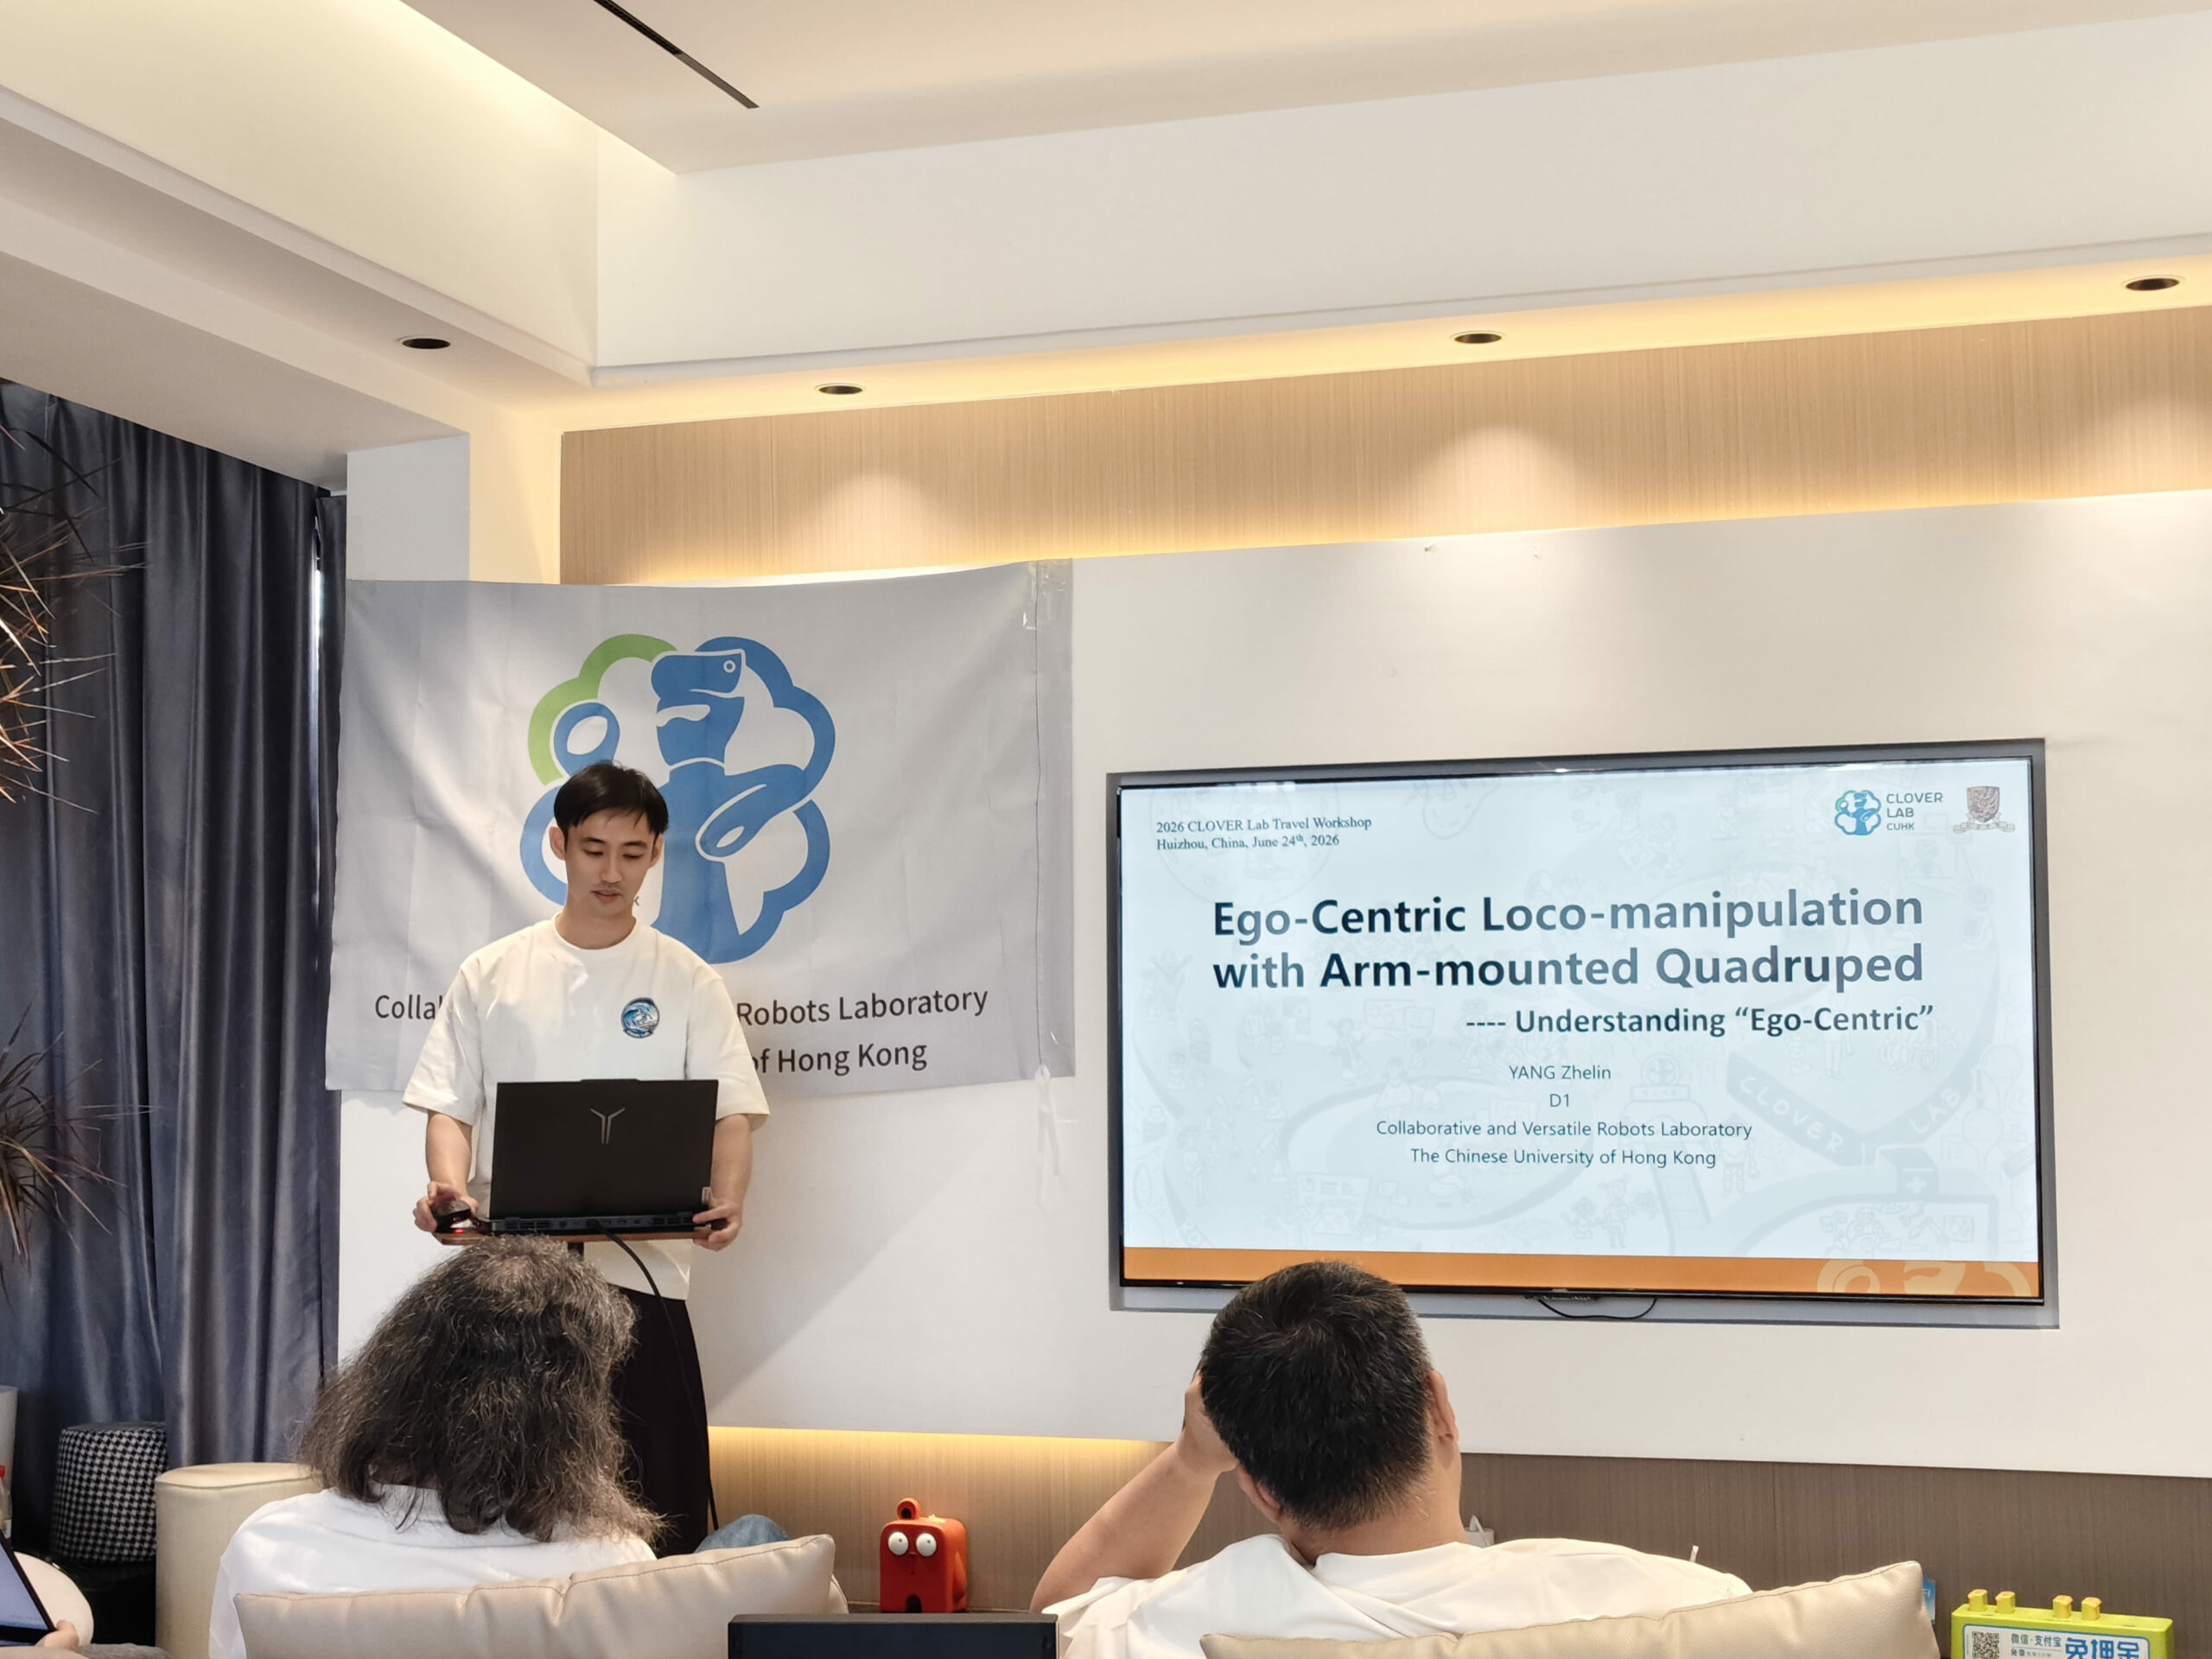
| 11:00-11:15 | Zhelin YANG Ego-Centric Loco-manipulation with Arm-mounted Quadruped |
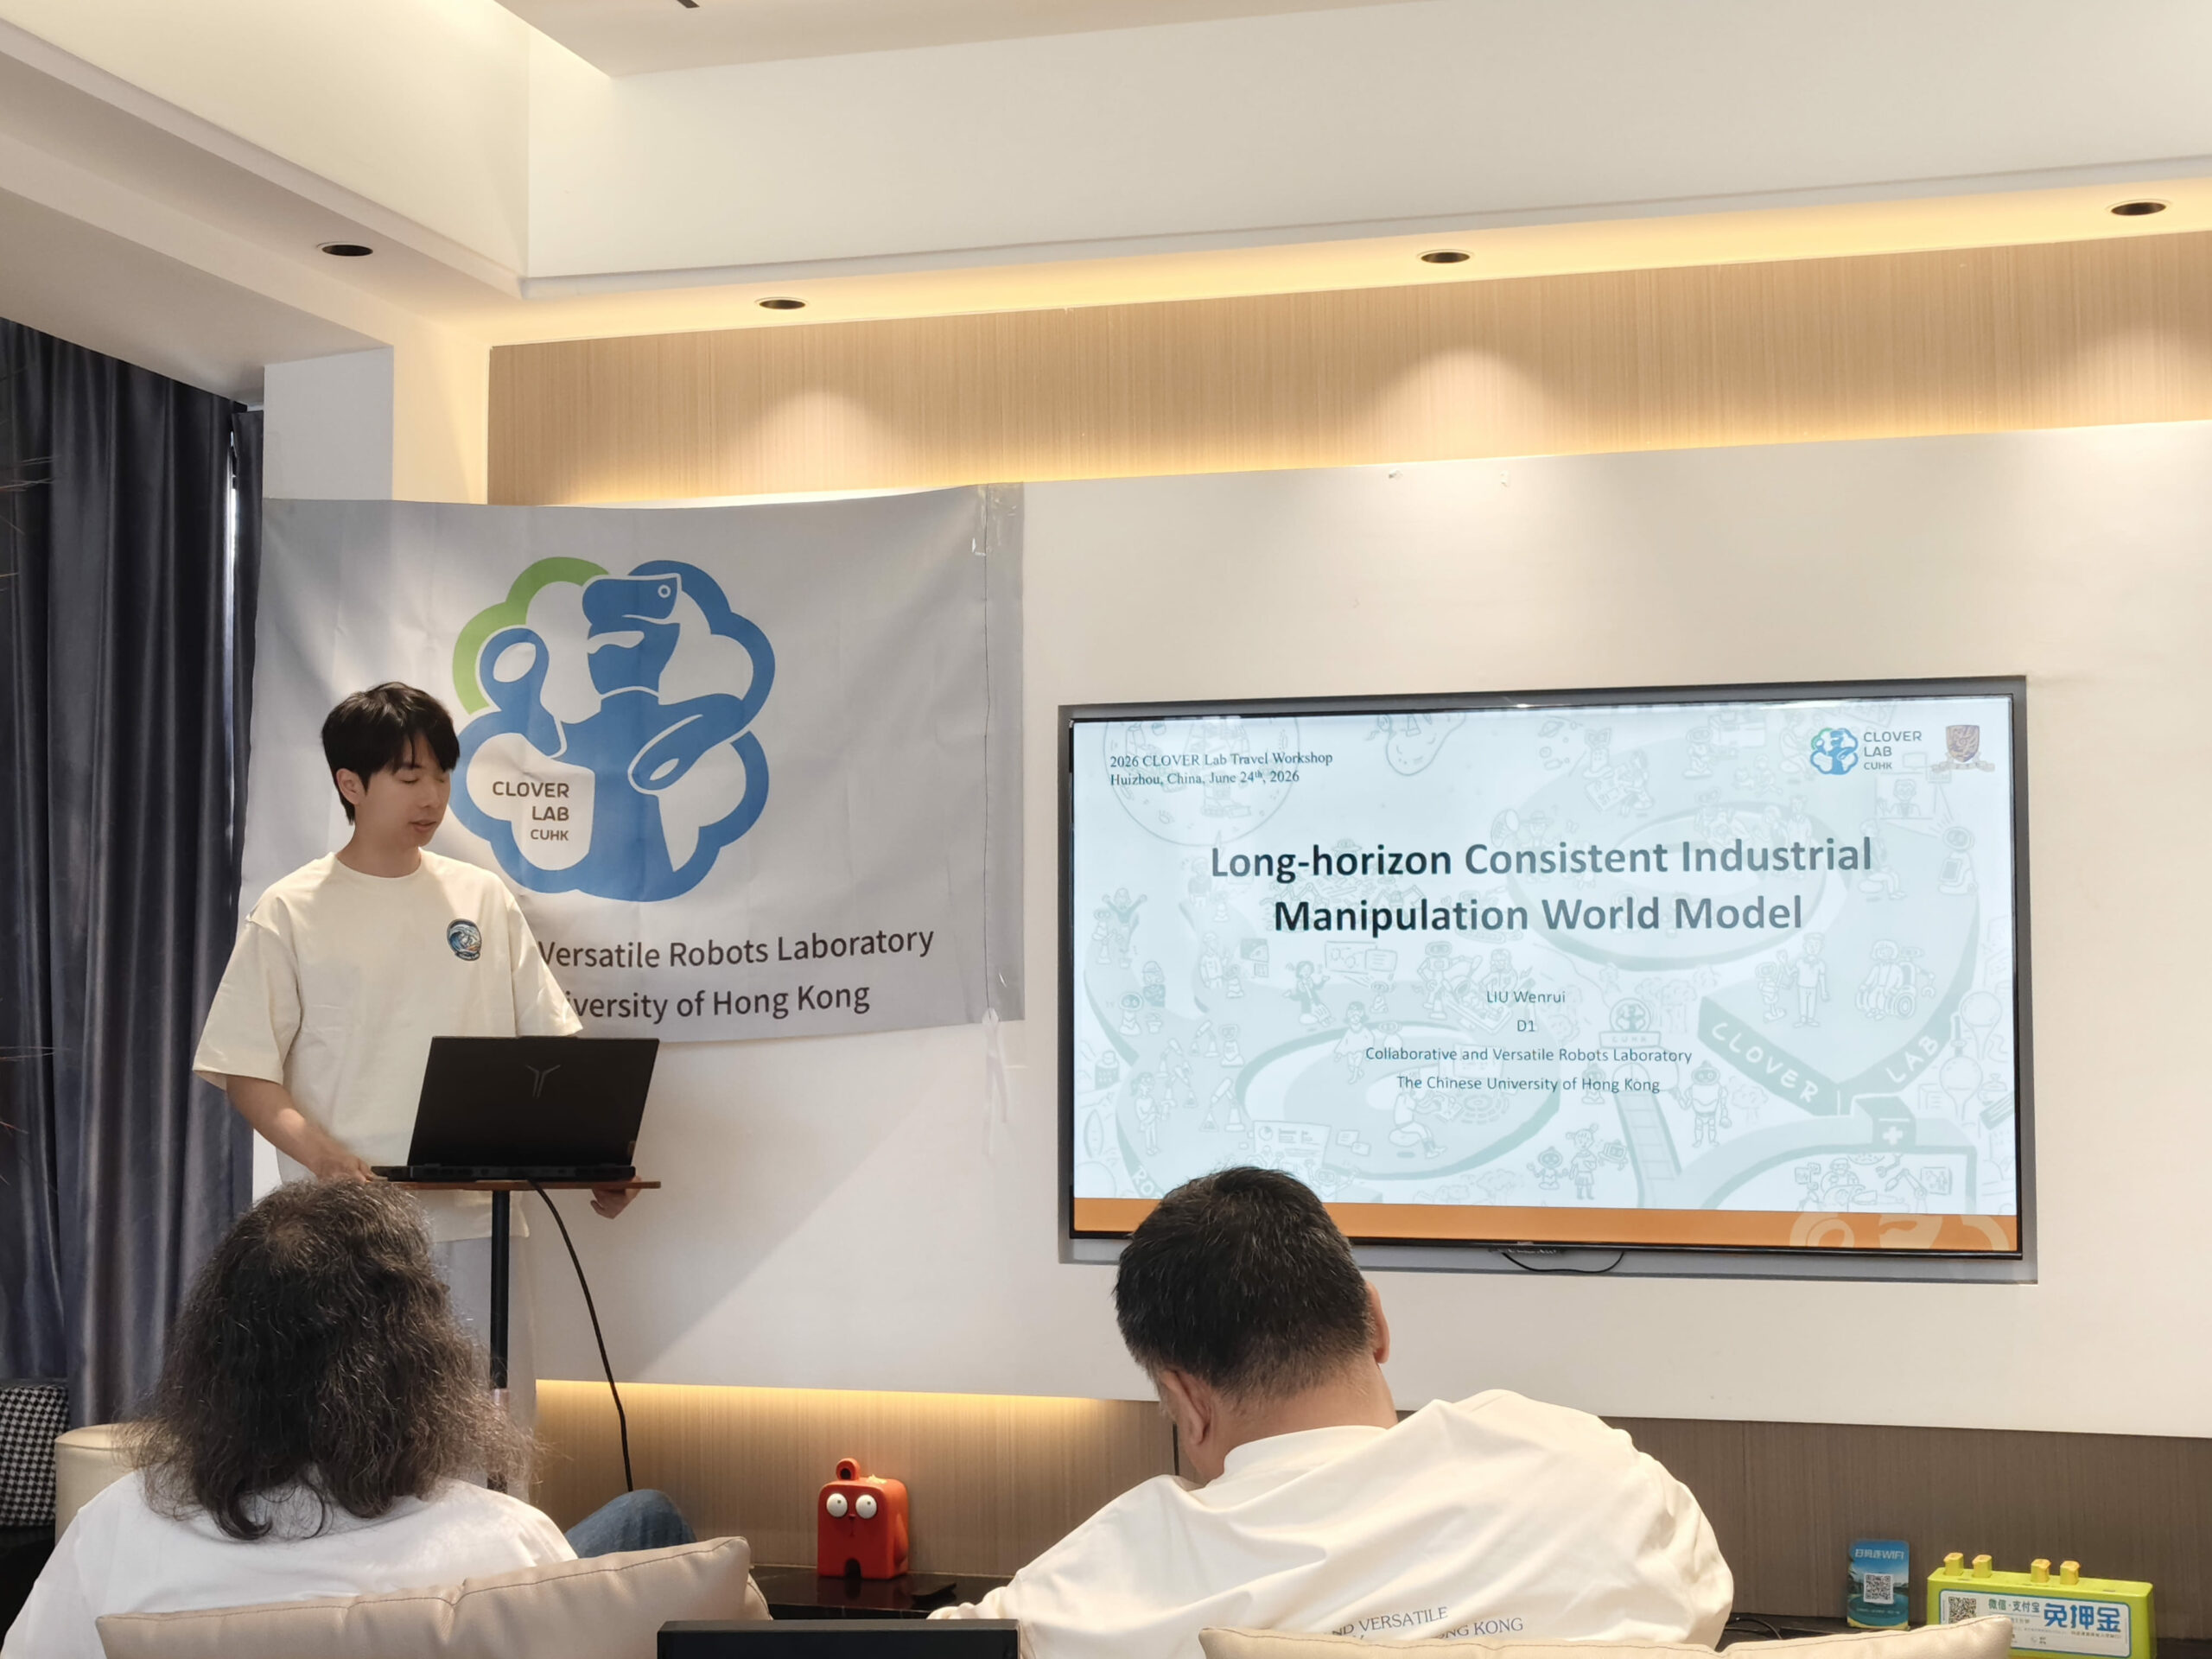
| 11:15-11:30 | Wenrui LIU Long-horizon Consistency Industrial Manipulation World Model |
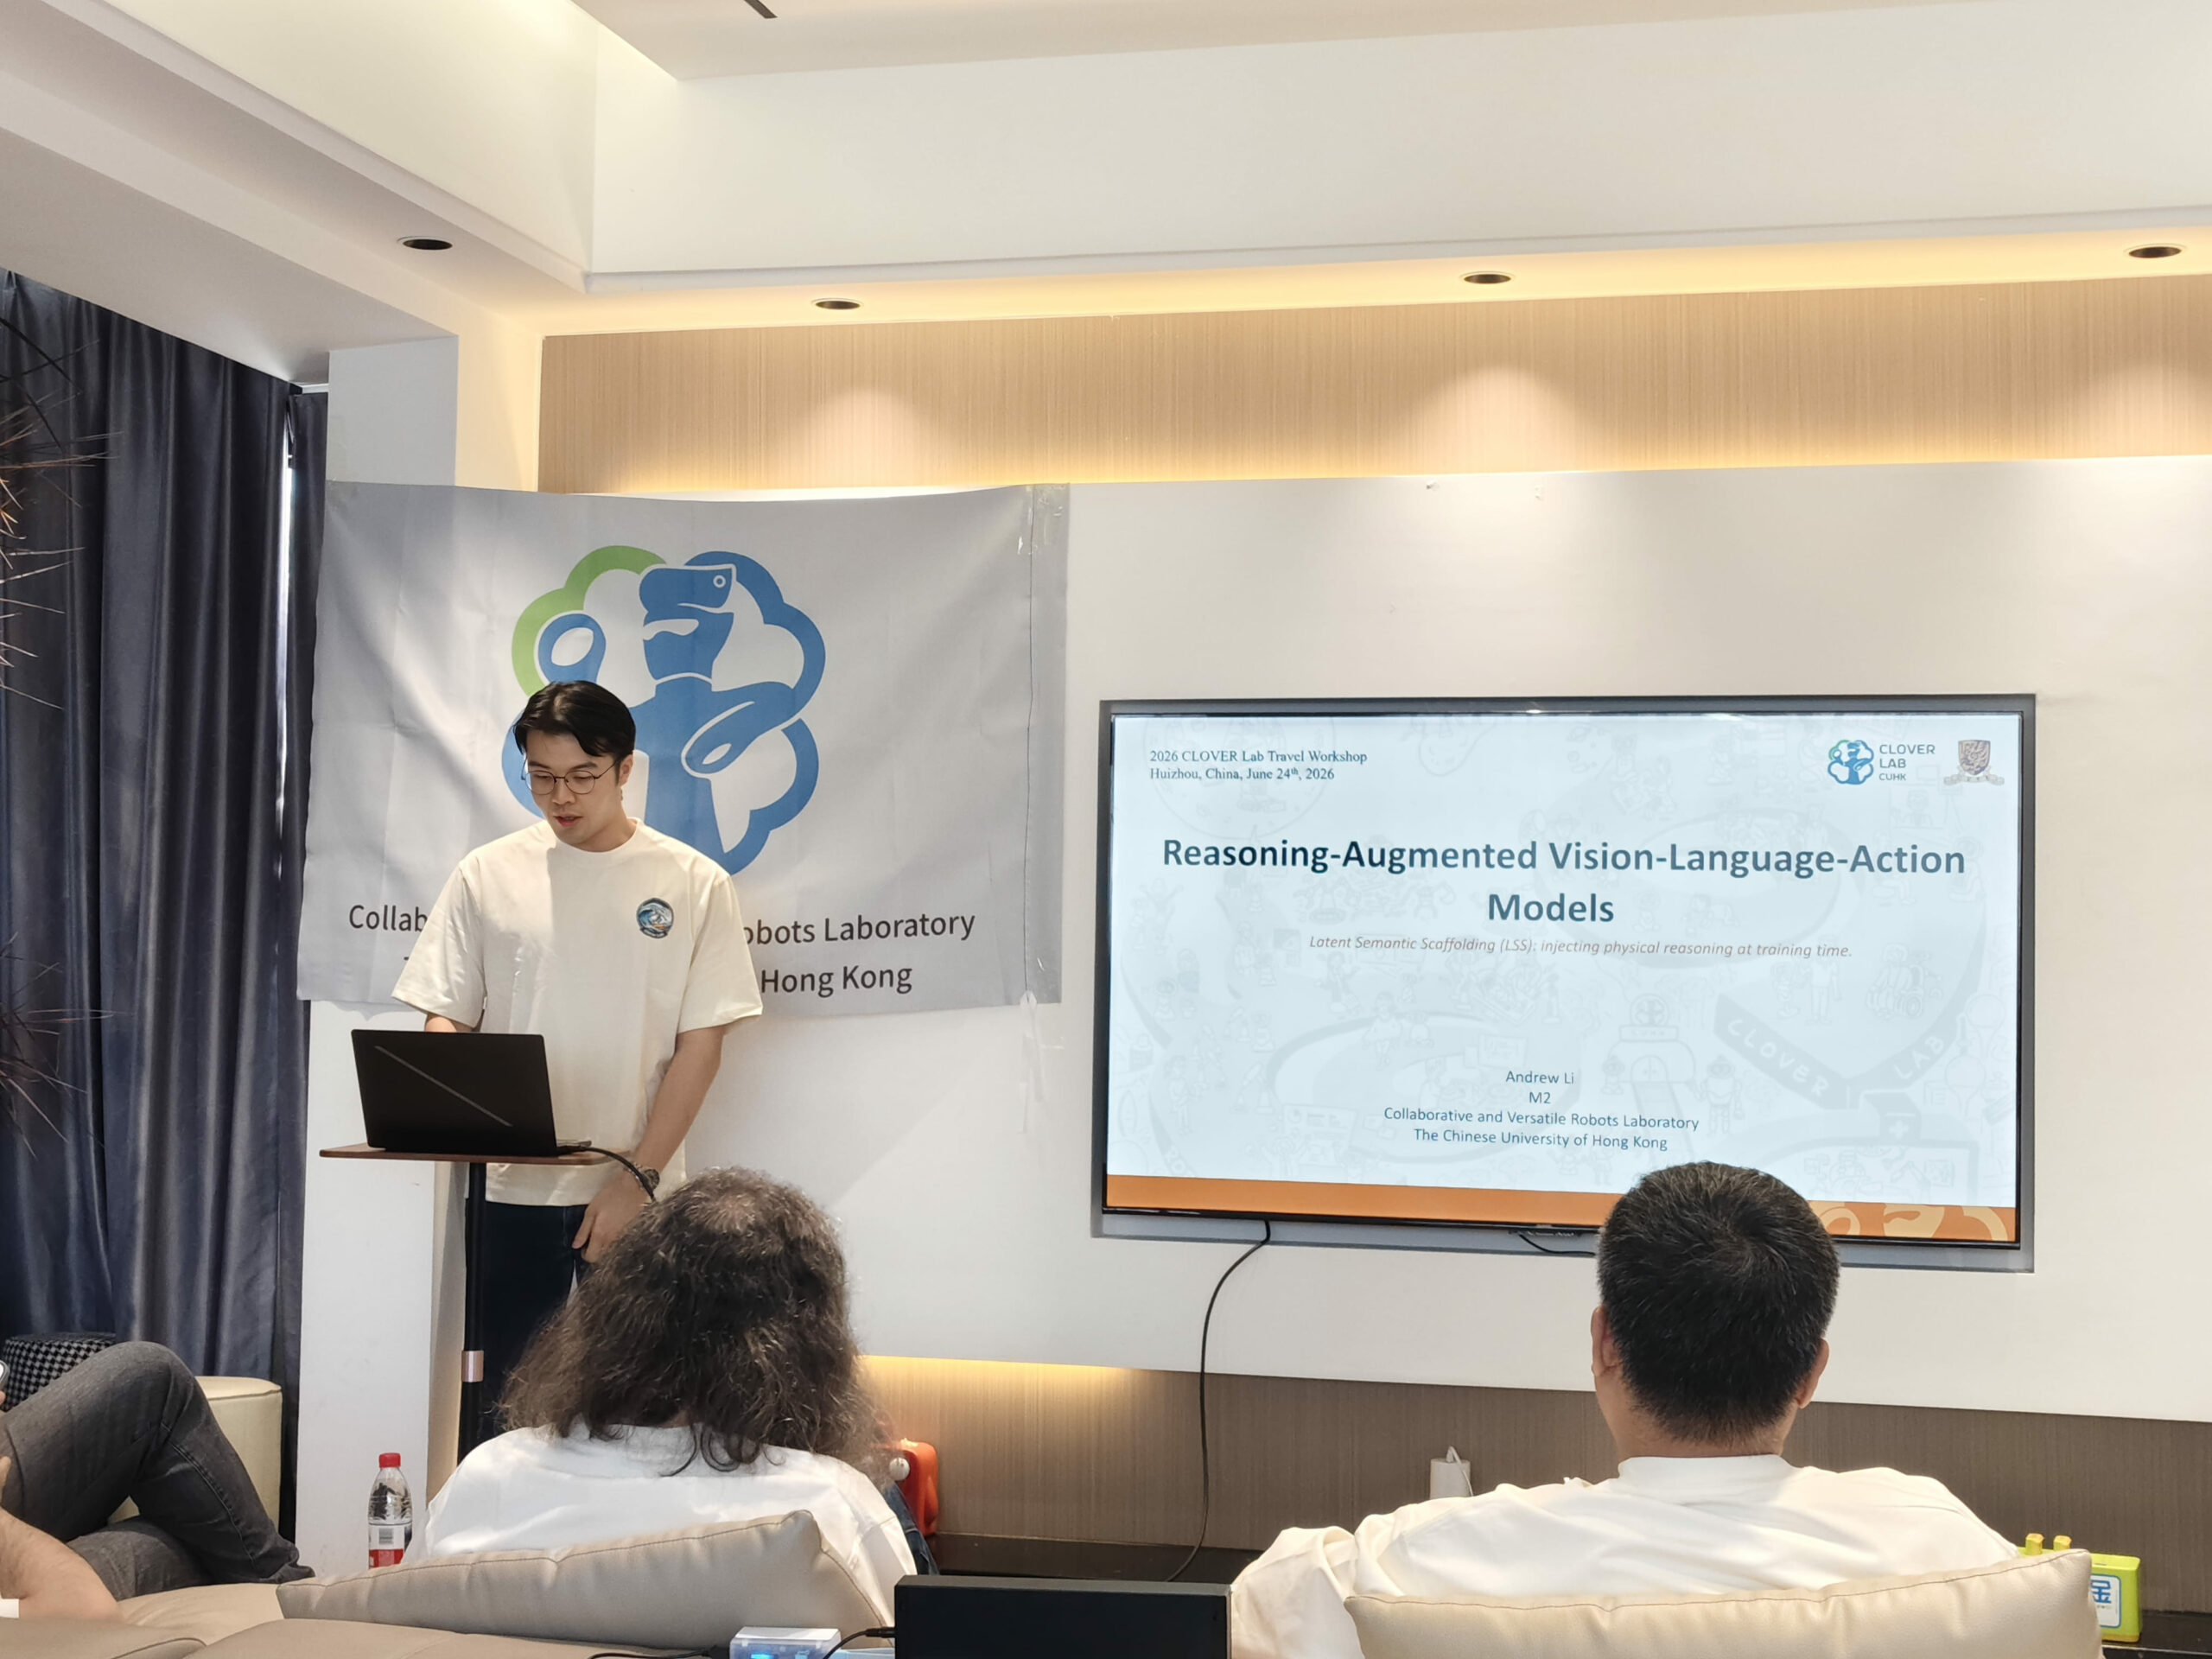
| 11:30-11:45 | Andrew LI Reasoning-Augmented Vision-Language-Action Models Latent Semantic Scaffolding (LSS): Injecting Physical Reasoning at Training Time |
| 12:00-13:00 | Lunch |
| 13:00-13:15 | Xueqian ZHAI Compliant and Cooperative Interaction Learning for Dual-Arm Robots |
| 13:15-13:30 | Yuchen YAN Decoupling Motion Priors from Control Strategies: Replicating and Refining Natural Gait in the Humanoid Robot Marathon |
| 13:30-13:45 | Issatay TOKMURZIYEV A Multi-point Wearable Fluidic Haptic Interface for Rendering Remotely Grasped Surfaces during Teleoperation Tasks |
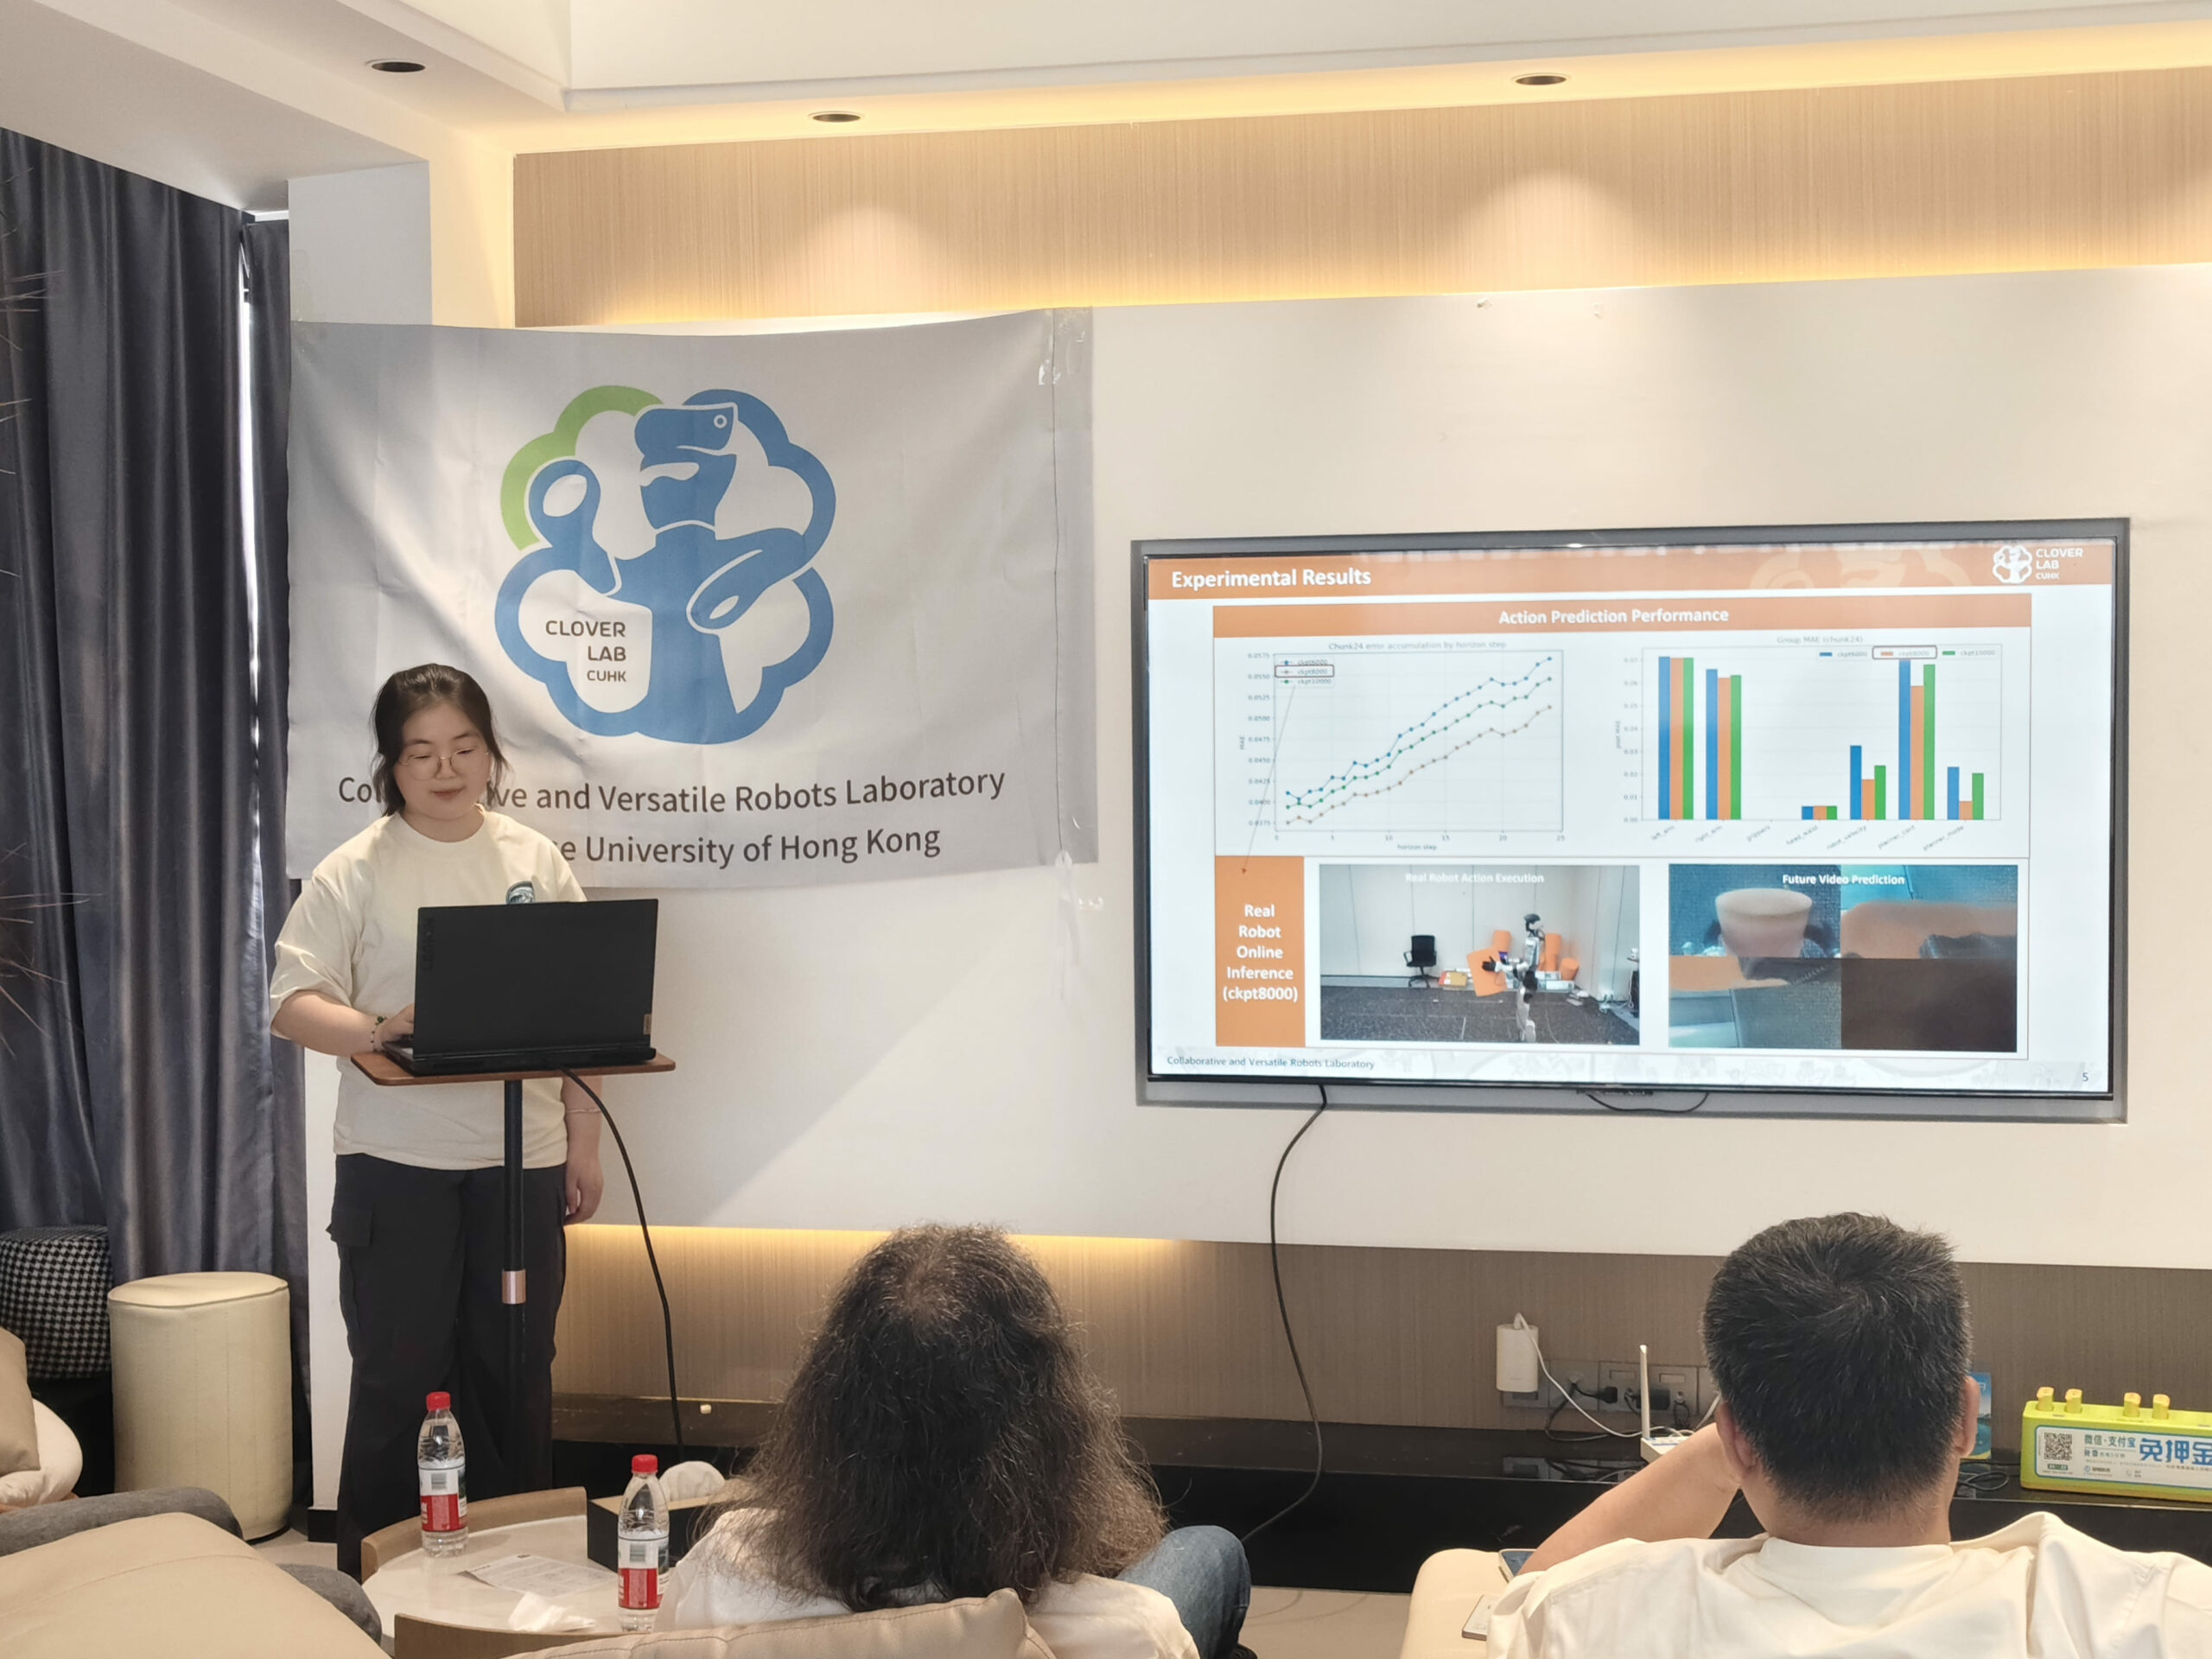
| 13:45-14:00 | Mengjie JING Long-Horizon Humanoid Cylinder Manipulation via World Action Model Adaptation for Whole-Body Execution |
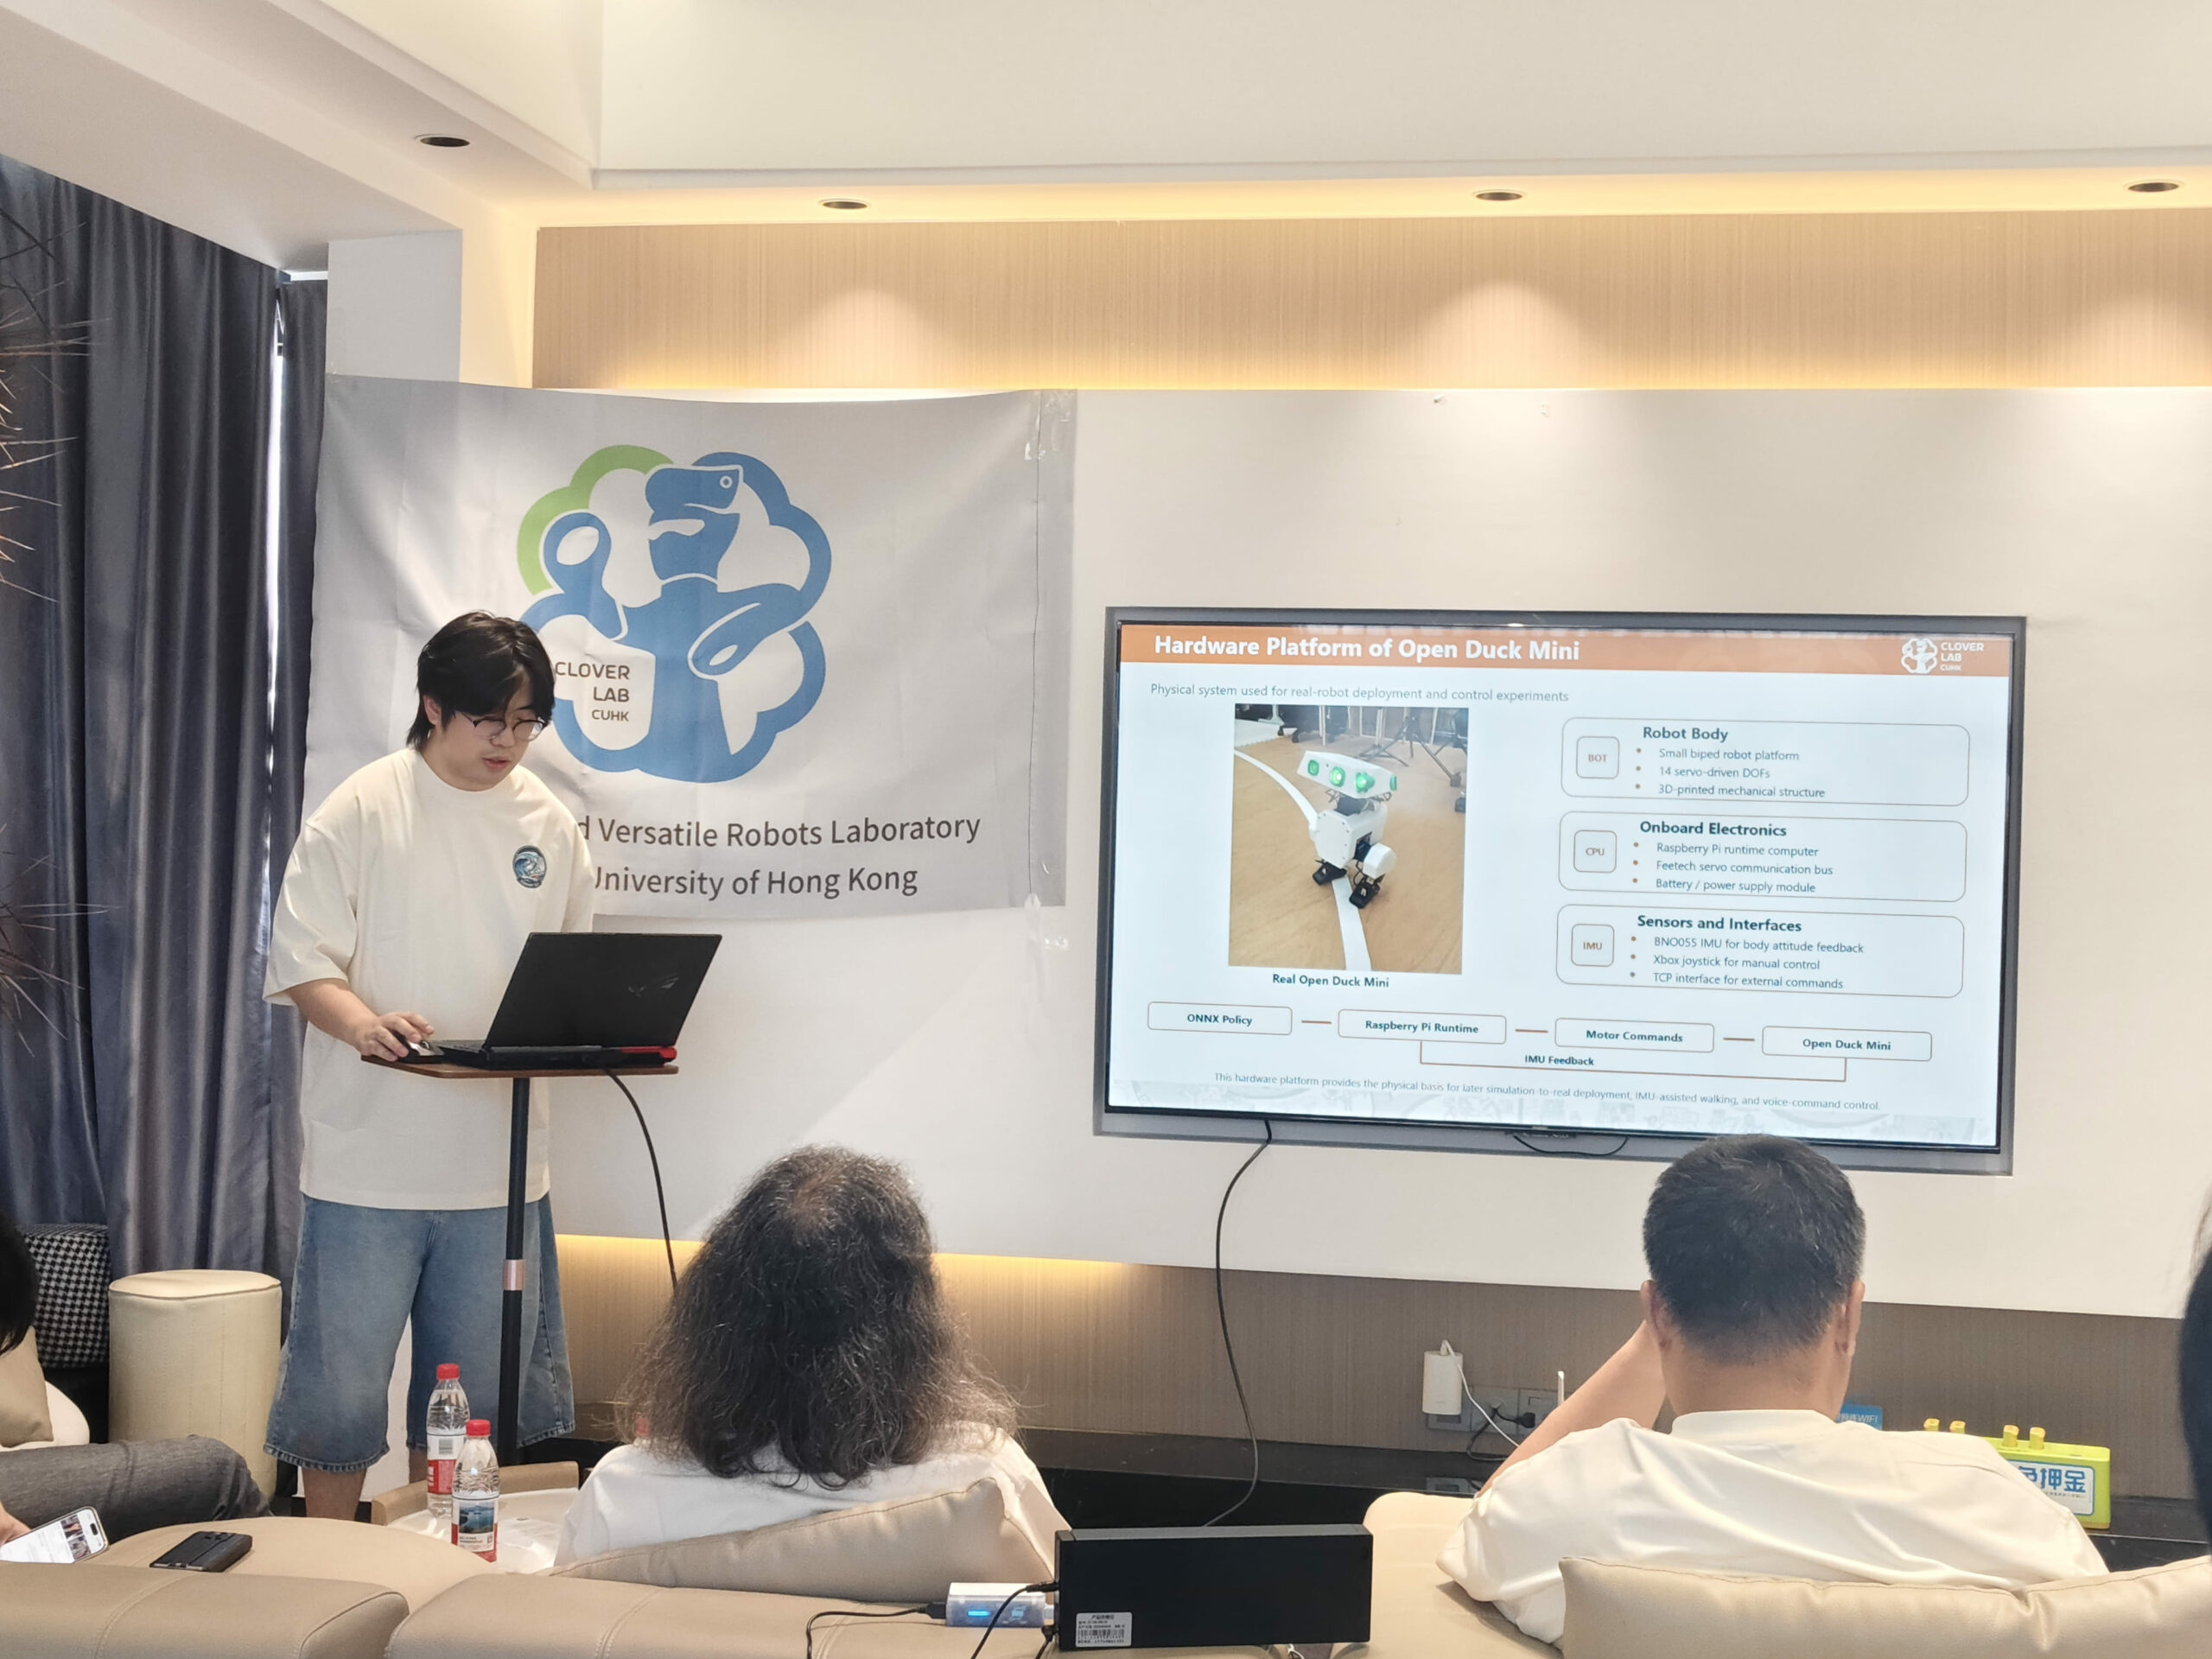
| 14:00-14:15 | Yuntian XIA Open Duck Mini Project: RL-based Biped Locomotion and Interactive Control |
| 14:15-14:30 | Hengyi SIM Soft Object World Model with In-Context Dynamics Identification |
| 14:30-14:45 | Zhihao LI Tutorial on Agents for Coding and Research |
| 14:45-15:00 | Dr. Chenzui LI The Road to a PhD: What to Do in the Last Six Months? |
| 15:00-15:15 | Yiming CHEN Adaptive Impedance Control Inspired by Neuromuscular Regulation |
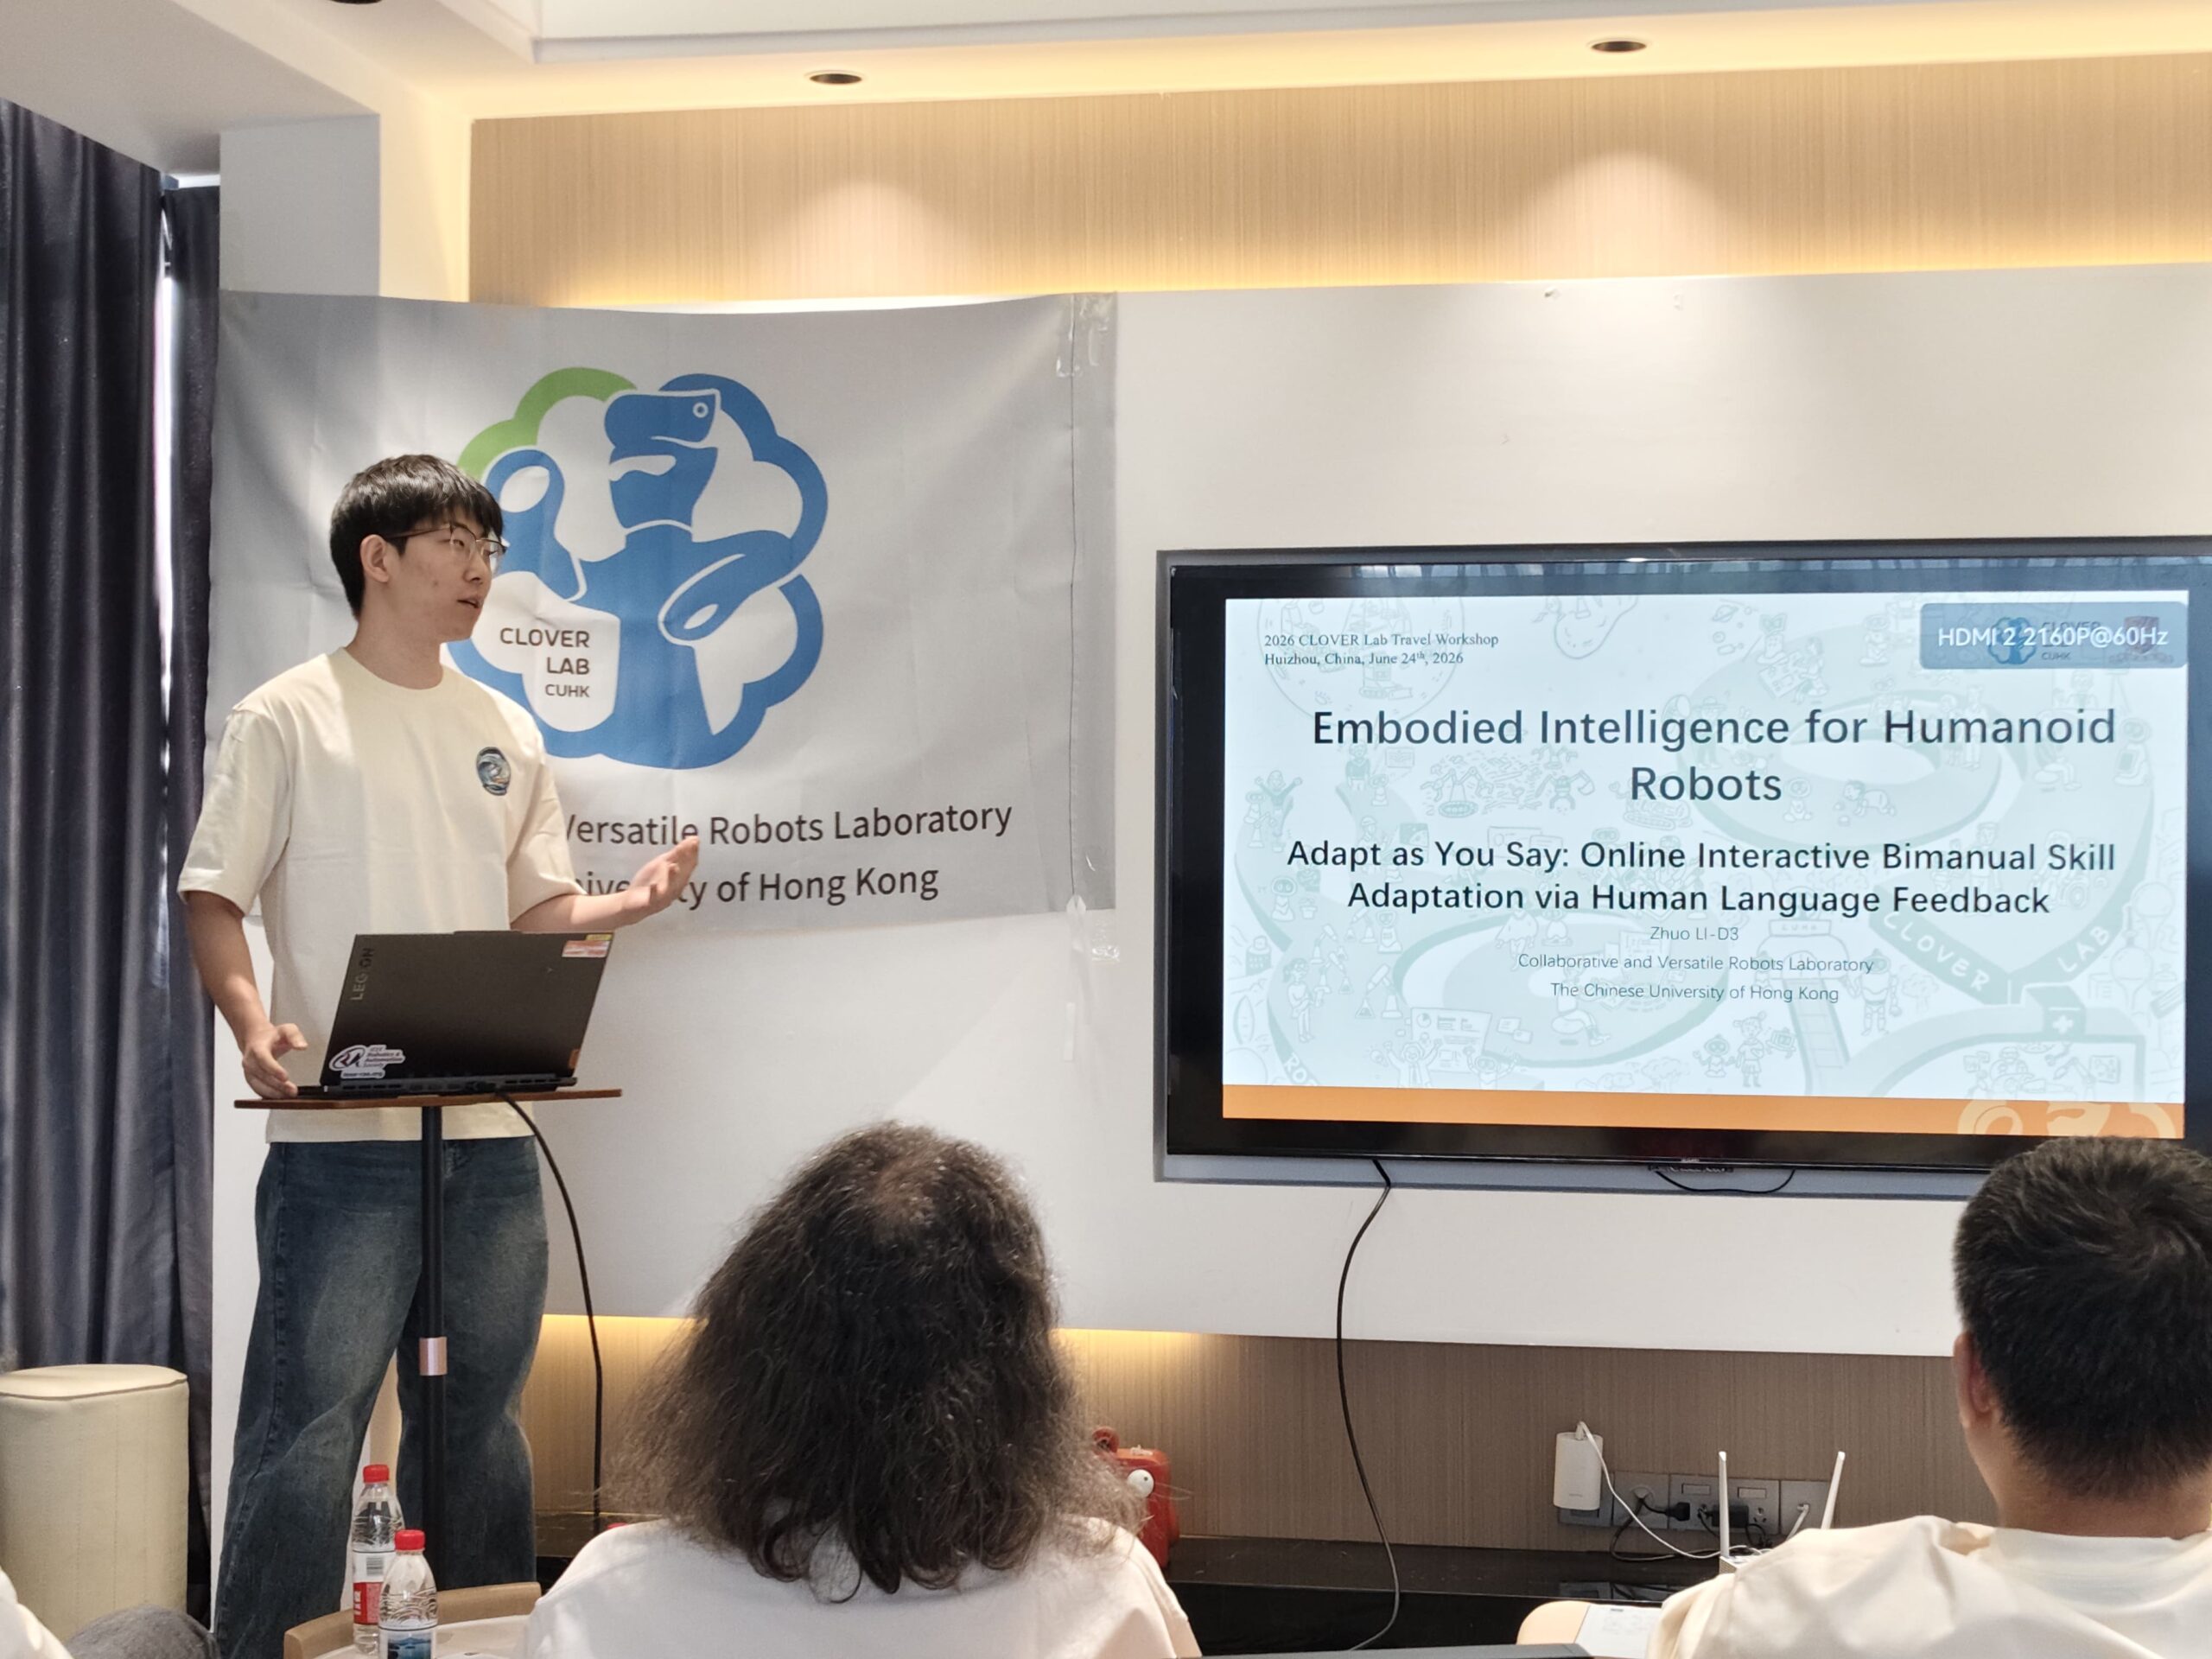
| 15:15-15:30 | Zhuo LI Adapt as You Say: Online Interactive Bimanual Skill Adaptation via Human Language Feedback |
| 15:30-16:00 | Prof. Fei CHEN Annual Summary of CLOVER Lab & Workshop Closing Remarks |
| 16:00-21:00 | Banquet & Fireworks |
| June 25 (Thursday) | |
| 10:00-16:00 | Local Culture Experience Dinner arranged individually |
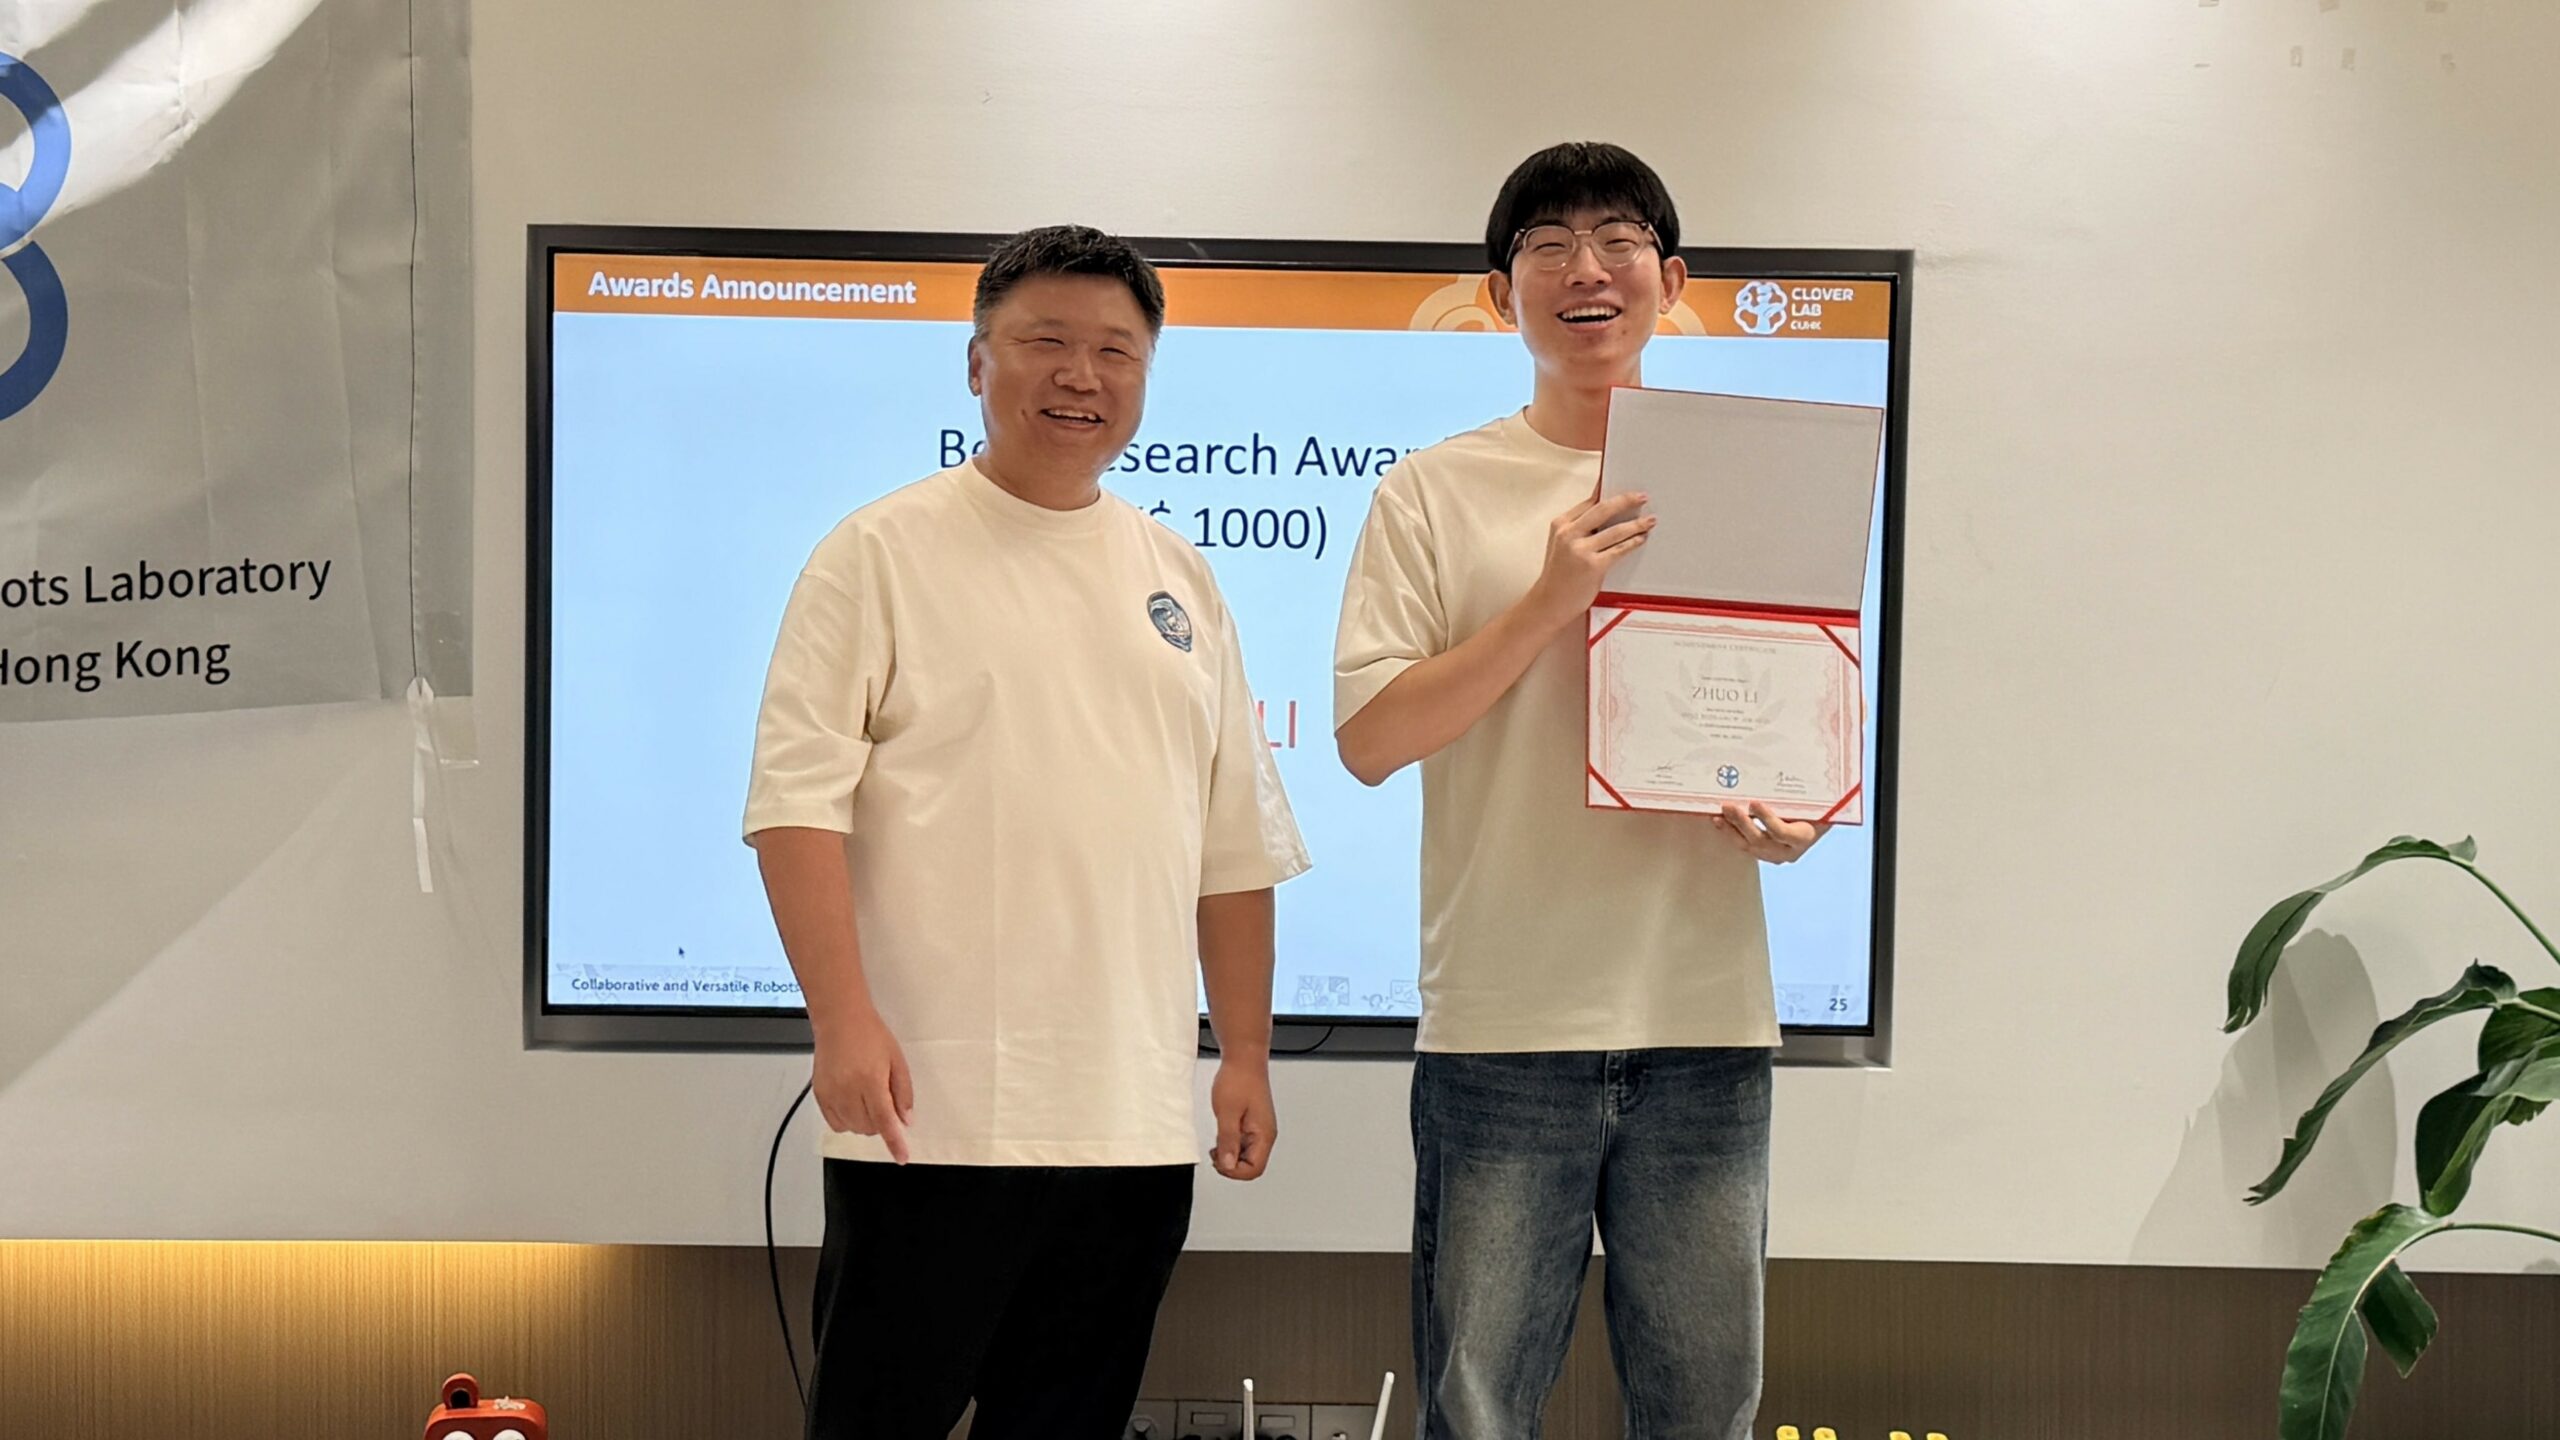
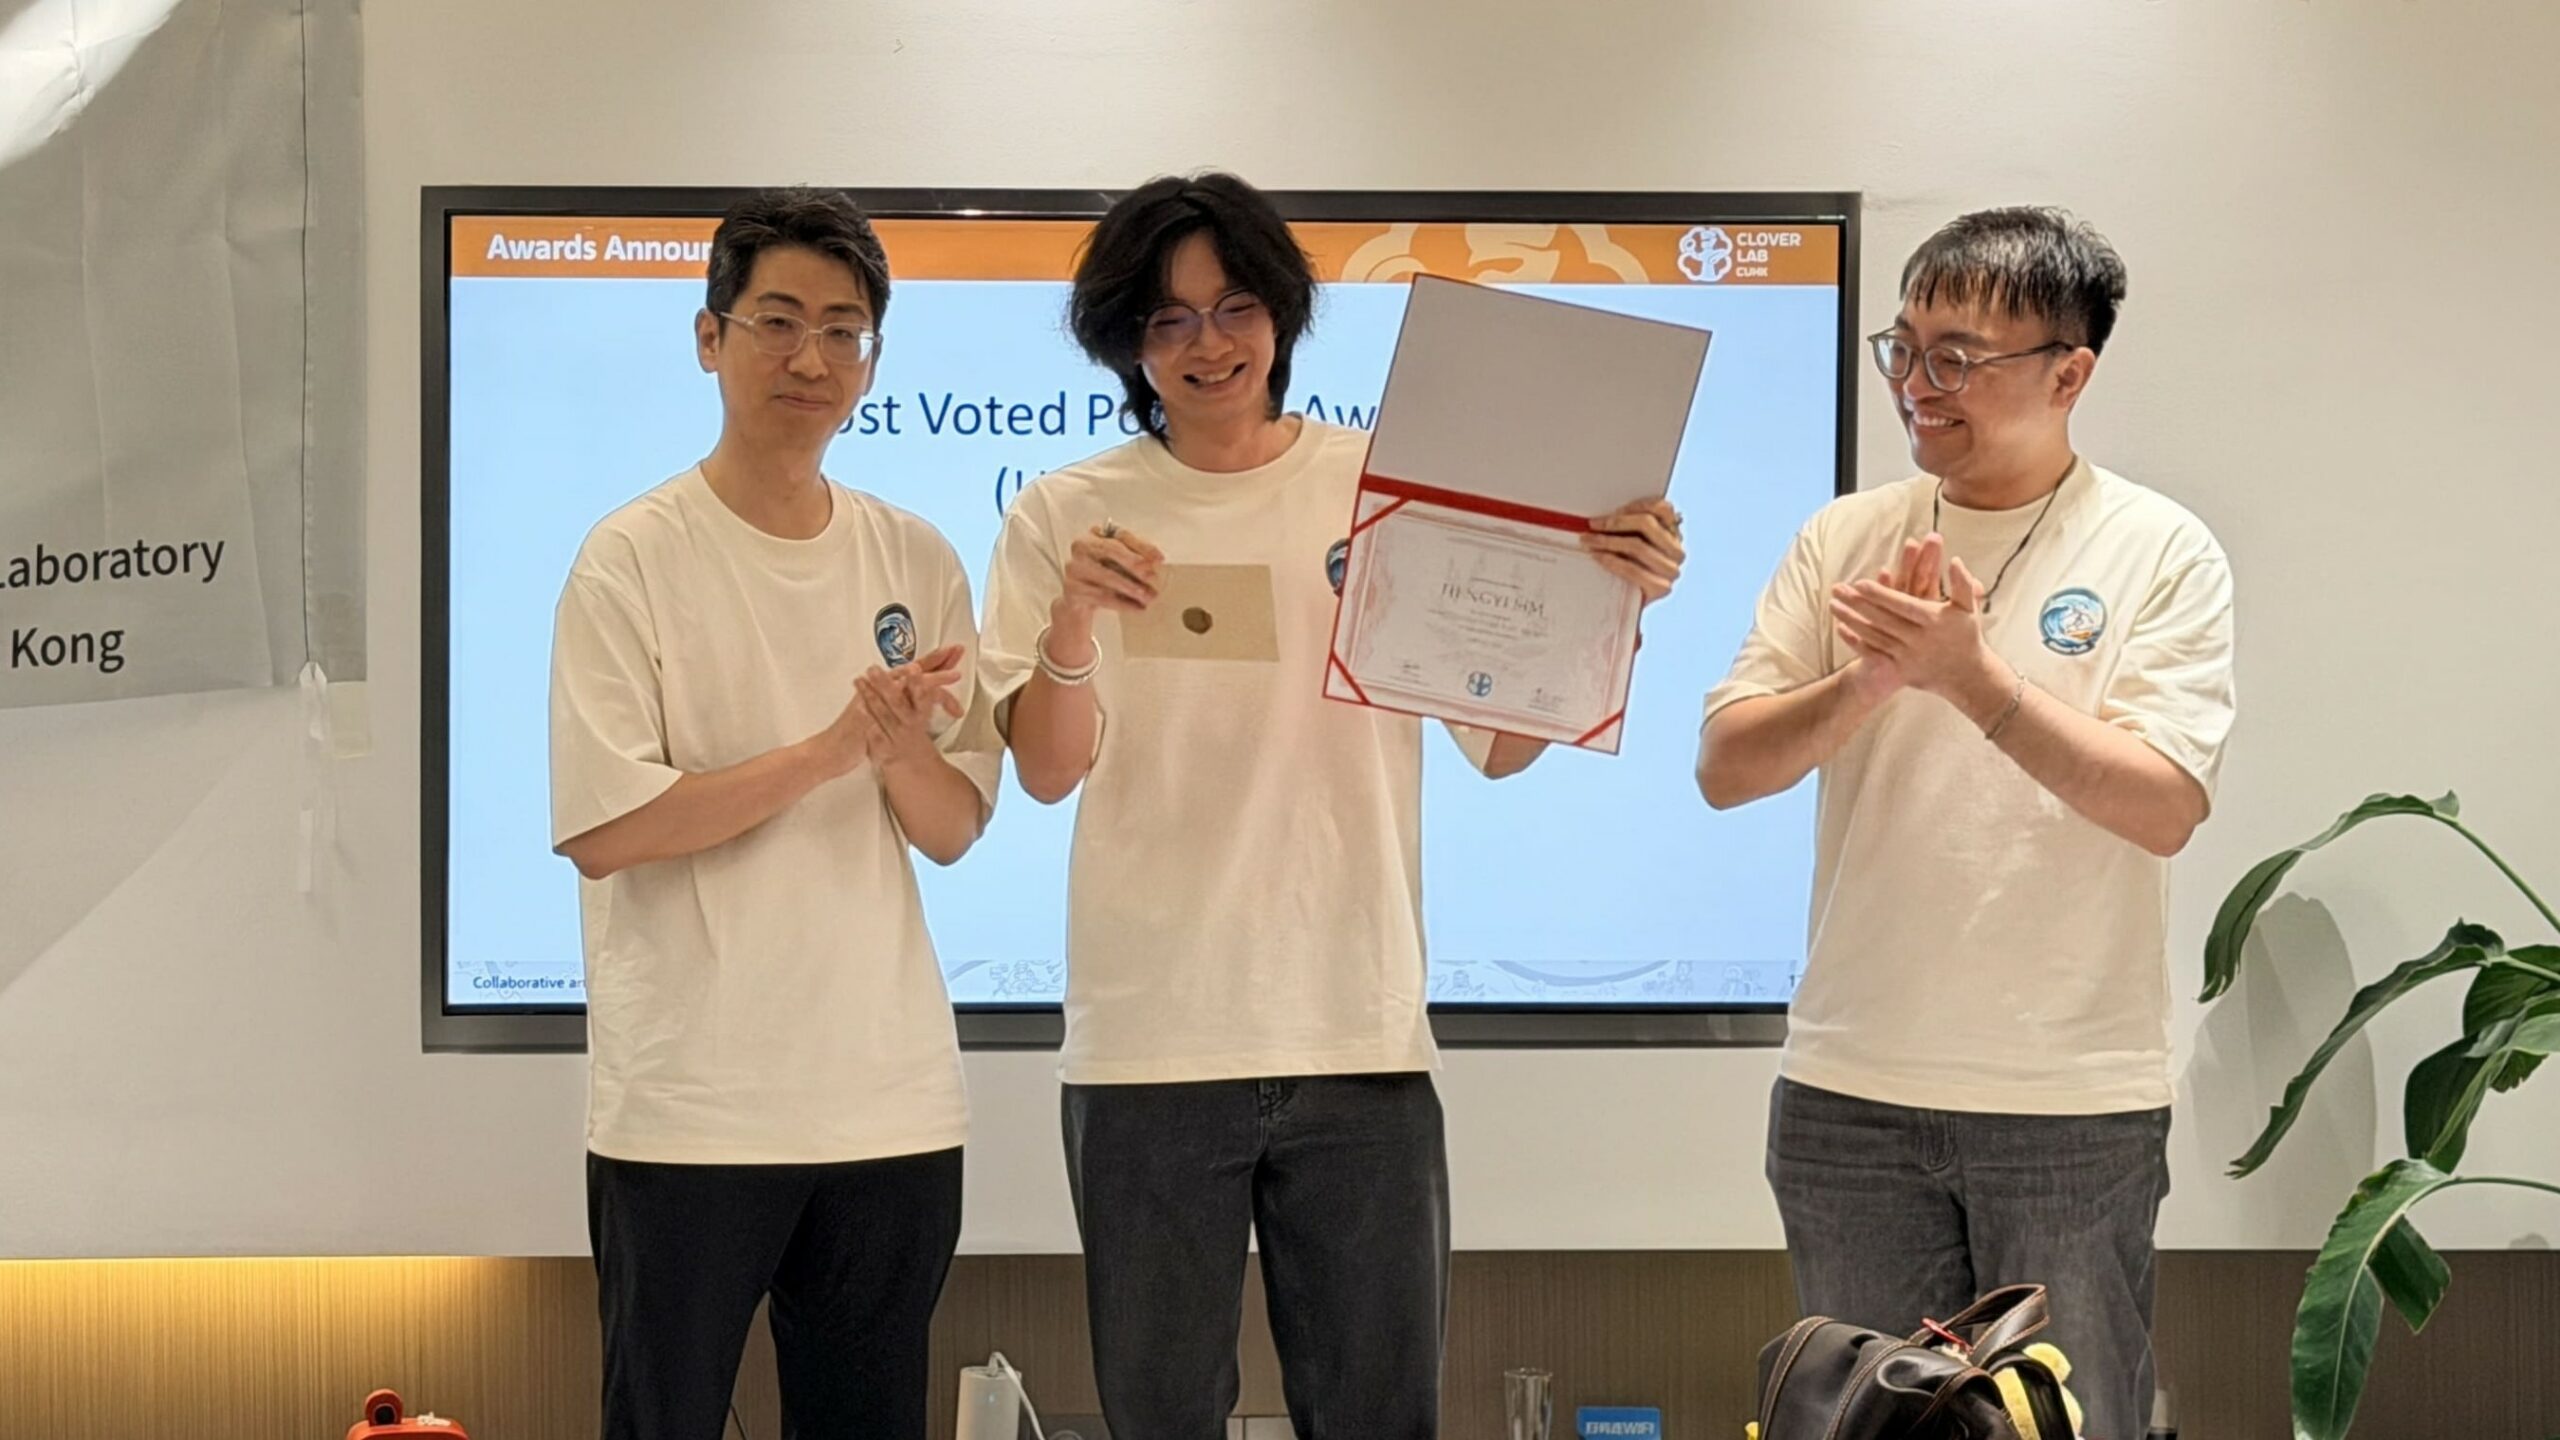
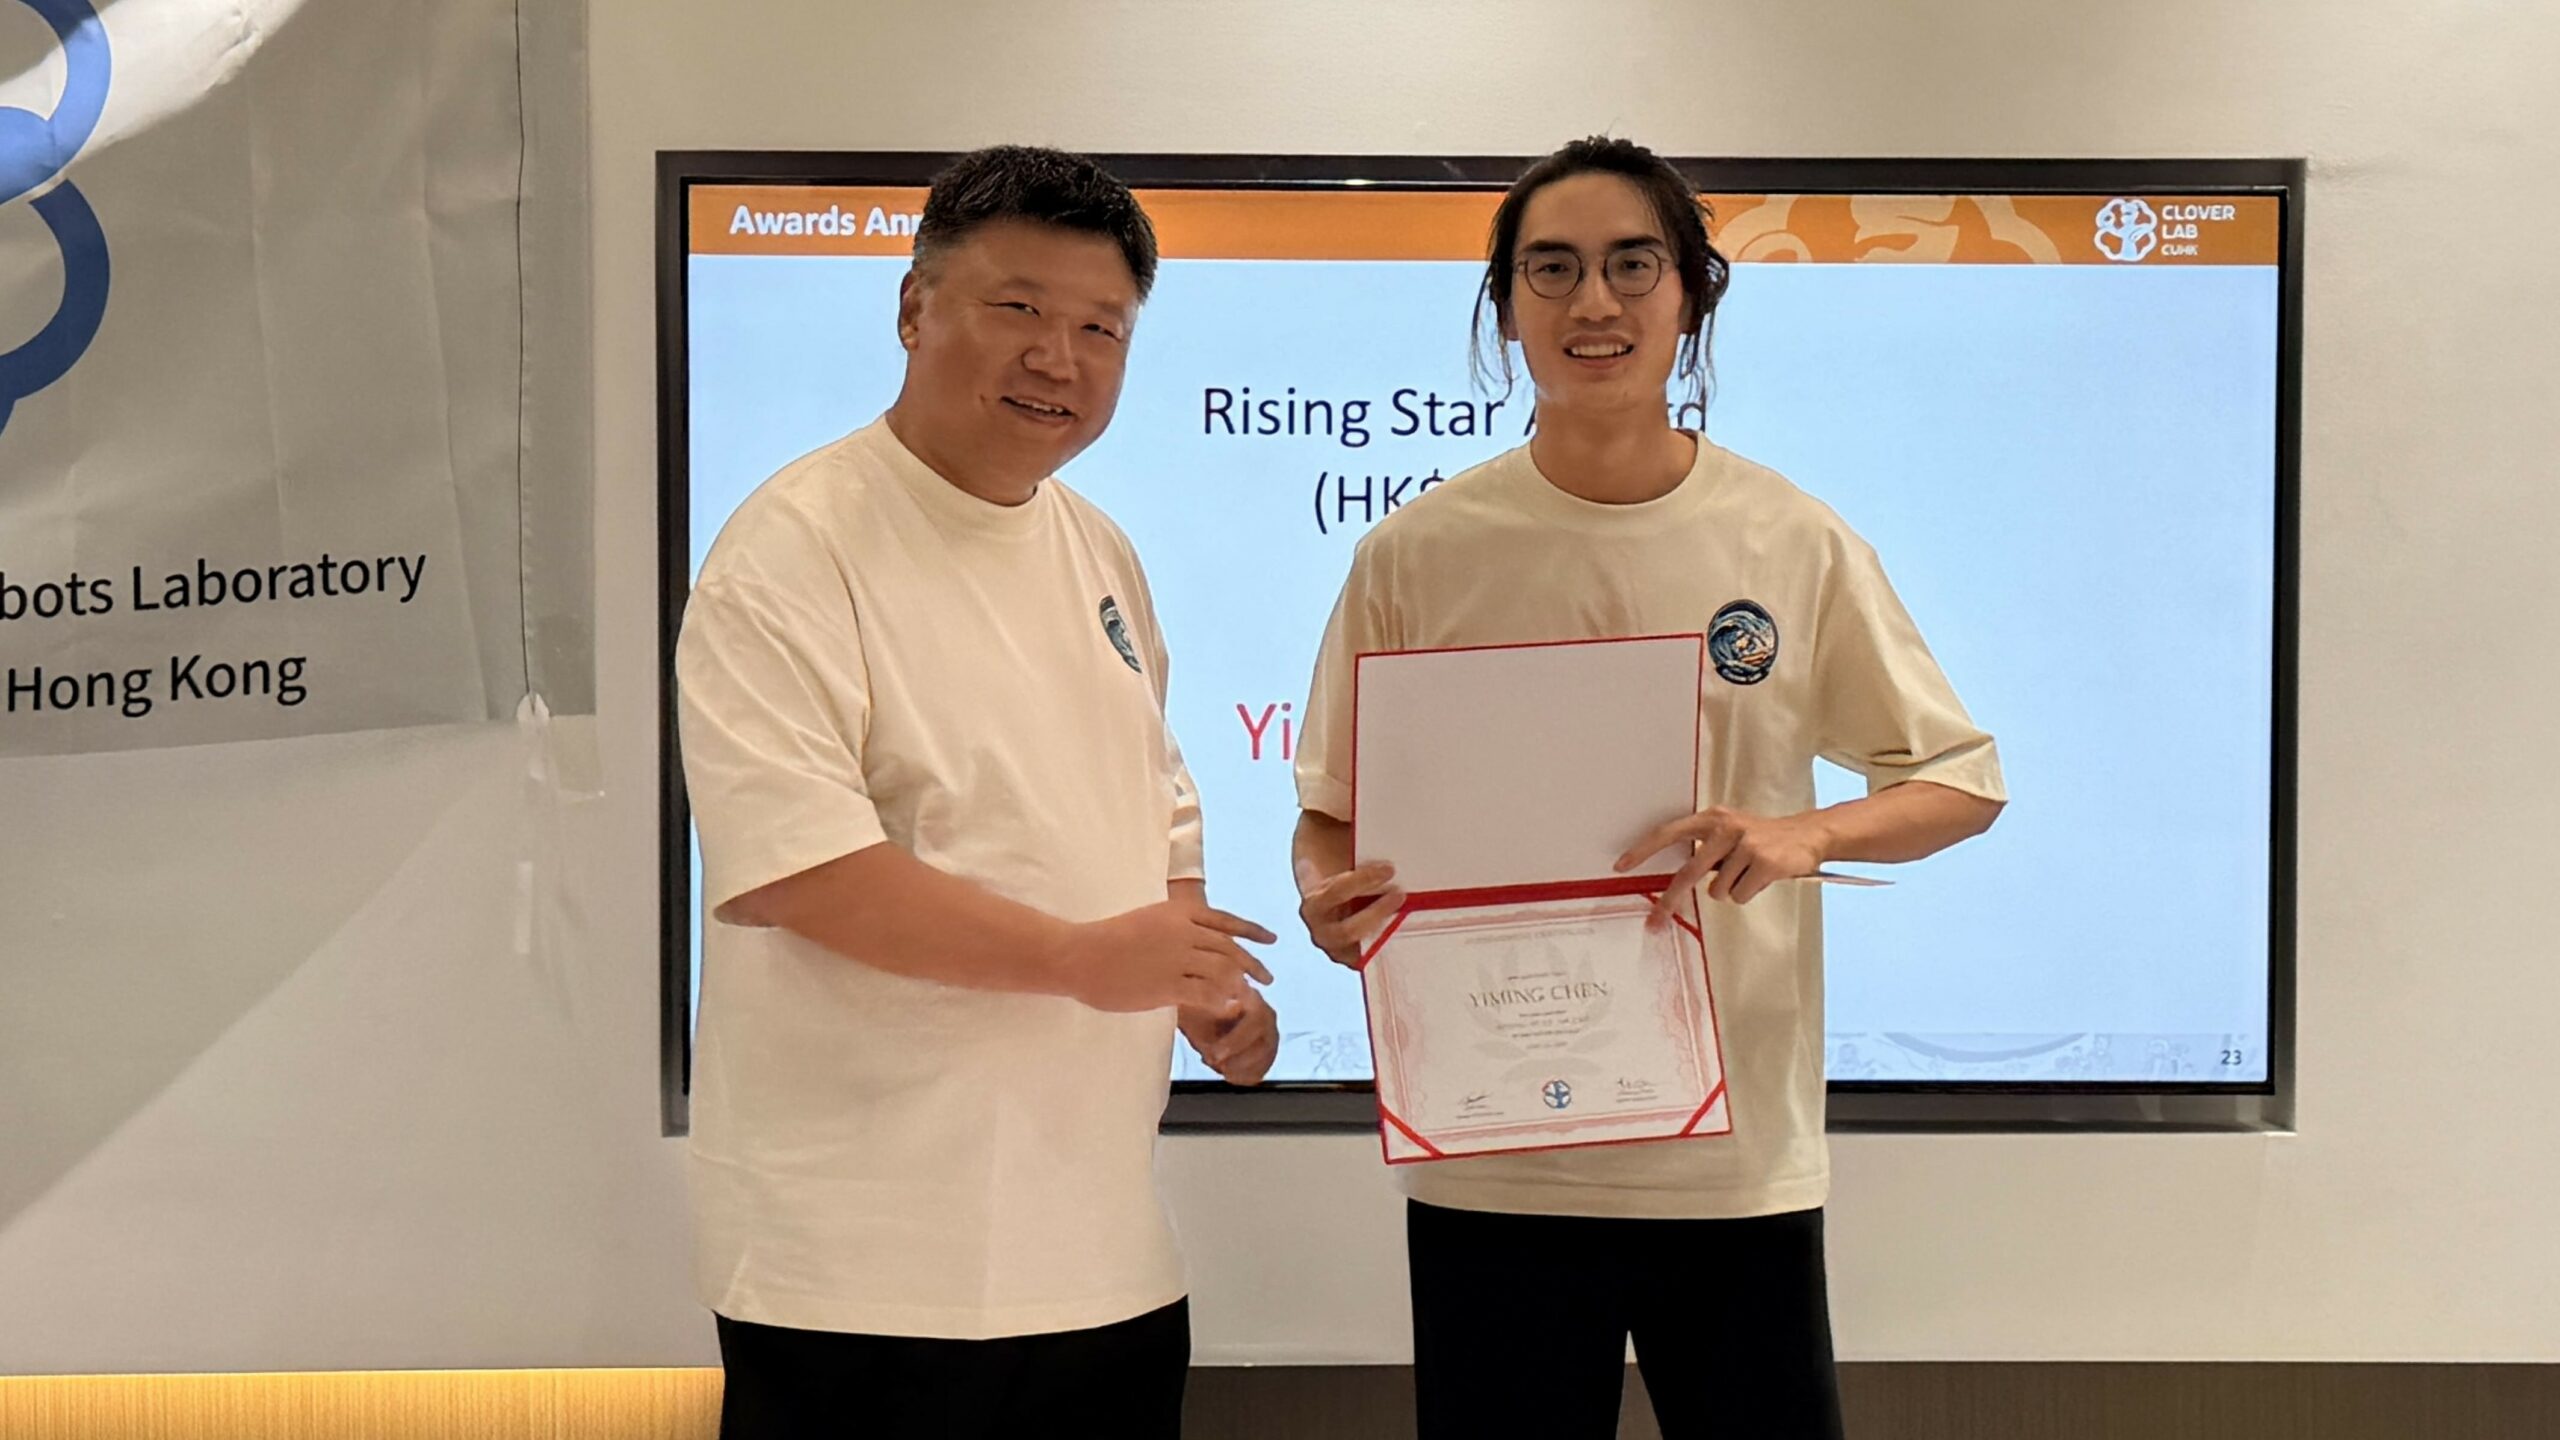
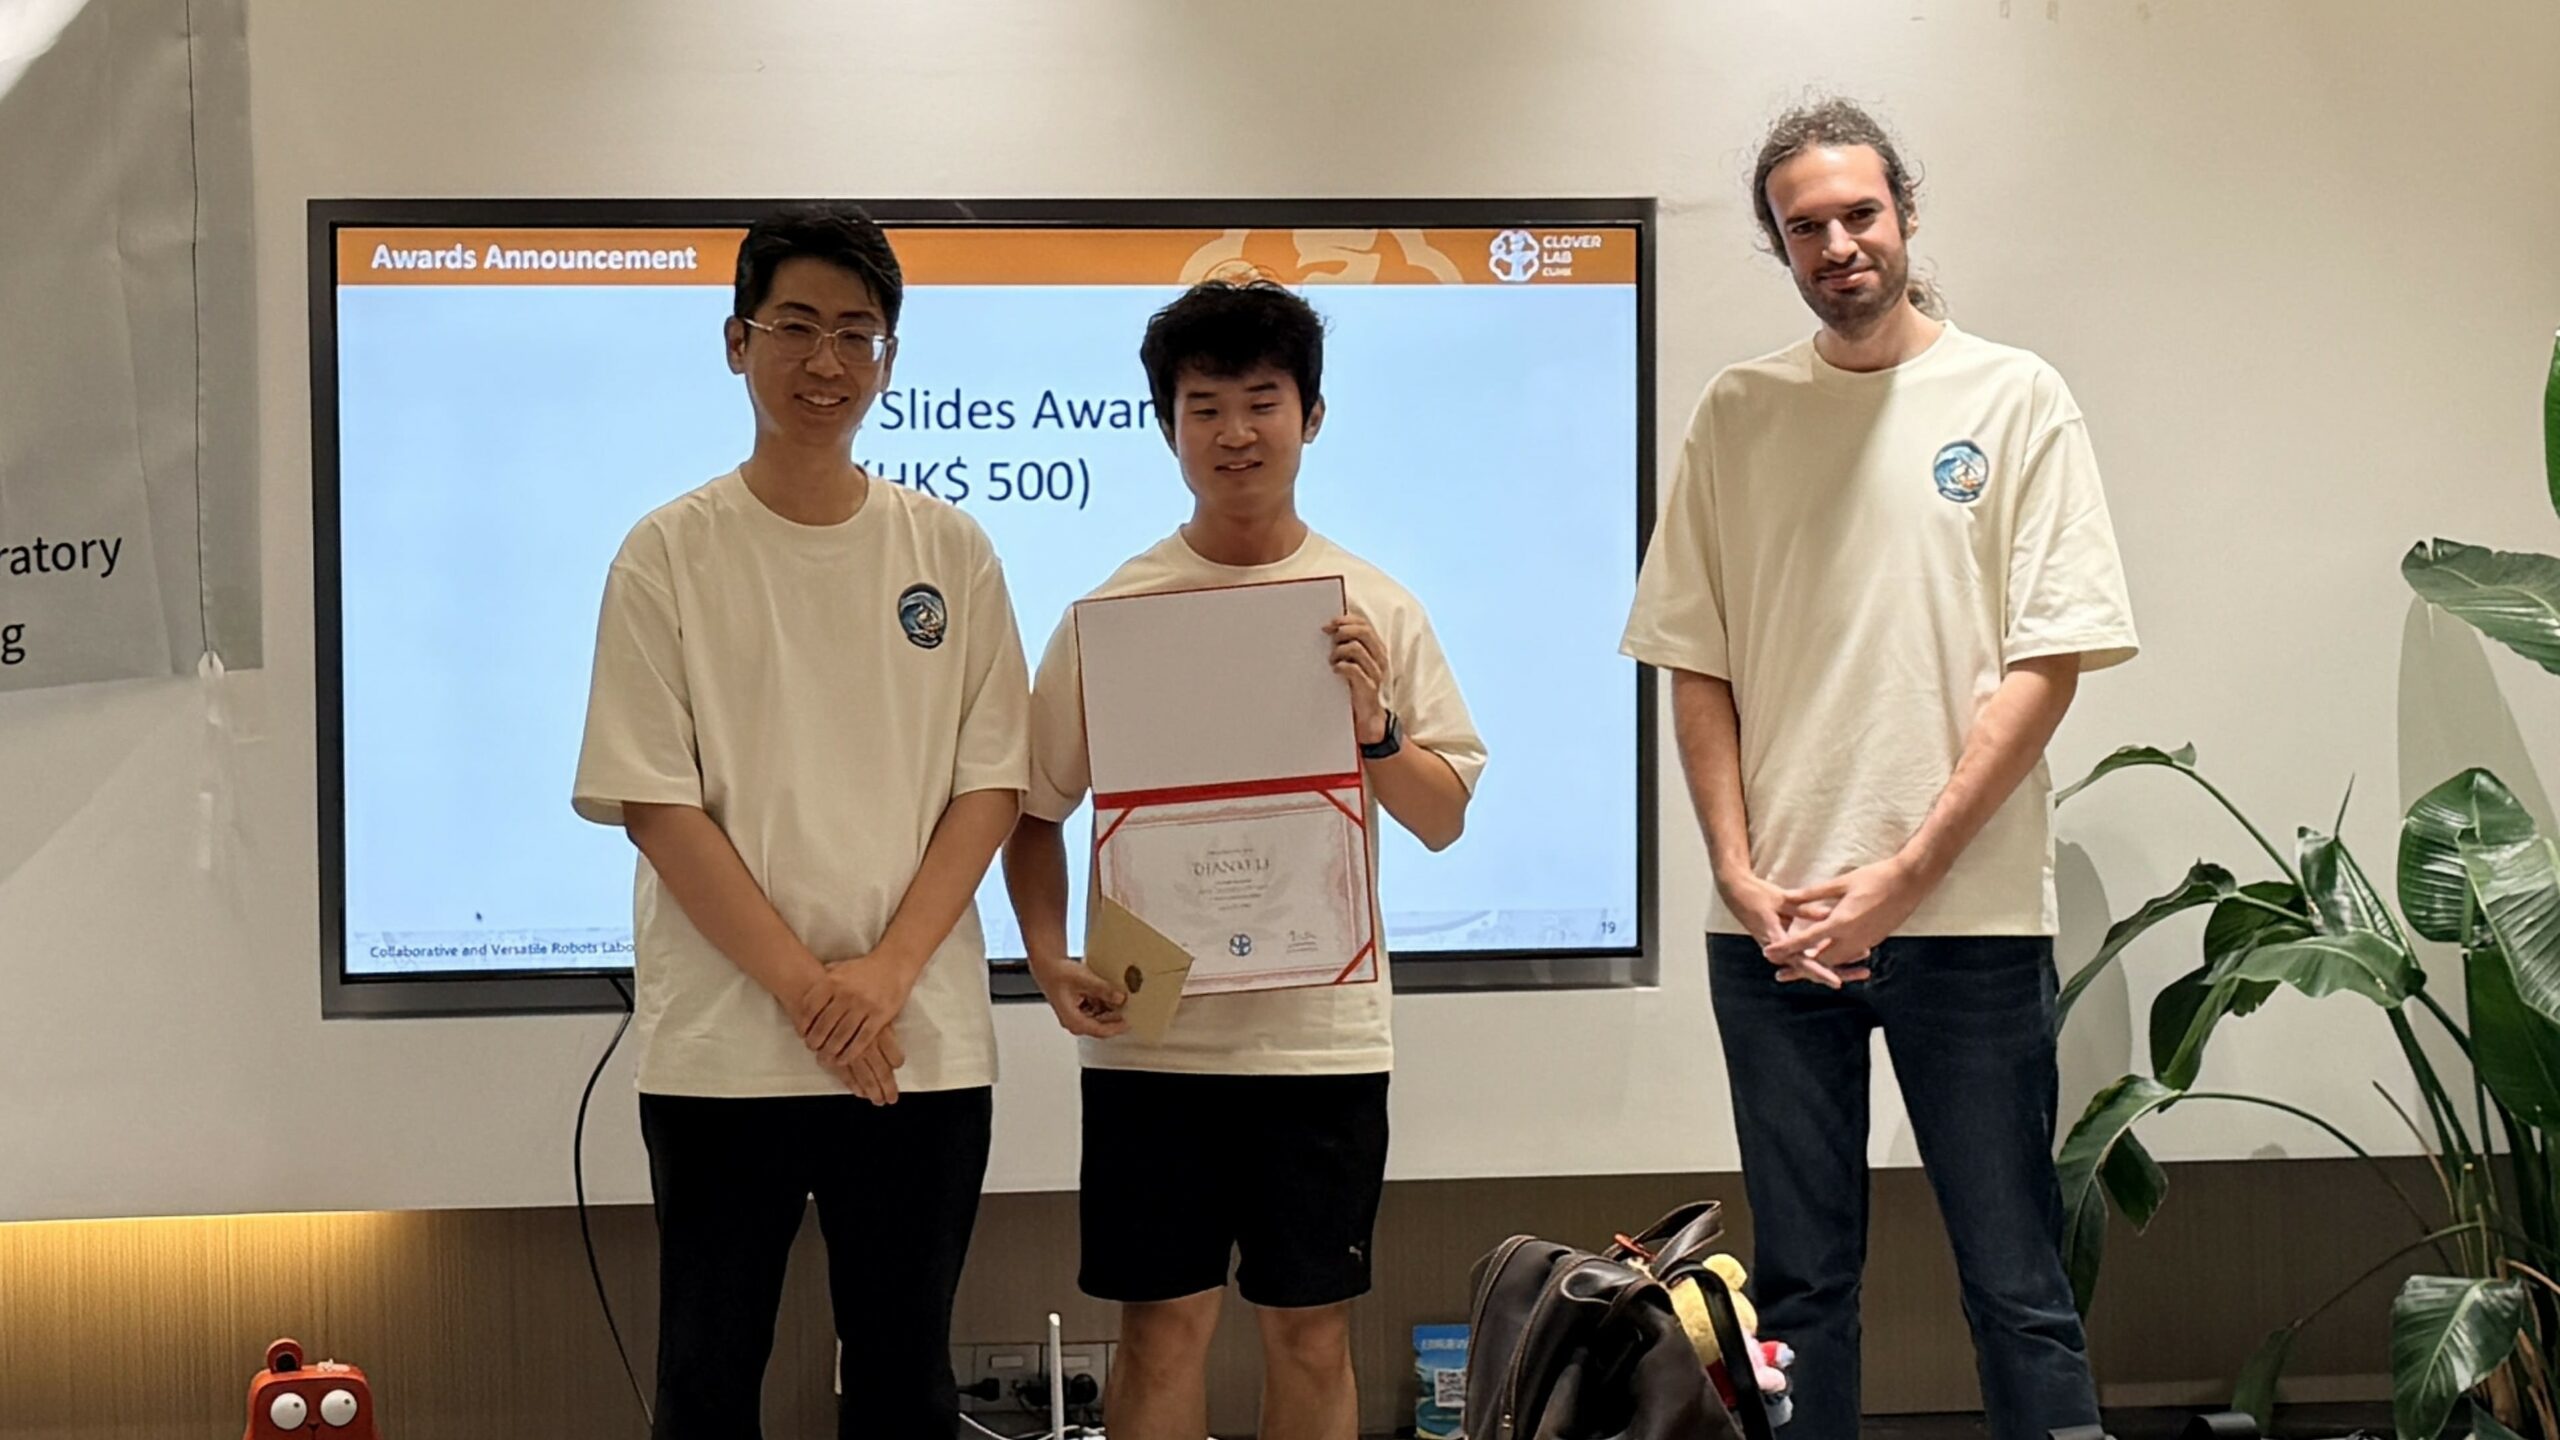
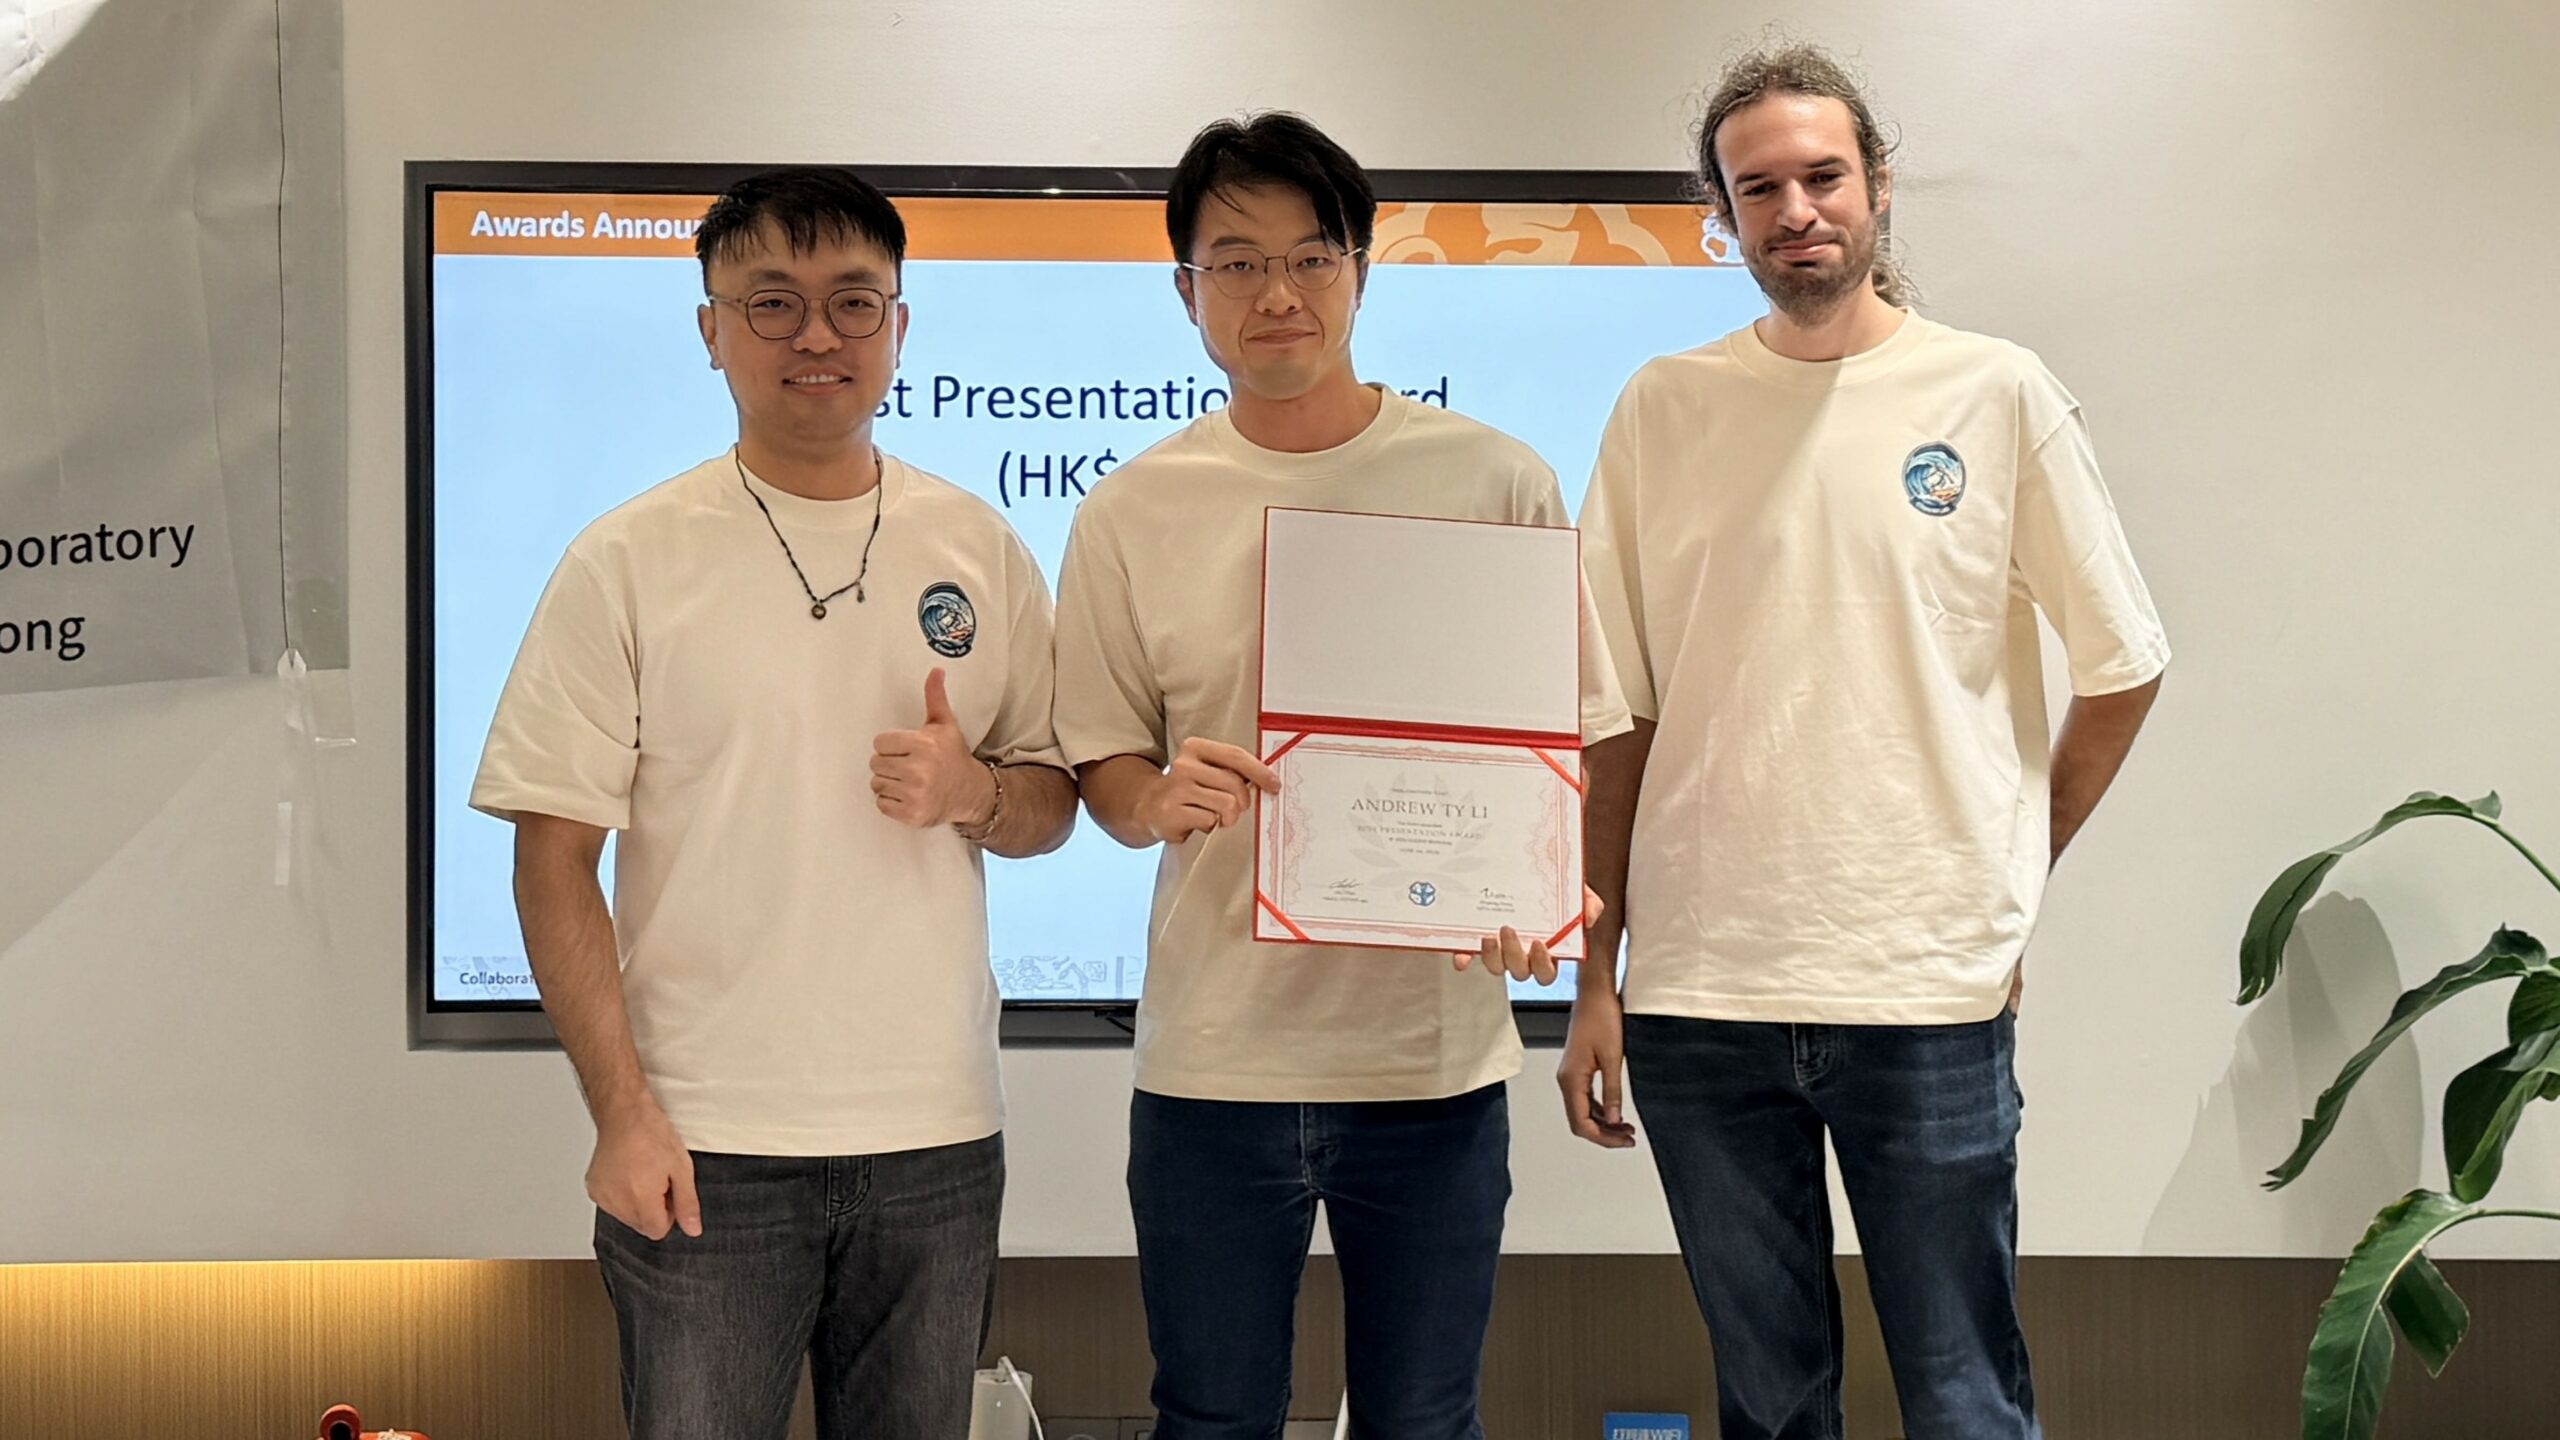
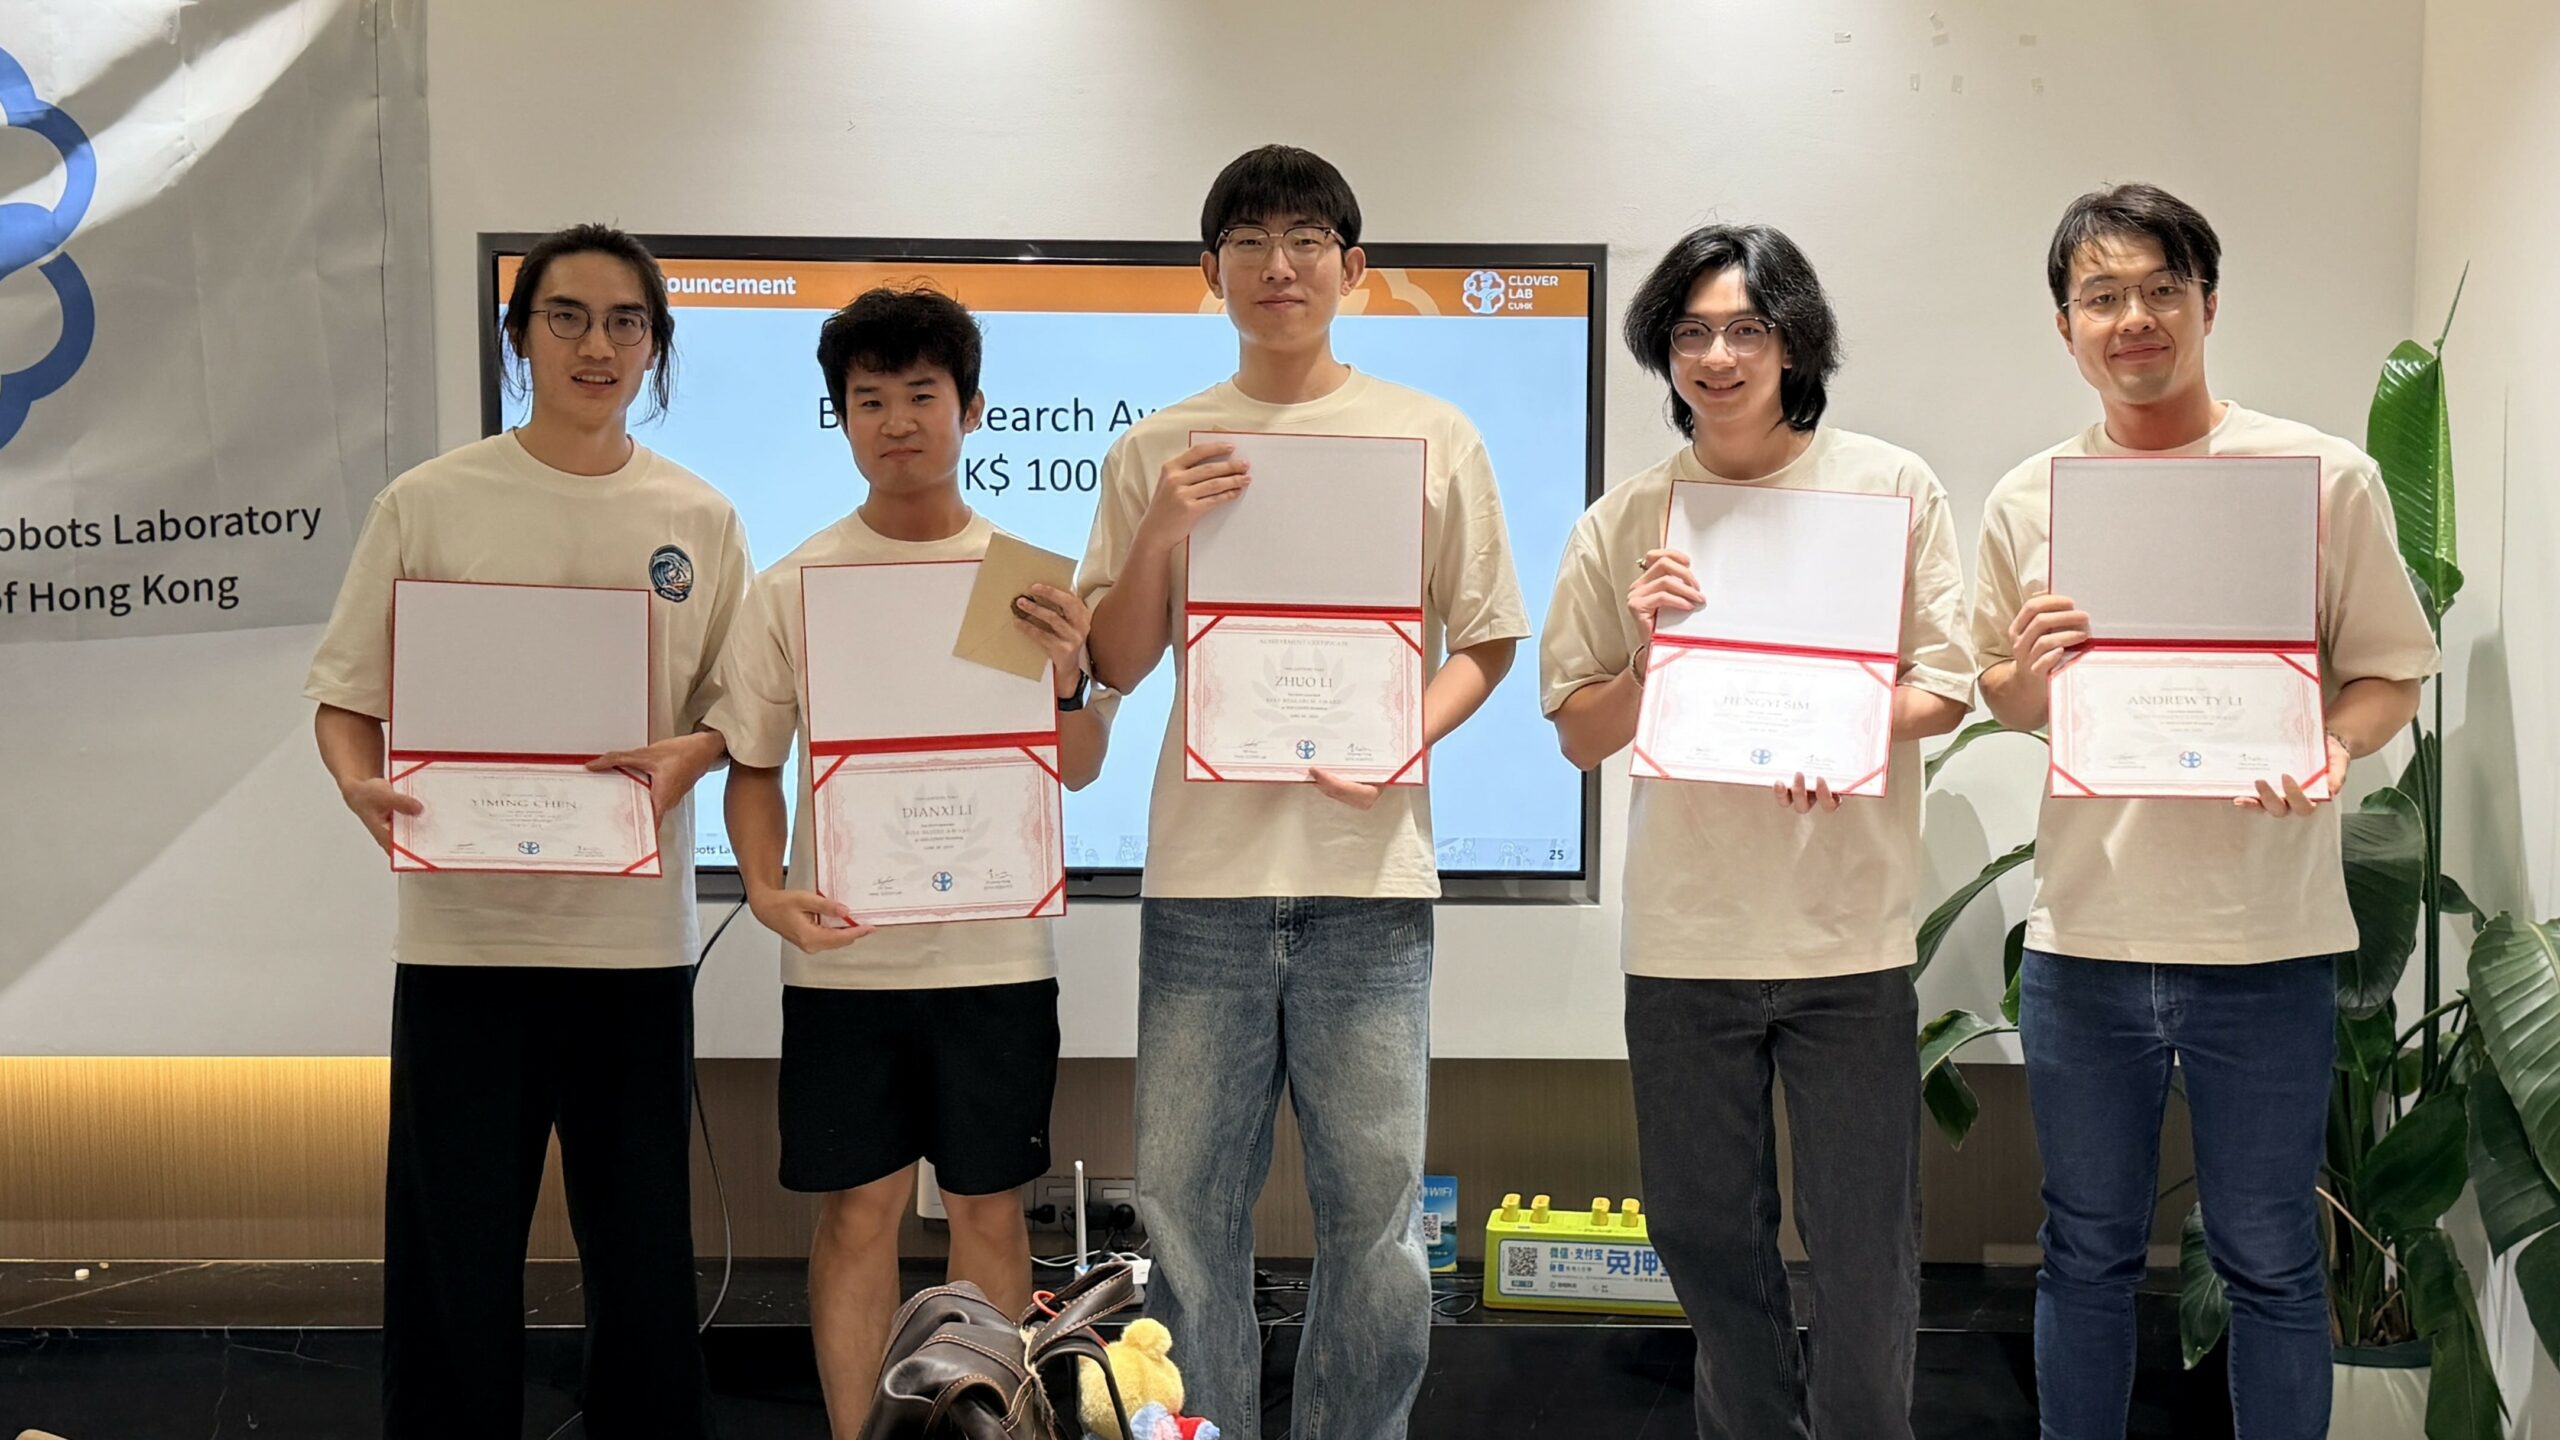
CLOVER Lab Annual Awards
Award Committee Prof. Fei CHEN Dr. Zhipeng DONG Dr. Tao TENG Dr. Quentin ROUXEL | Awardee of Year 2025 – 2026
|
Workshop Swag
 | 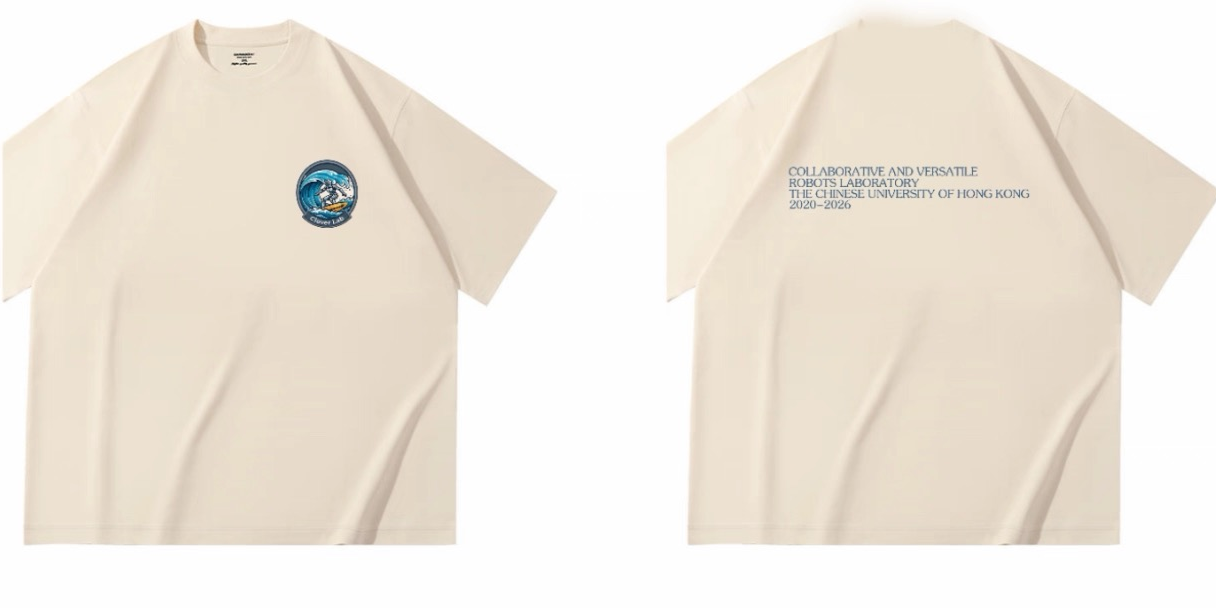 |
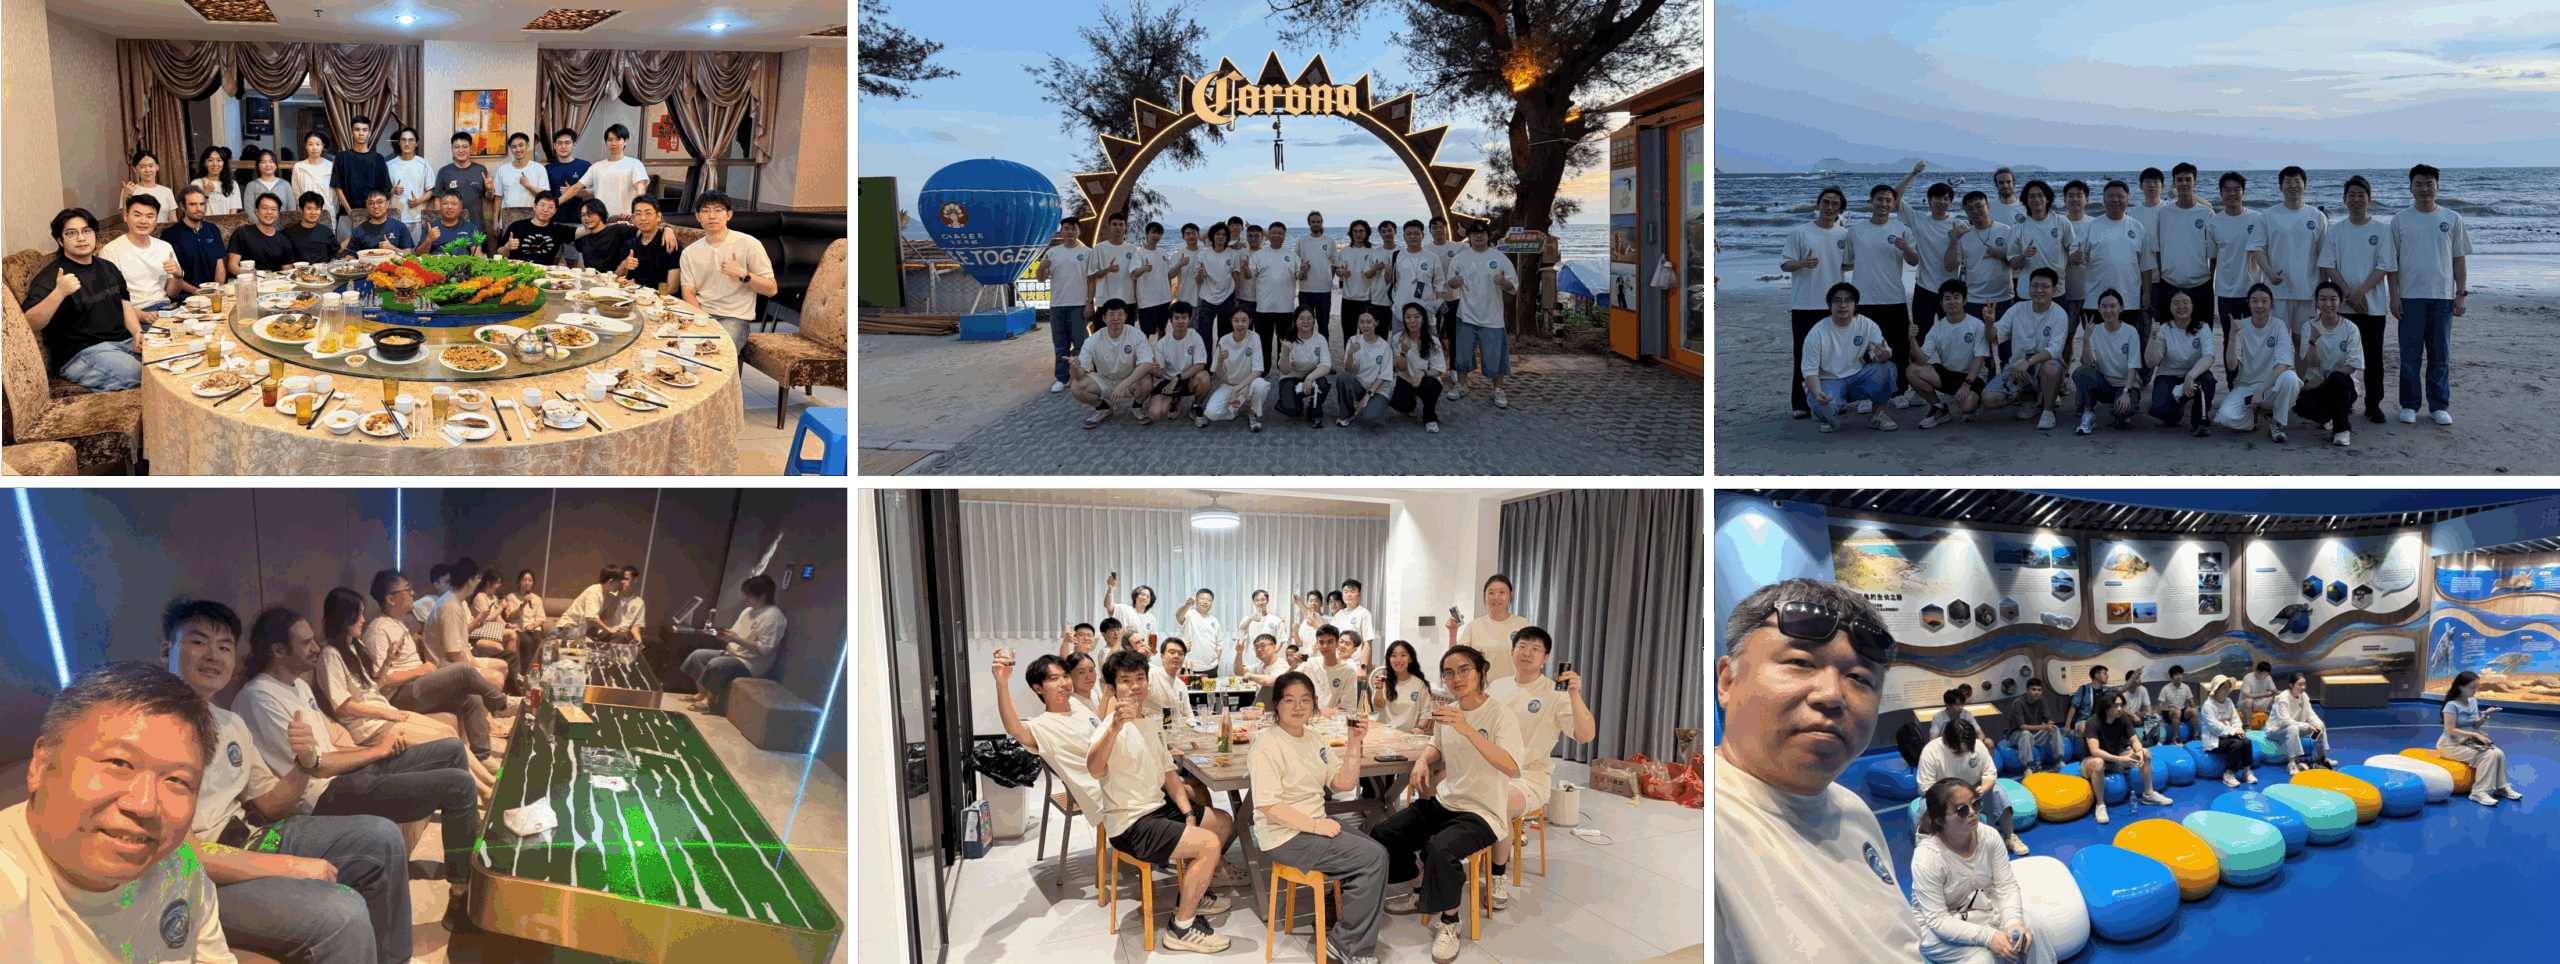
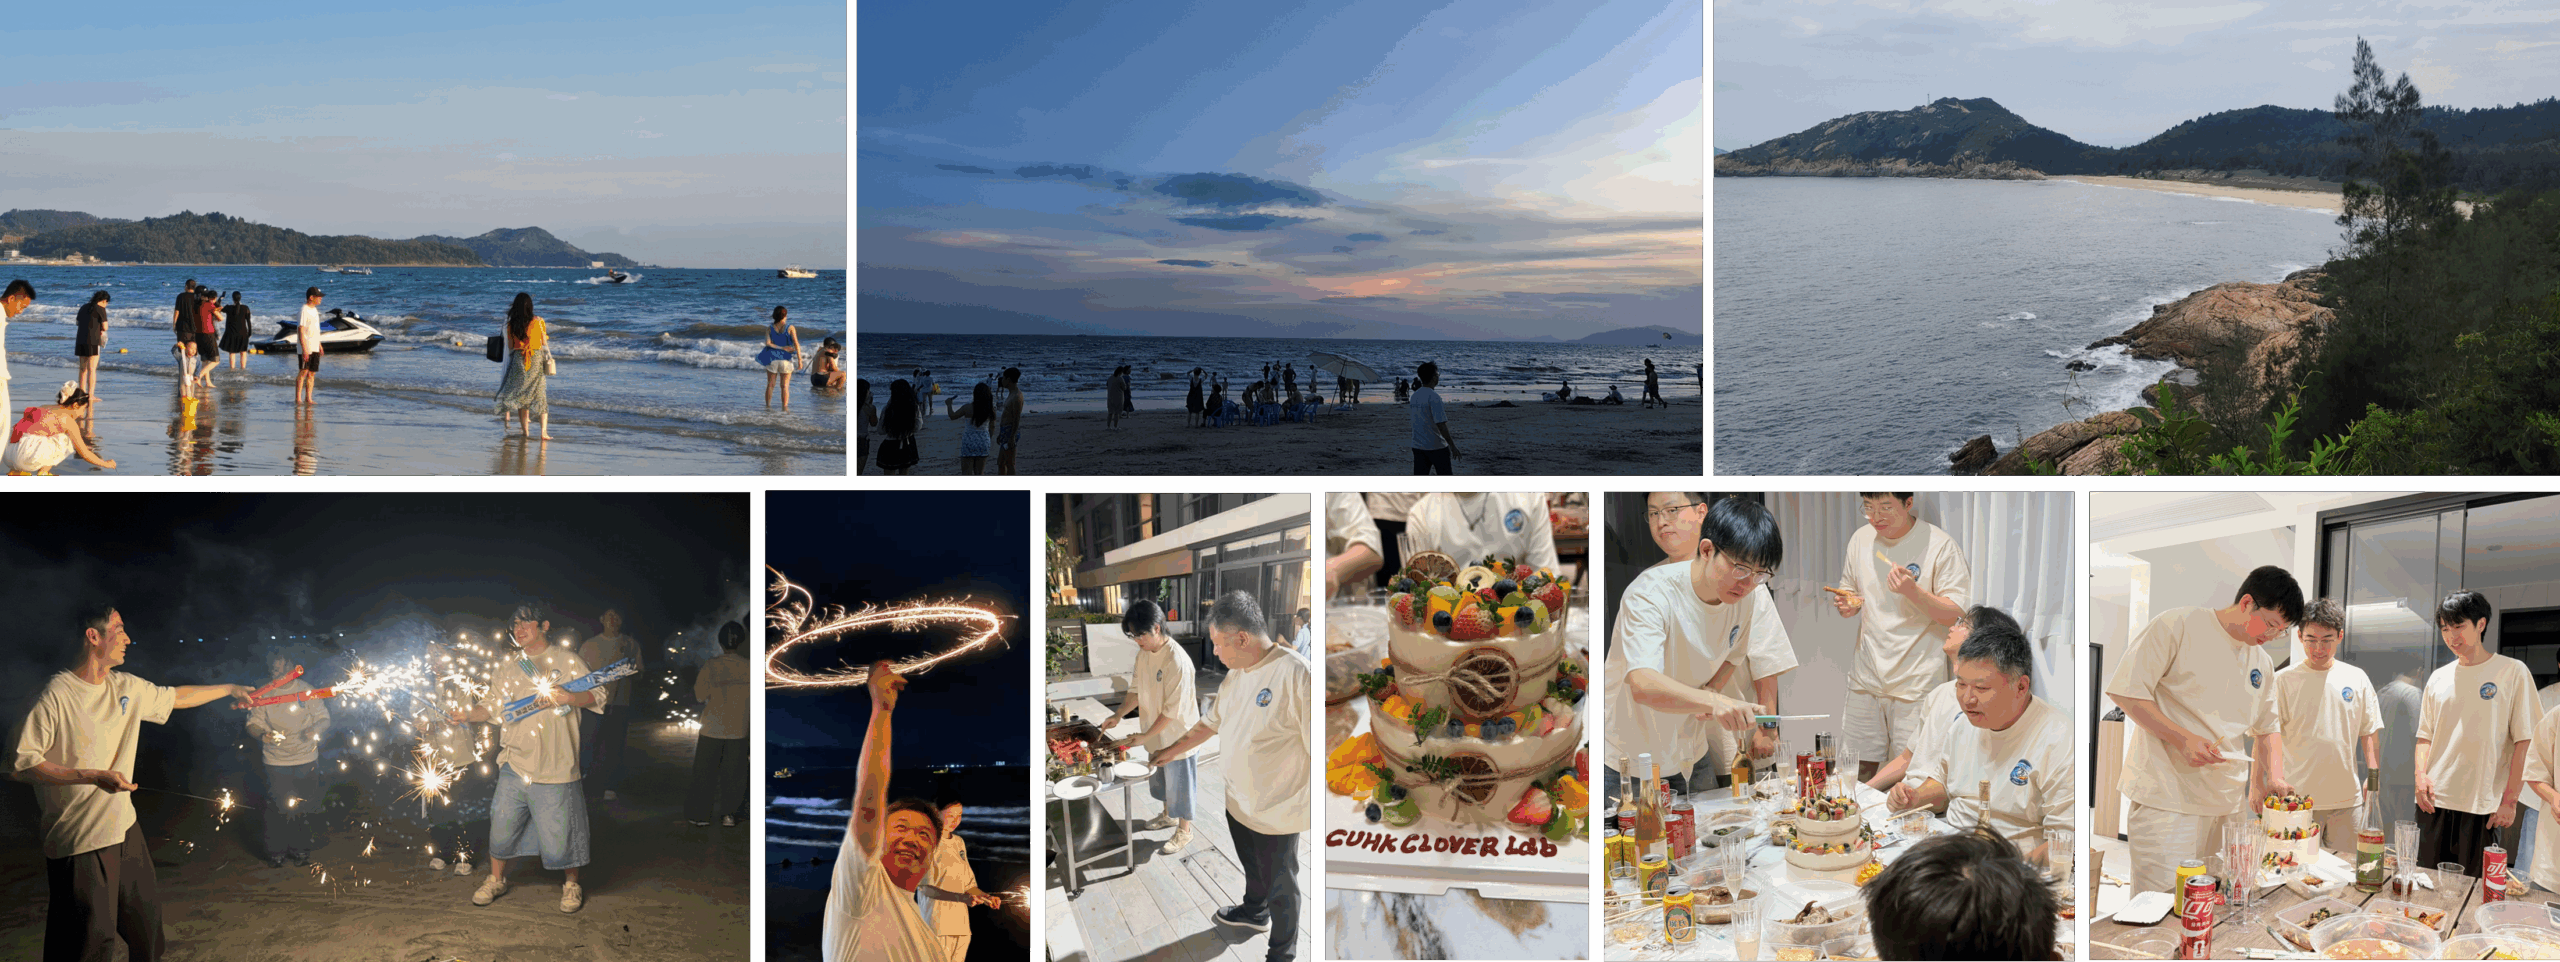
Activity Gallery
Sponsor
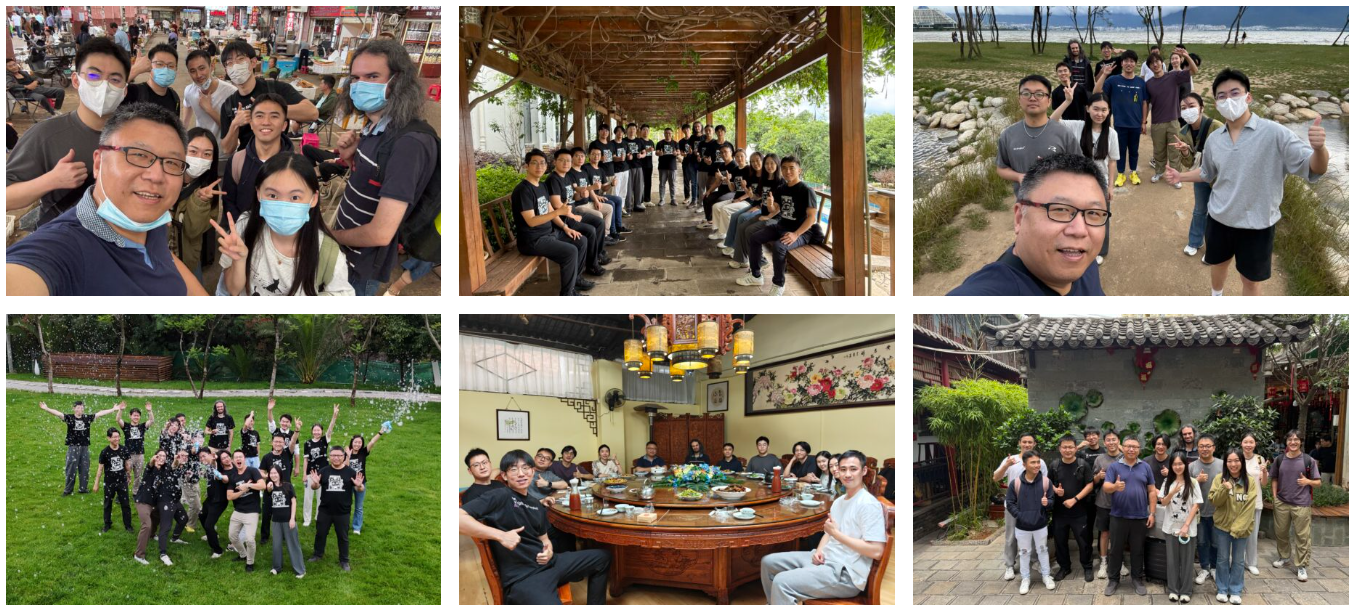
The Clover Lab Annual Workshop 2024-2025 was held in DaLi, China, from June 1st to June 4th, 2025.
Workshop Committee
Program Committee Zhuo LI Xi WU Yiming CHEN | Organization Committee Yuchen YAN Minghao YU |
Program
| June 01 (Sunday) | |
| 9:00-9:30 | Local Culture Experience Yunnan Mushuihua Wild Mushroom Trading Center |
| 12:00-18:00 | Check In |
| June 02 (Monday) | |
| 9:00-9:30 | Welcome Remarks Organization Committee |
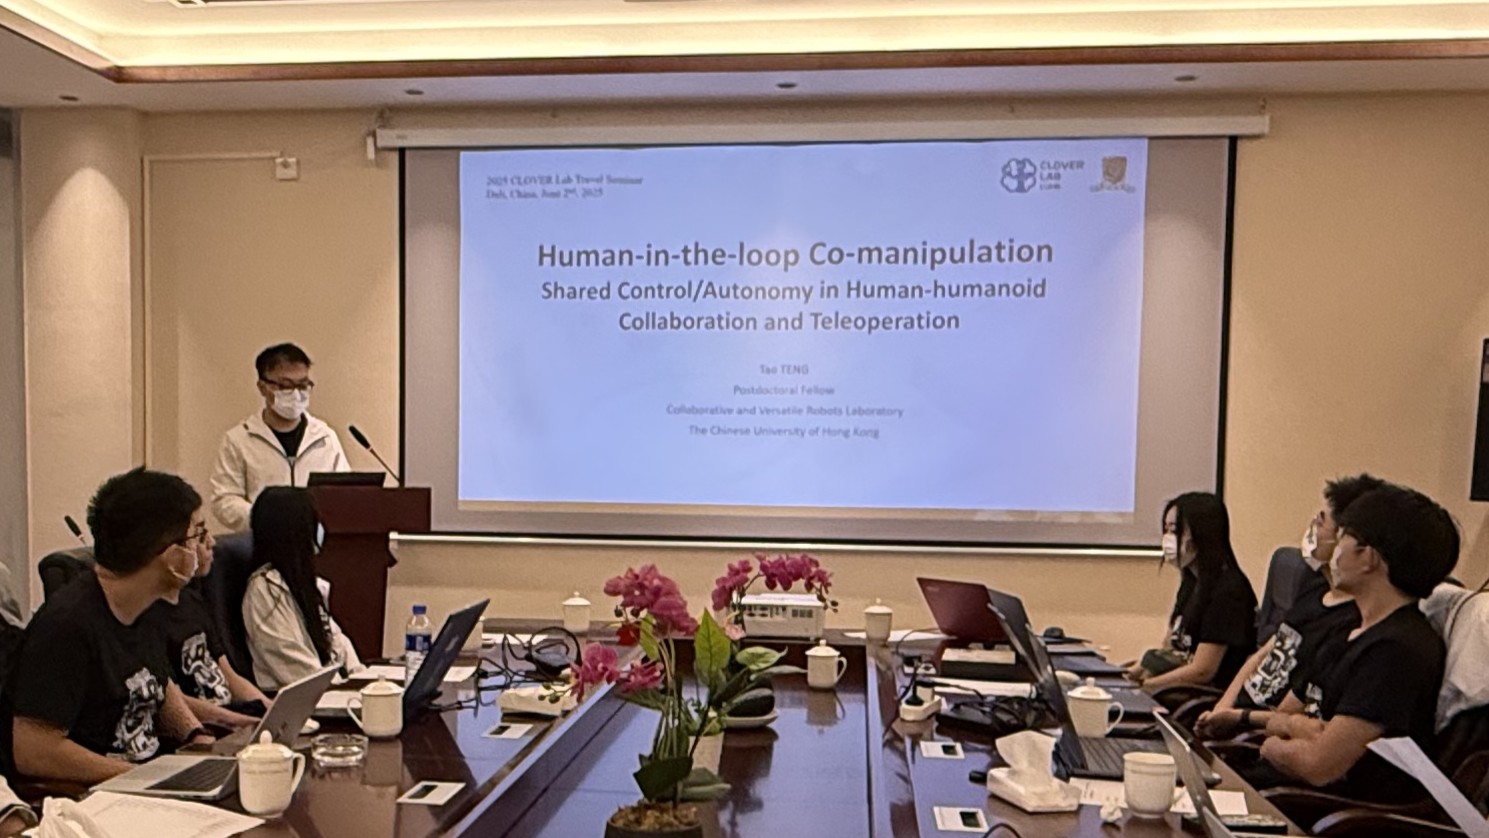
| 9:30-9:45 | Dr. Tao TENG Shared Control/Autonomy in Human-humanoid Collaboration and Teleoperation |
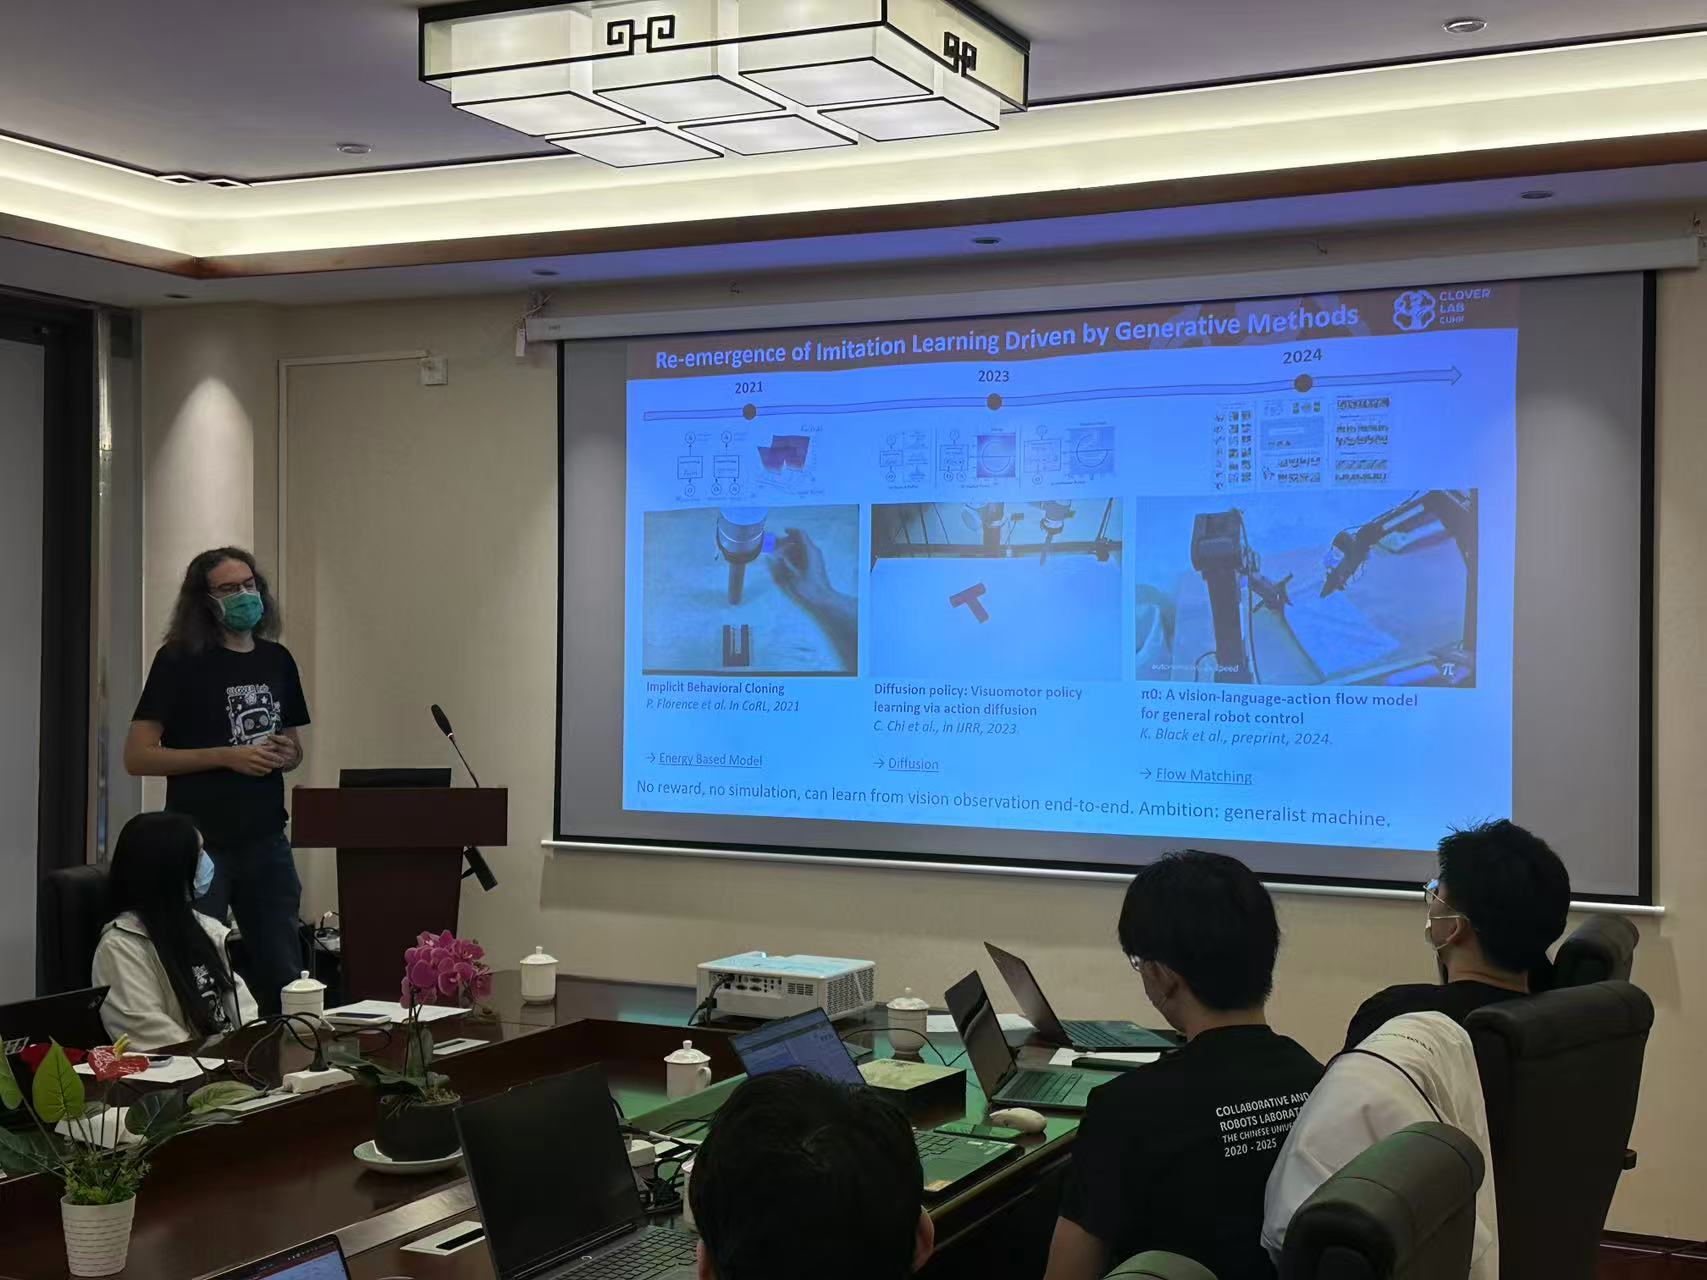
| 9:45-10:00 | Dr. Quentin ROUXEL Multi-Contact and Play Data Imitation Learning with Flow Matching |
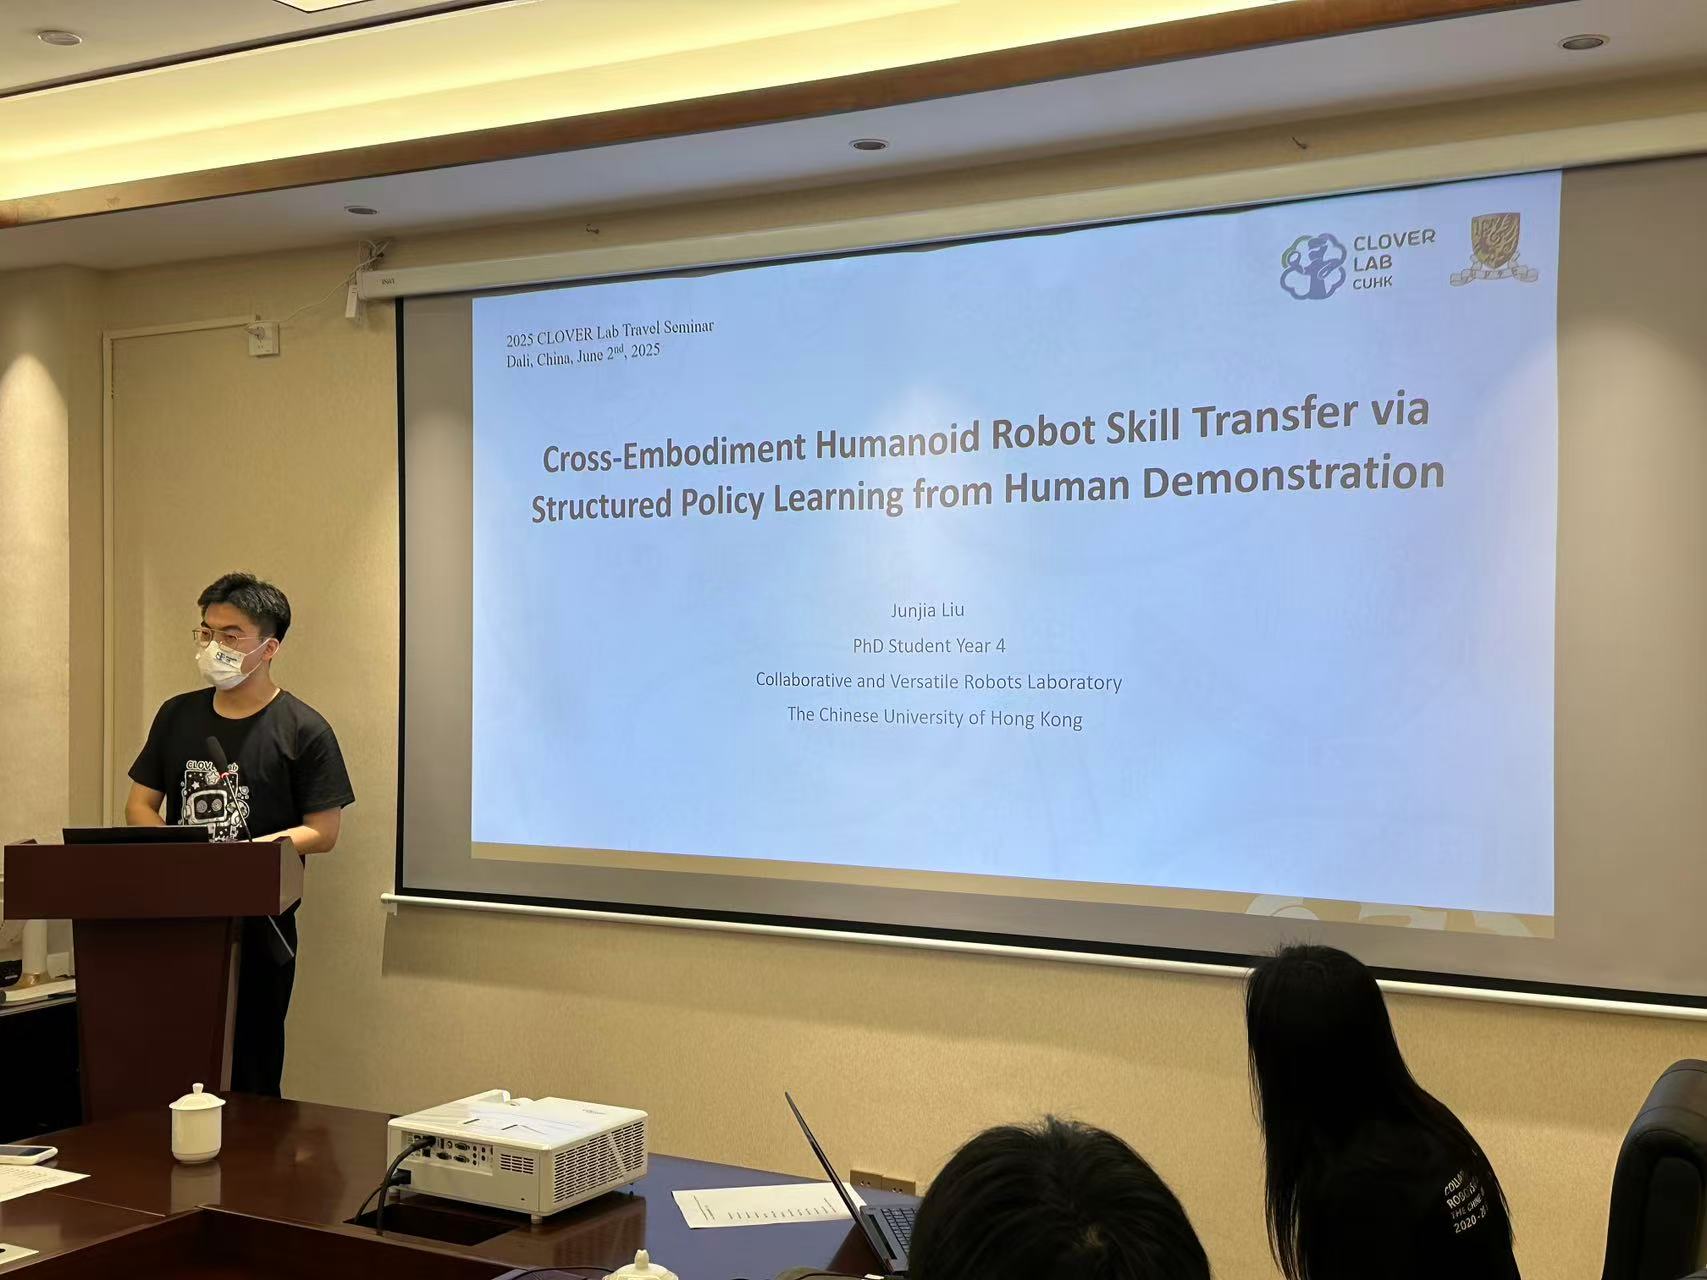
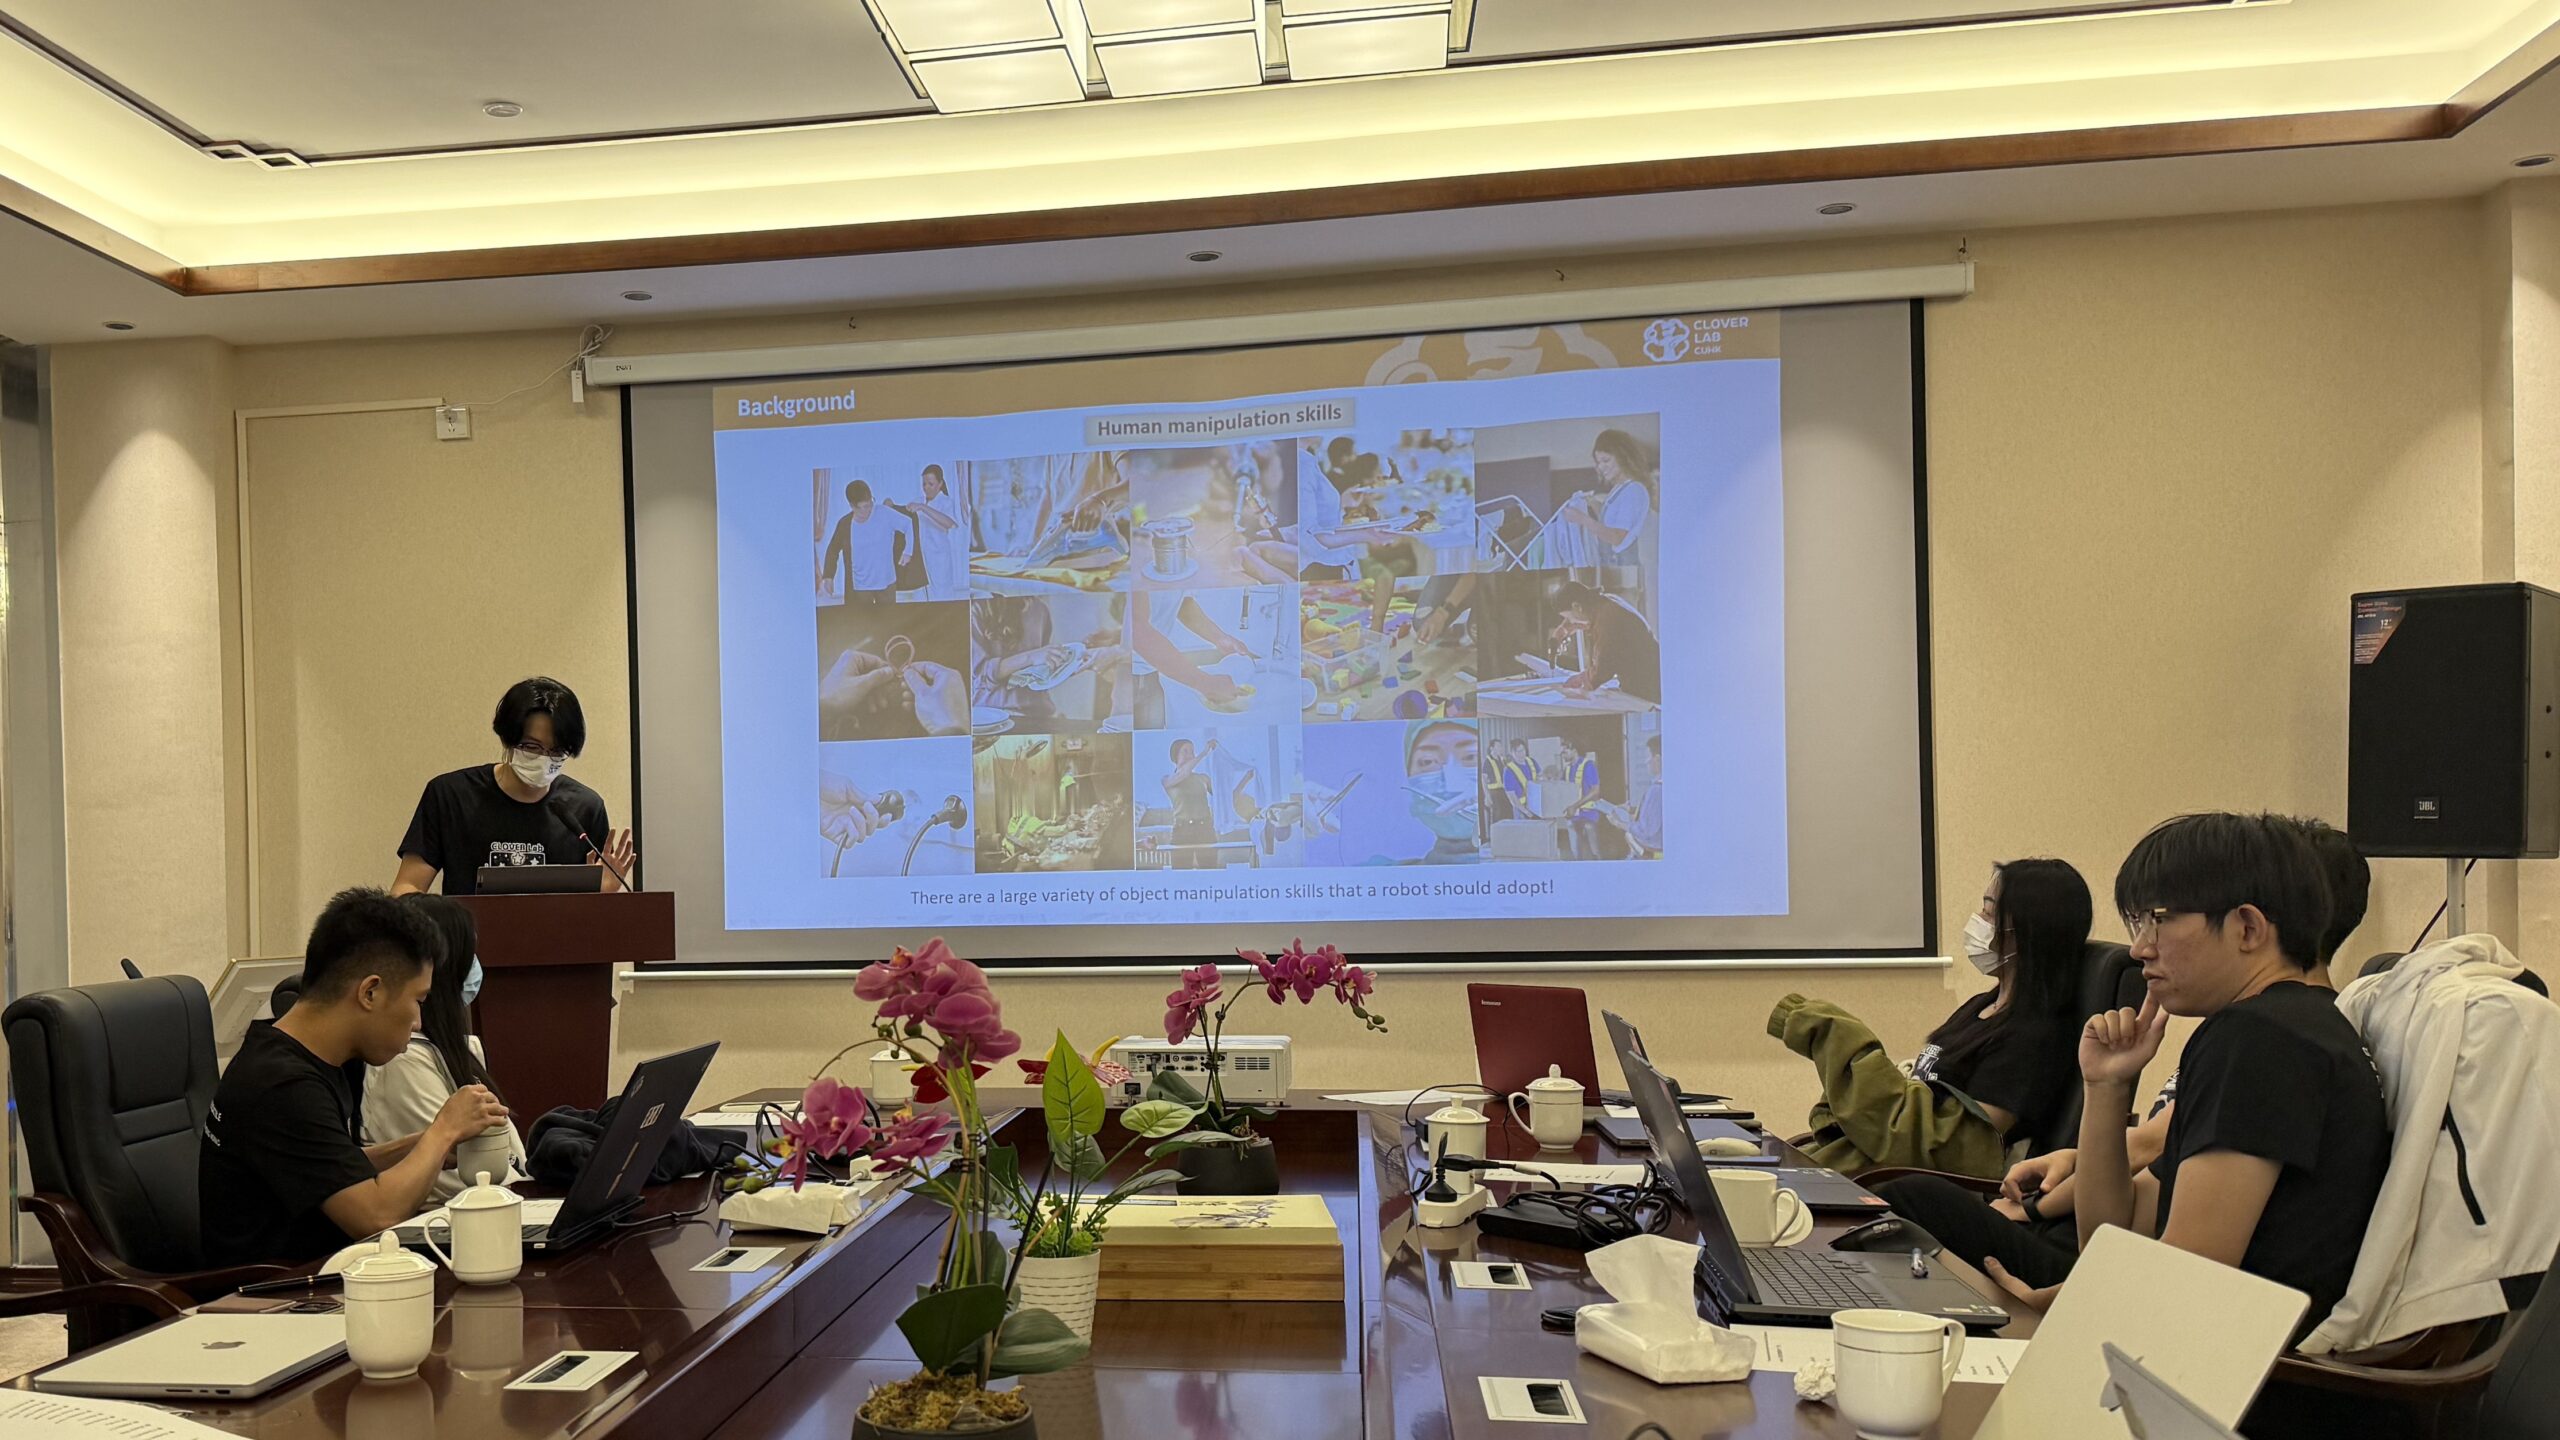
| 10:00-10:15 | Junjia LIU Cross-Embodiment Humanoid Robot Skill Transfer via Structured Policy Learning from Human Demonstration |
| 10:15-10:30 | Zhihao LI Foundation Model for Robot Ergodic Manipulation |
| 10:30-11:00 | Coffee Break |
| 11:00-11:15 | Hengyi SIM Learning Robot Dynamic Cloth Manipulation Based on Differentiable Dynamics Optimization and Motion Transfer |
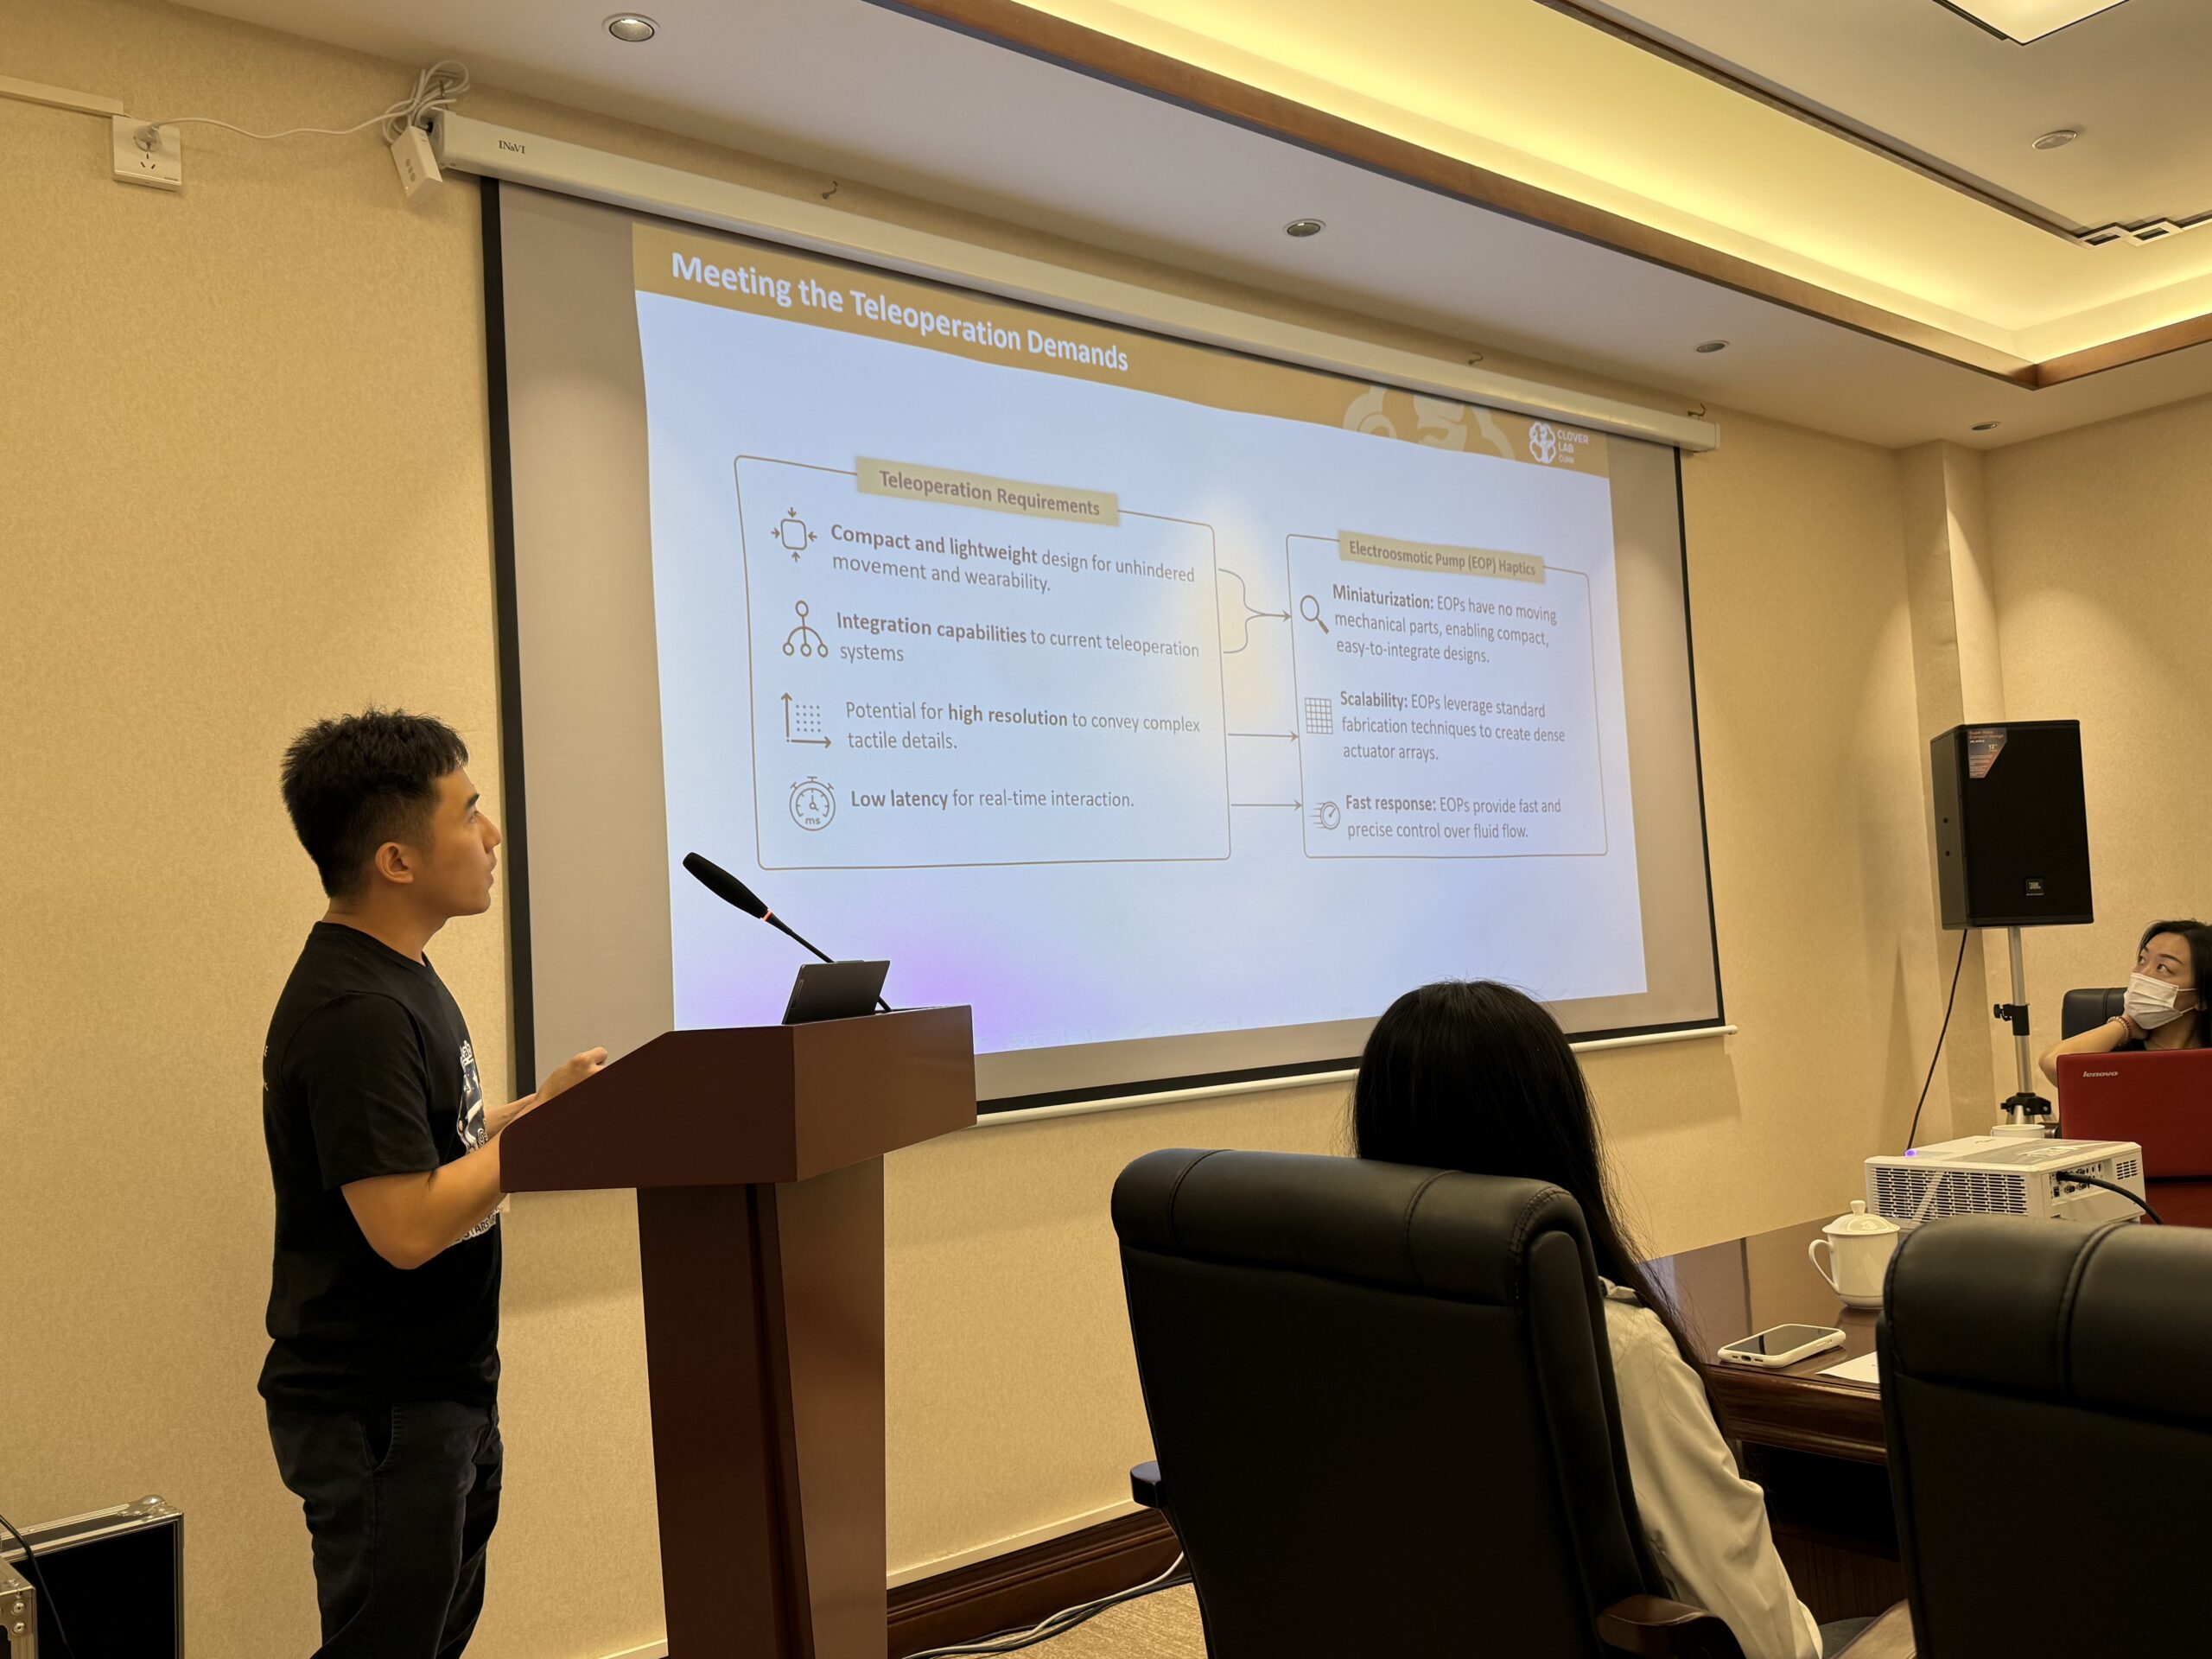
| 11:15-11:30 | Mark Lester Francisco Padilla Design and Development of Wearable Fluid Haptics for Enhanced Teleoperation |
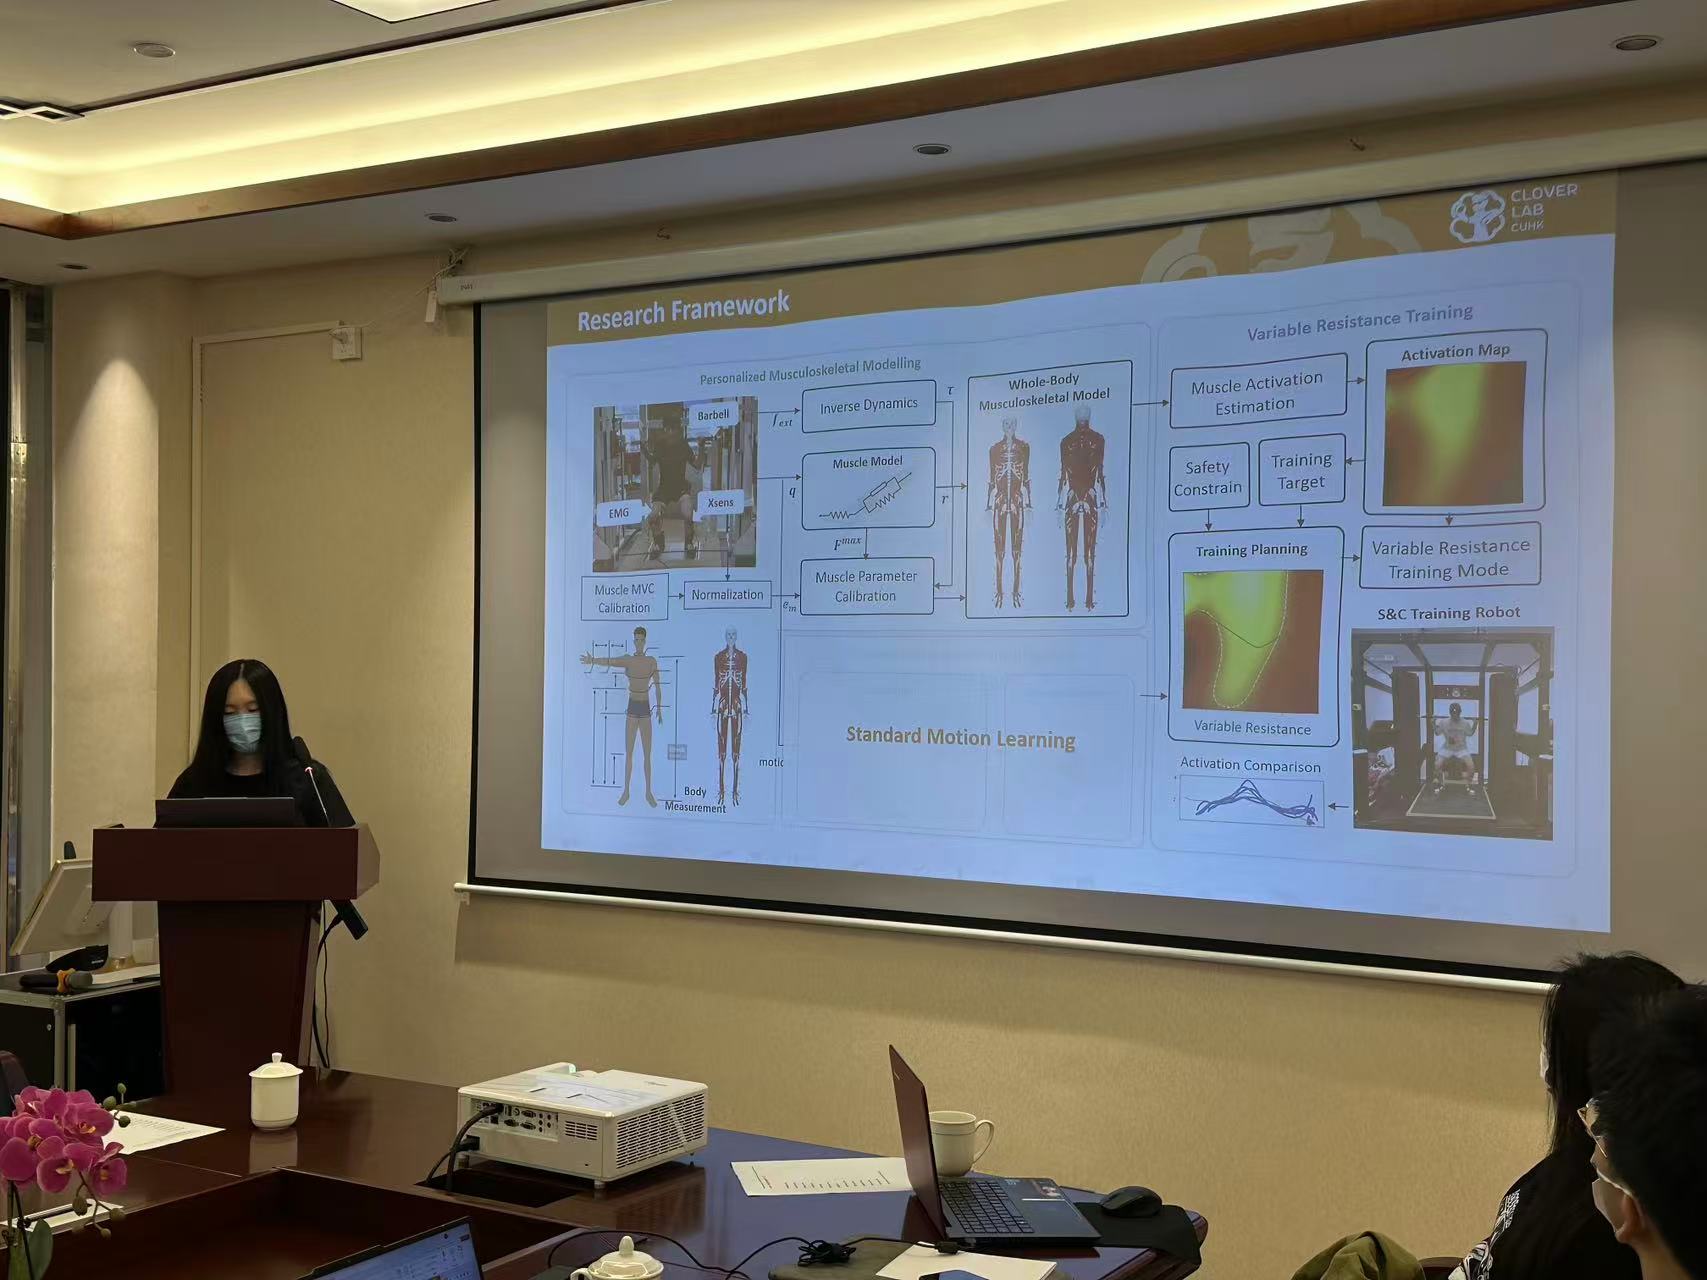
| 11:30-11:45 | Xi WU Personalized Variable Resistance Training Mode for Safe and Efficient Strength and Conditioning Training |
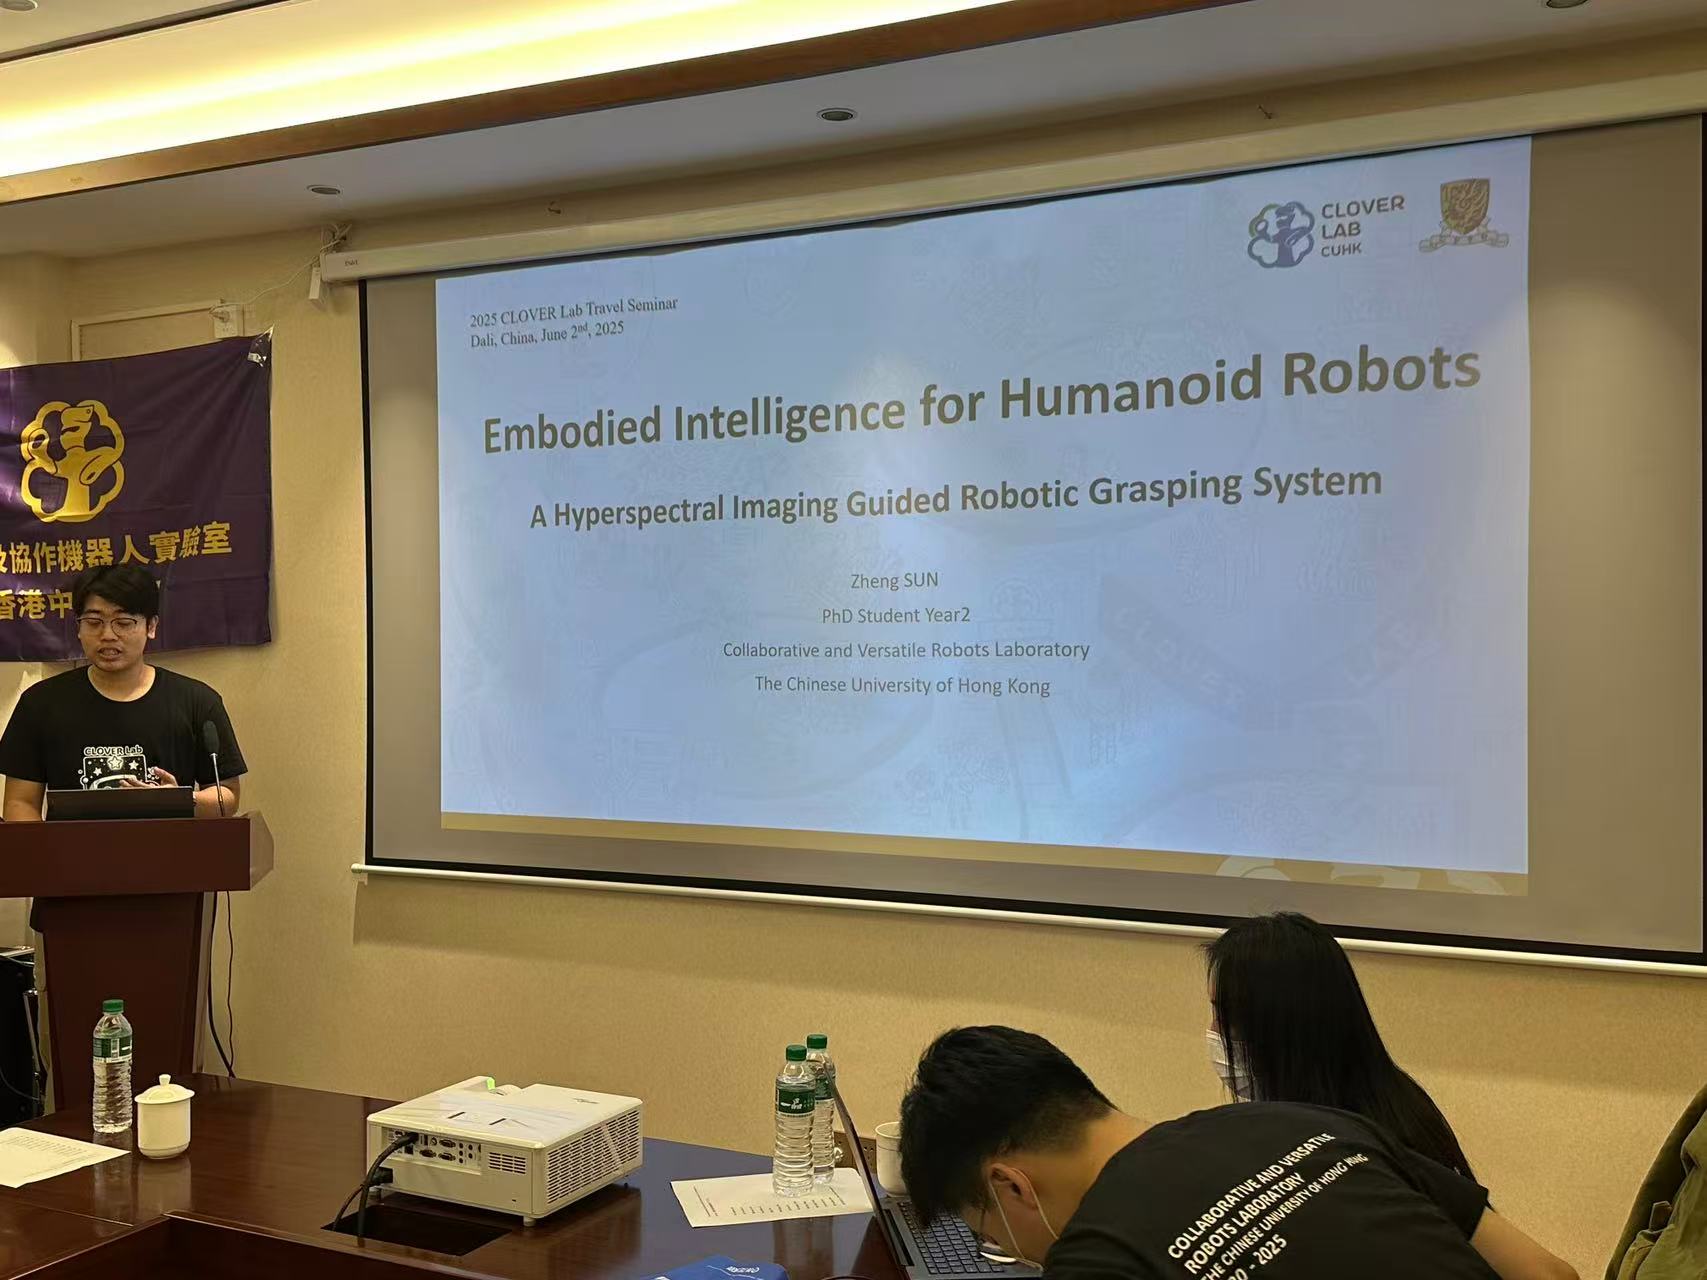
| 11:45-12:00 | Zheng SUN A Hyperspectral Imaging Guided Robotic Grasping System |
| 12:00-13:00 | Lunch Time |
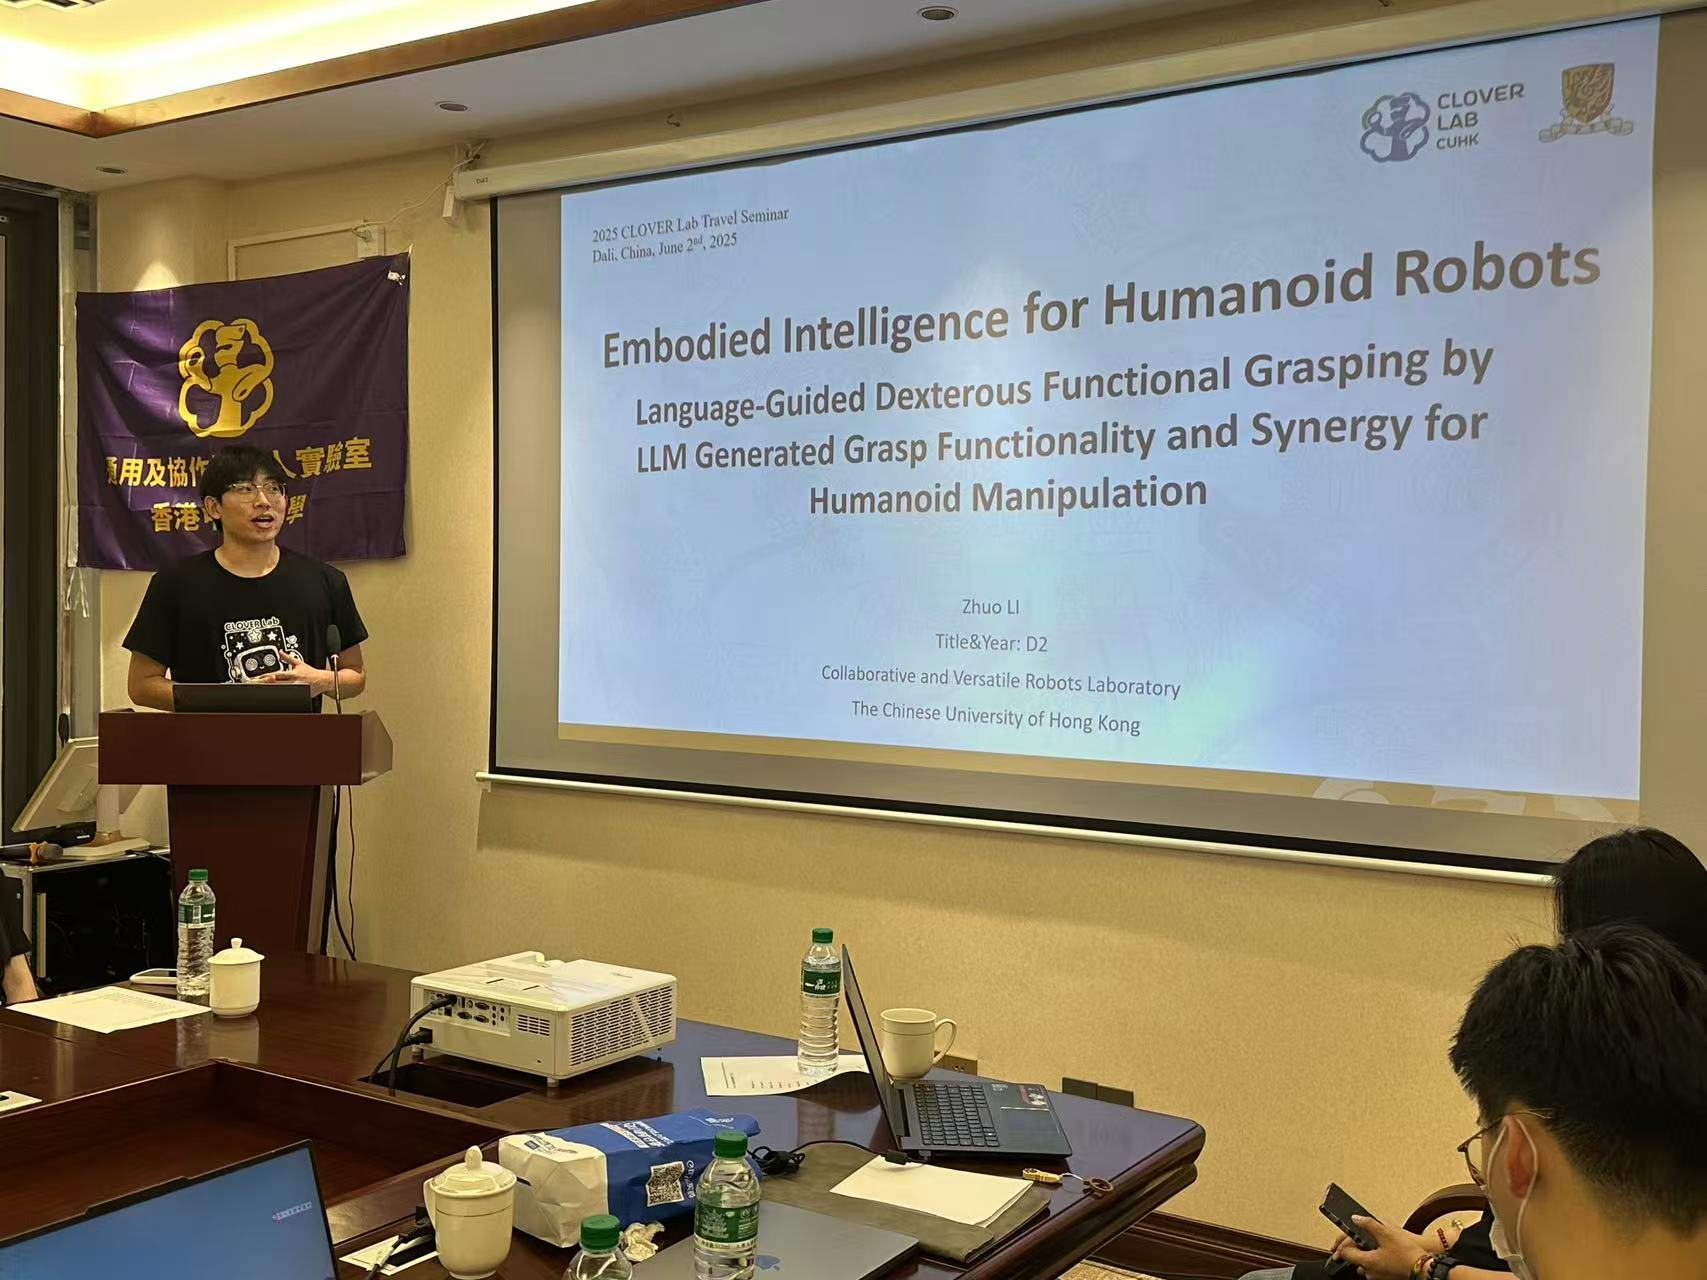
| 13:00-13:15 | Zhuo LI Language-Guided Dexterous Functional Grasping by LLM Generated Grasp Functionality and Synergy for Humanoid Manipulation |
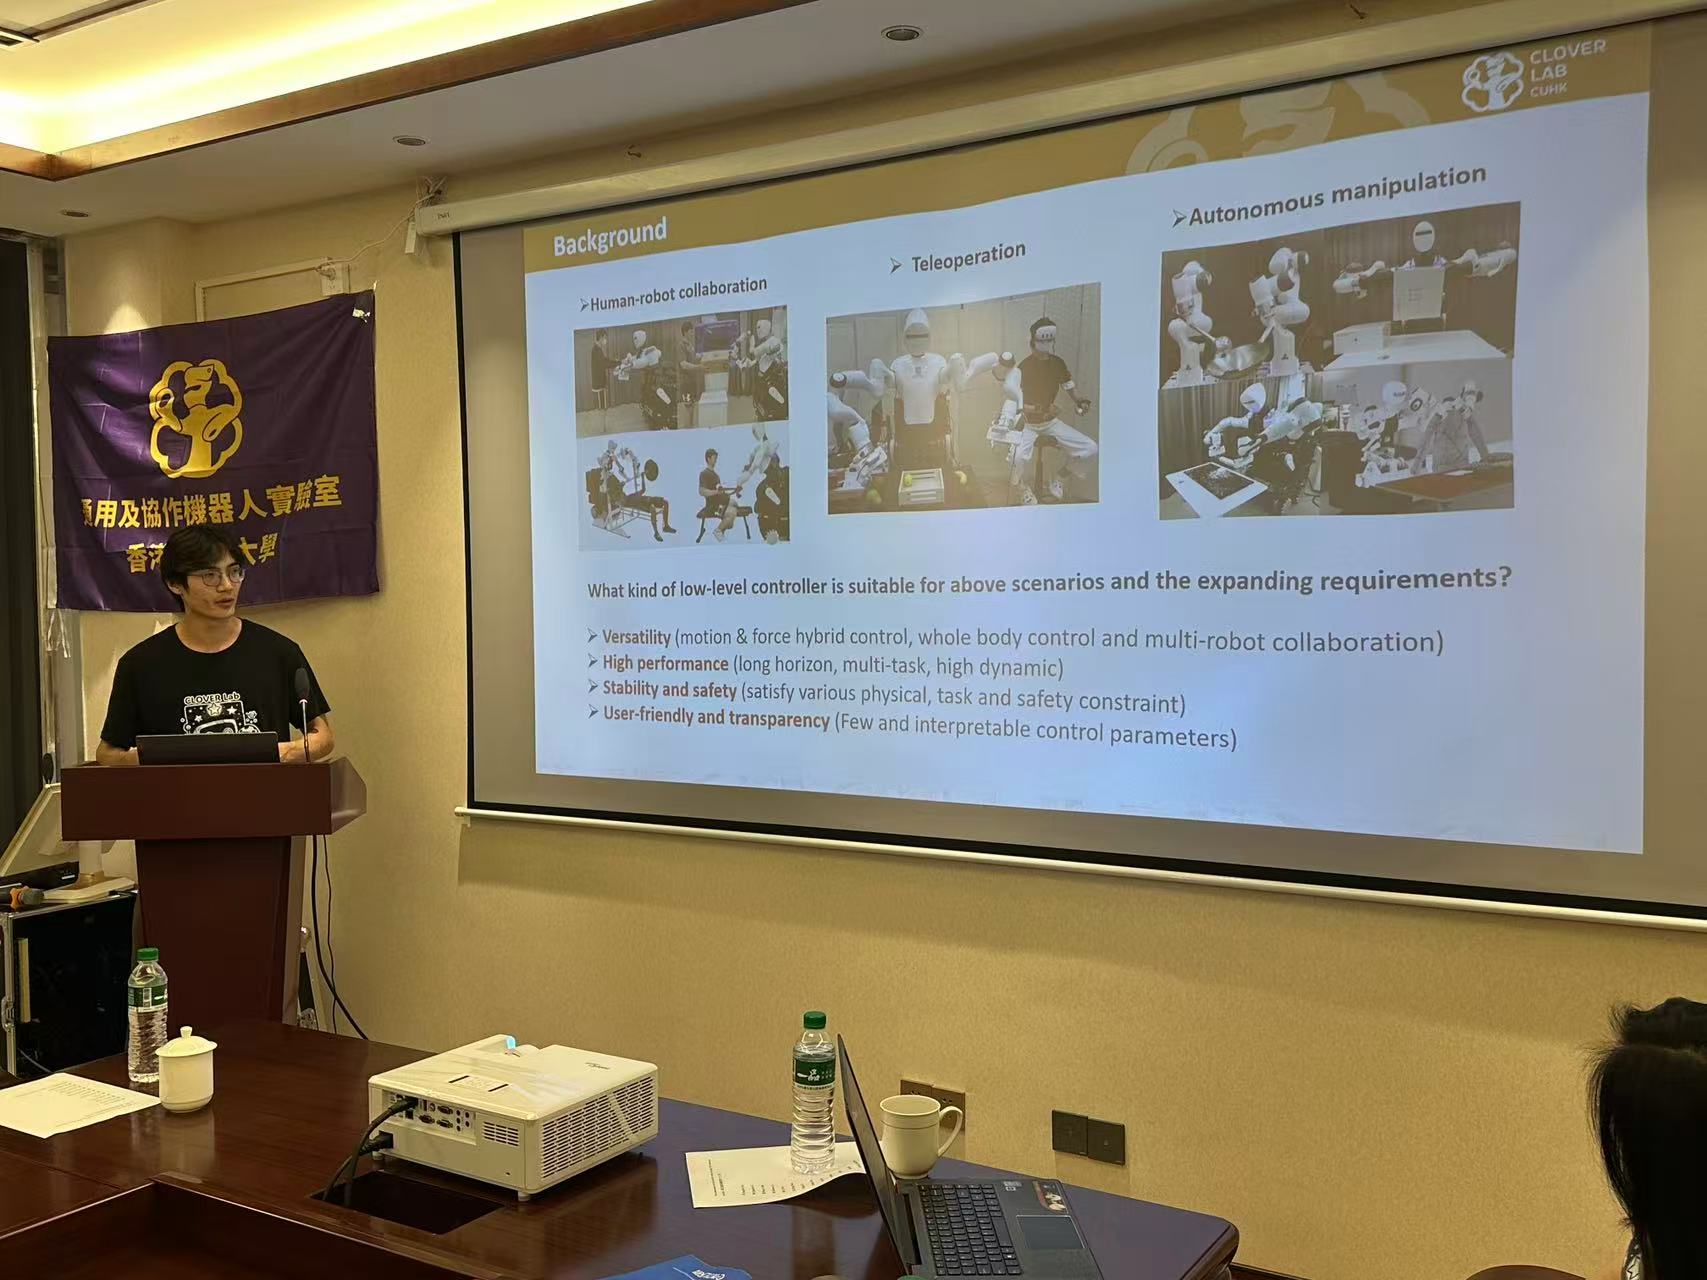
| 13:15-13:30 | Yiming CHEN Unified Model Predictive Interaction Control (MPIC) Impedance Matching and Constraint Optimization |
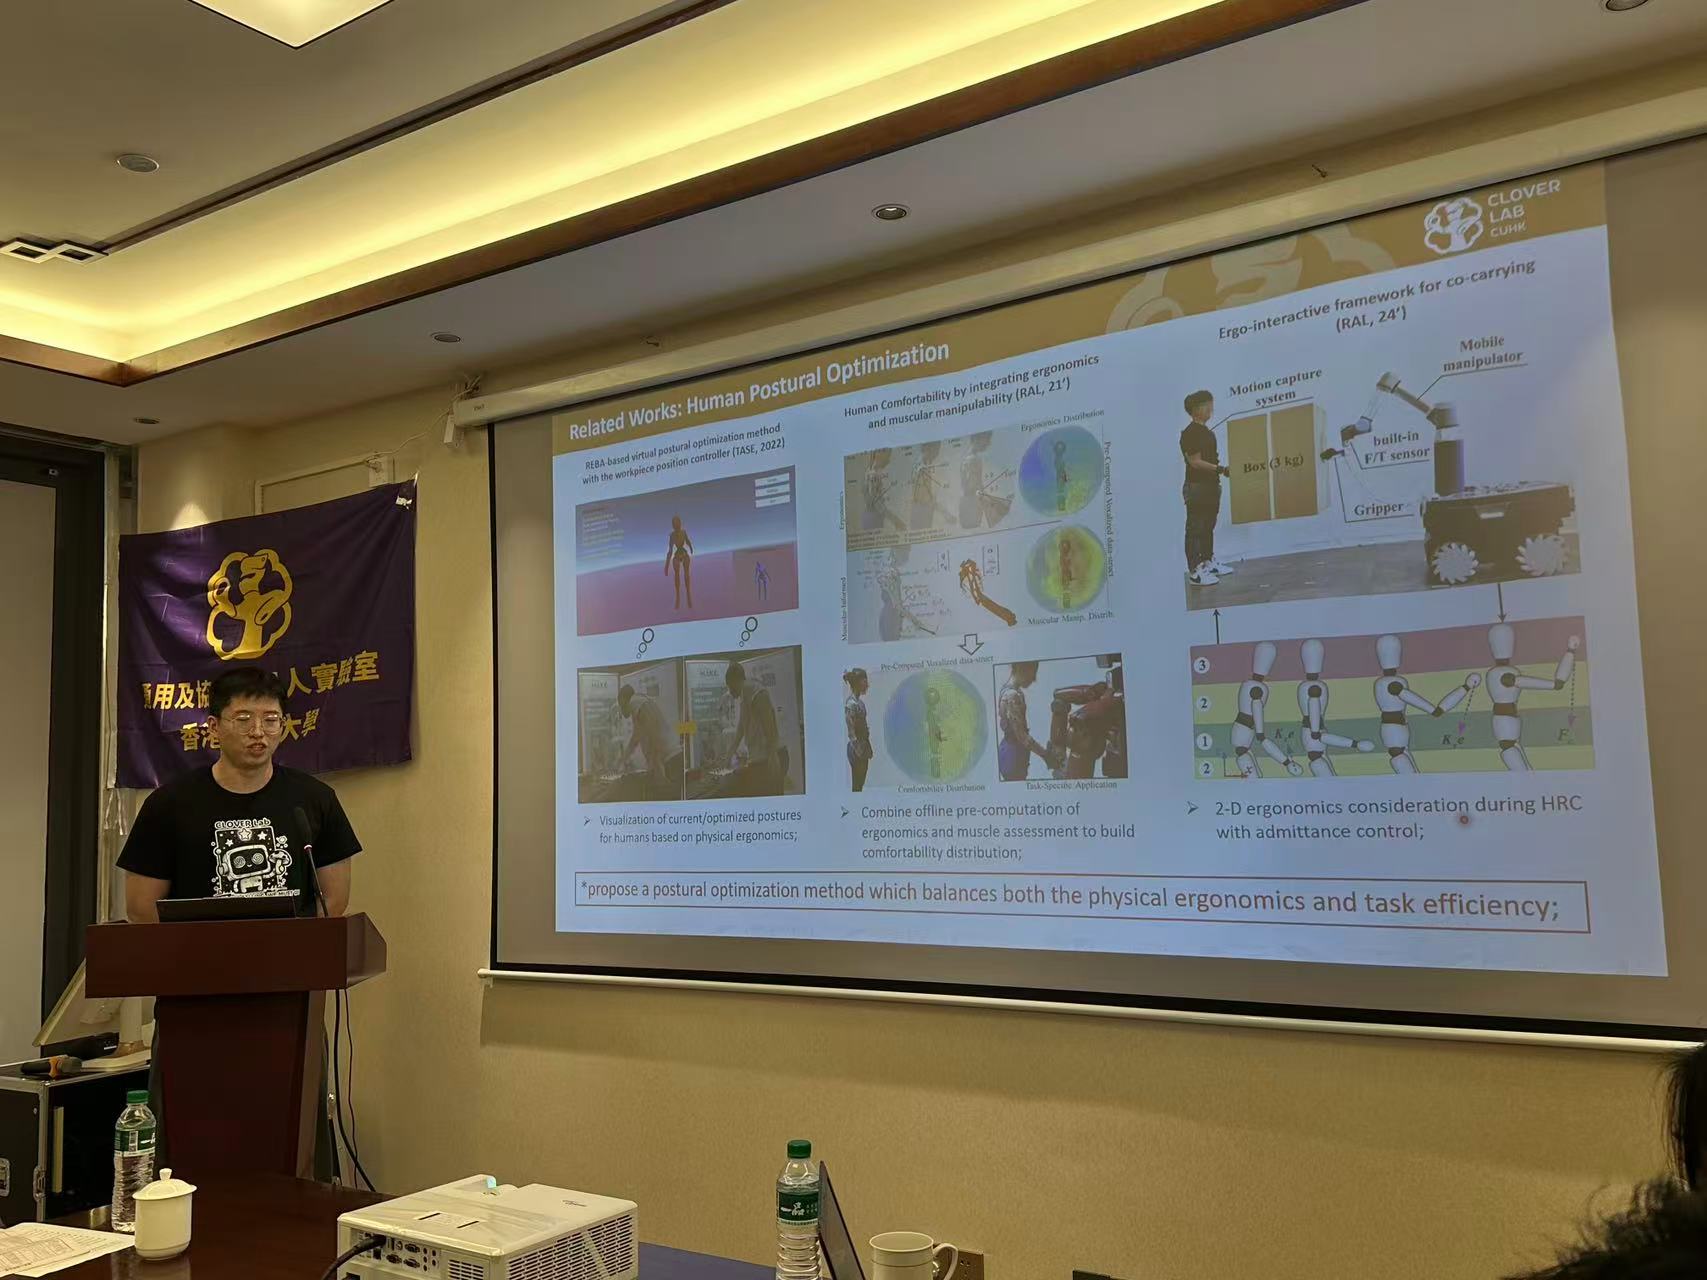
| 13:30-13:45 | Chenzui LI Ergonomics-Oriented Human Upper Limb Postural Optimization and Robot Motion Planning for pHRI in Logistics Scenarios |
| 13:45-14:00 | Zixin TANG TELE-LEARN: Human Tele-demonstration Based on Manipulation Skills Learning for Collaborative Dual-arm Mobile Robots |
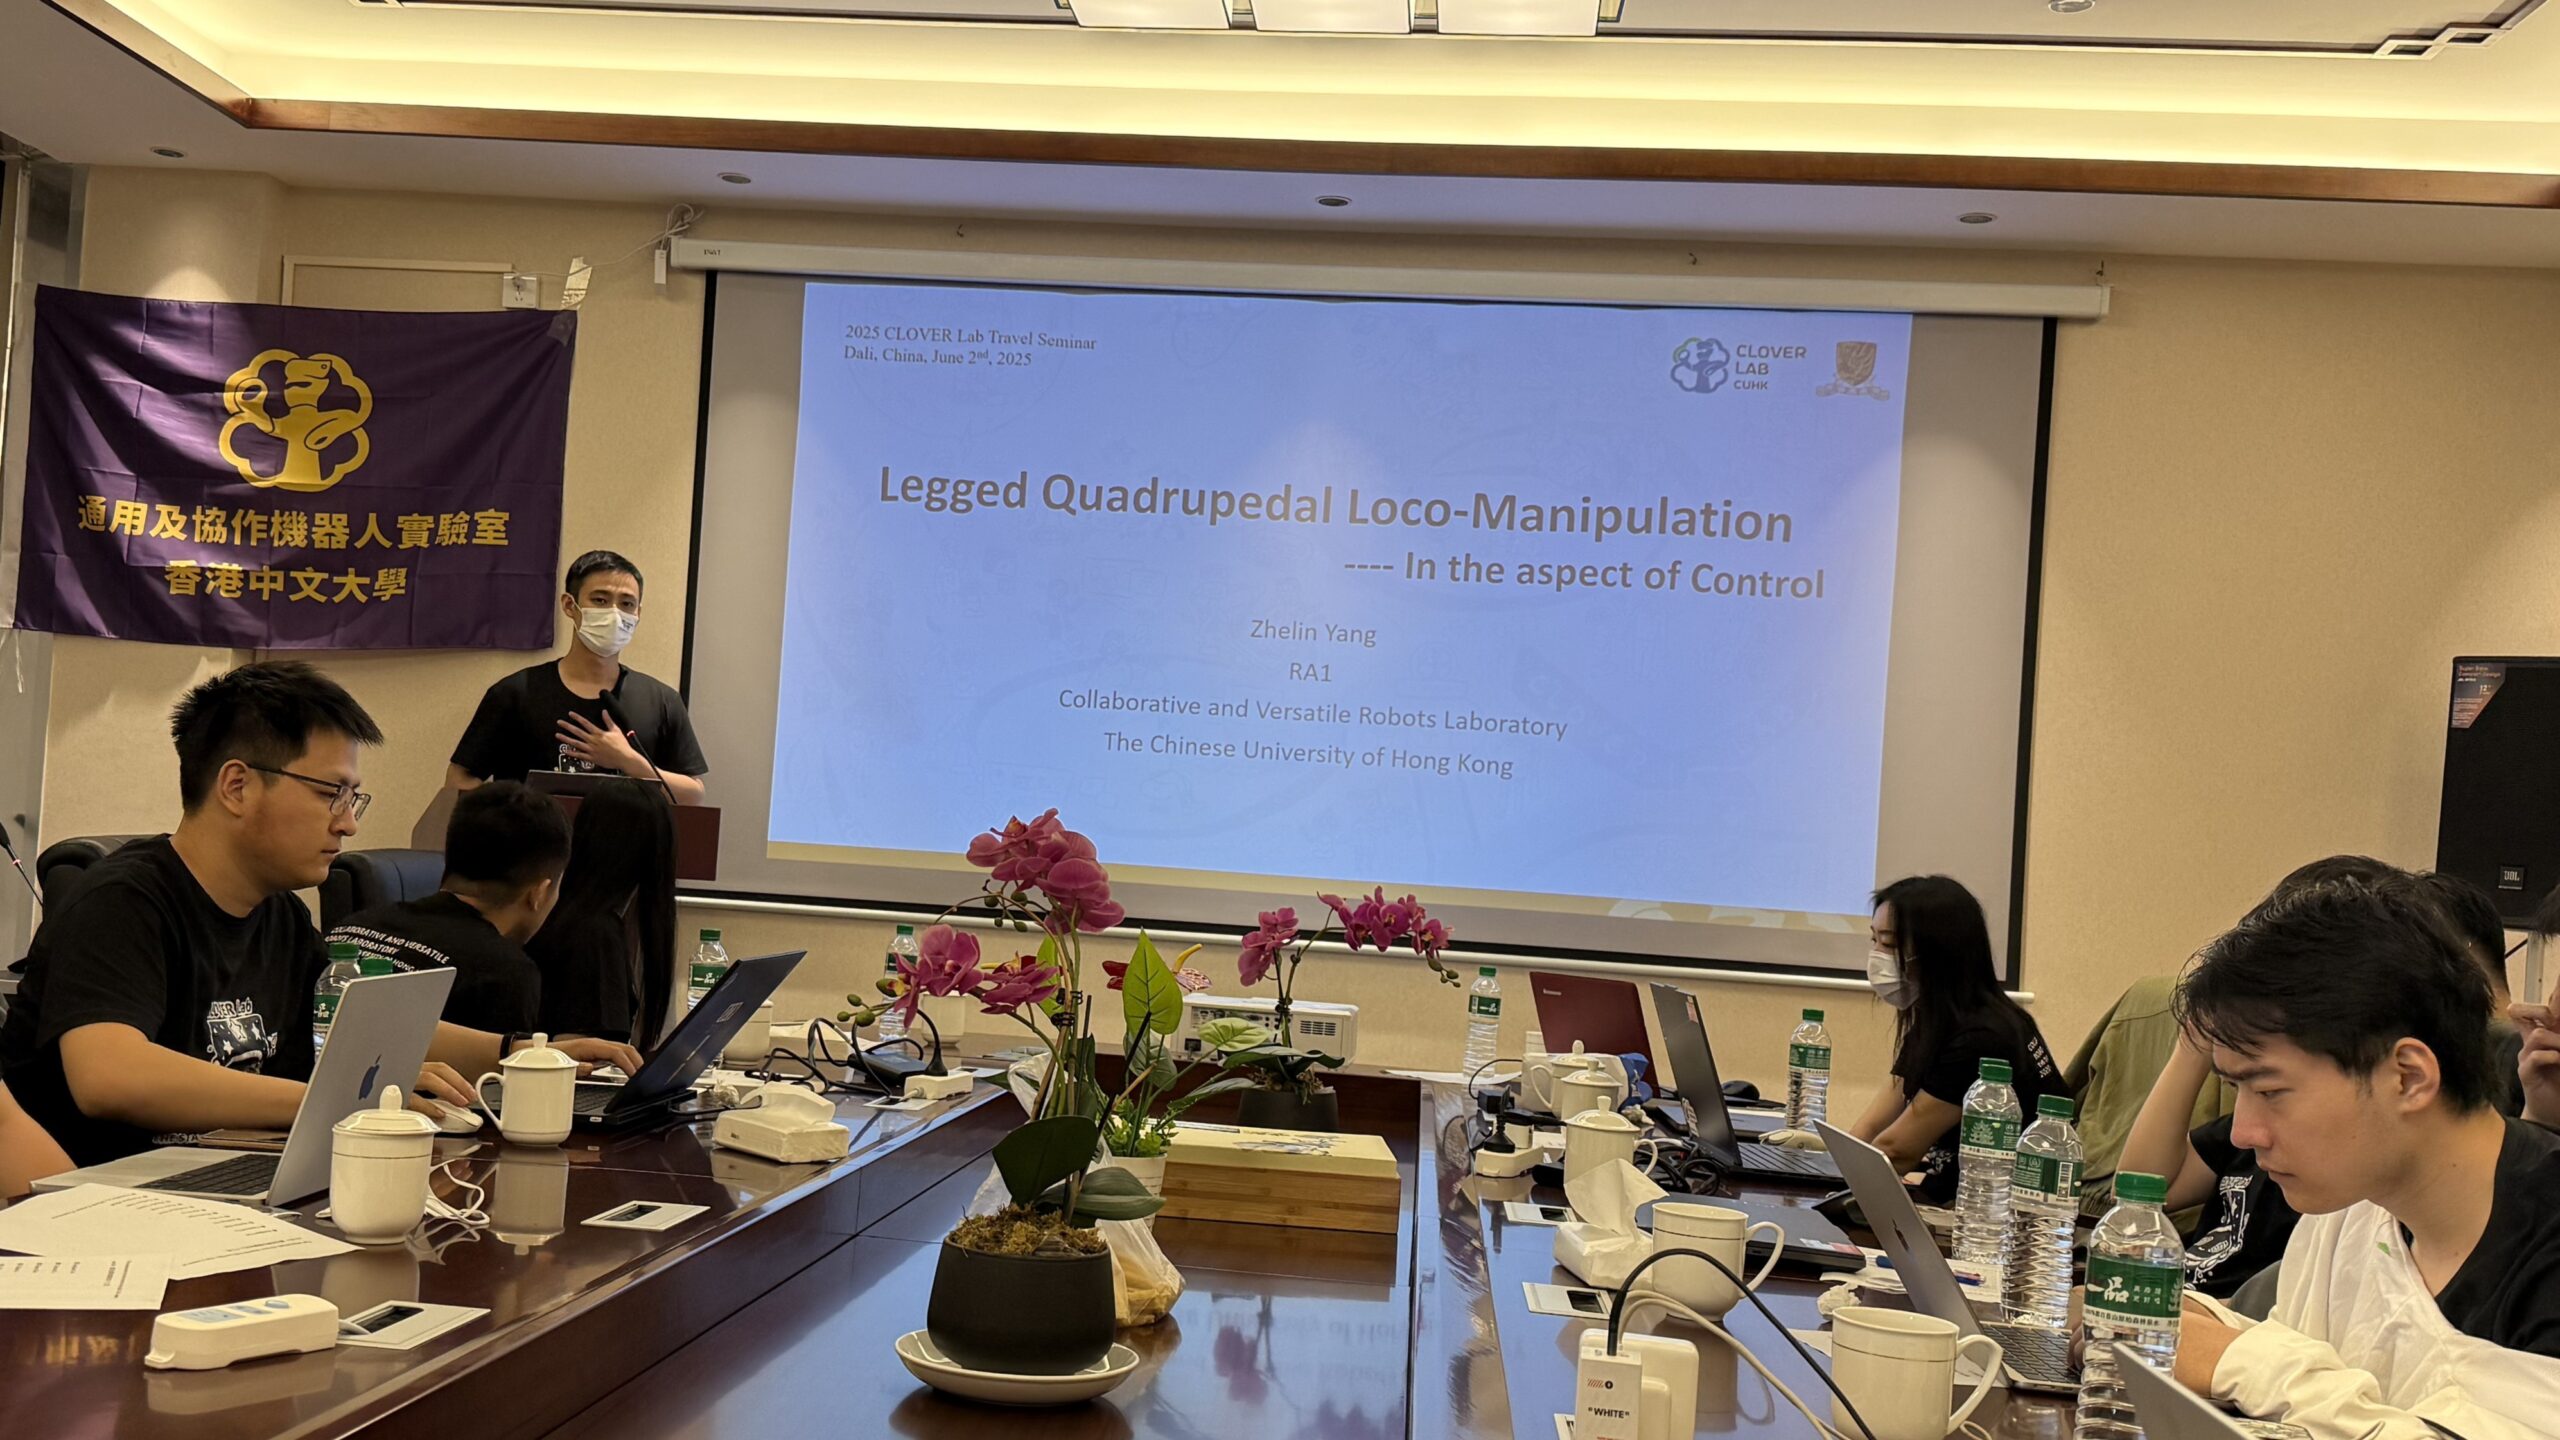
| 14:00-14:15 | Zhelin YANG Legged Quadrupedal Loco-Manipulation—- In the aspect of Control |
| 14:15-14:30 | Yuchen YAN Localization and Planning of a UAV for Rapid Complete Coverage Bridge |
| 14:30-15:00 | Coffee Break |
| 15:00-15:15 | Xueqian ZHAI Robot Compliant Skill Learning and Control Methods for Complex Force Interaction Tasks |
| 15:15-16:00 | Prof. Fei CHEN Annual Summary of CLOVER Lab & Workshop Closing Remarks |
| 16:00-21:00 | Banquet |
| June 03 (Tuesday) | |
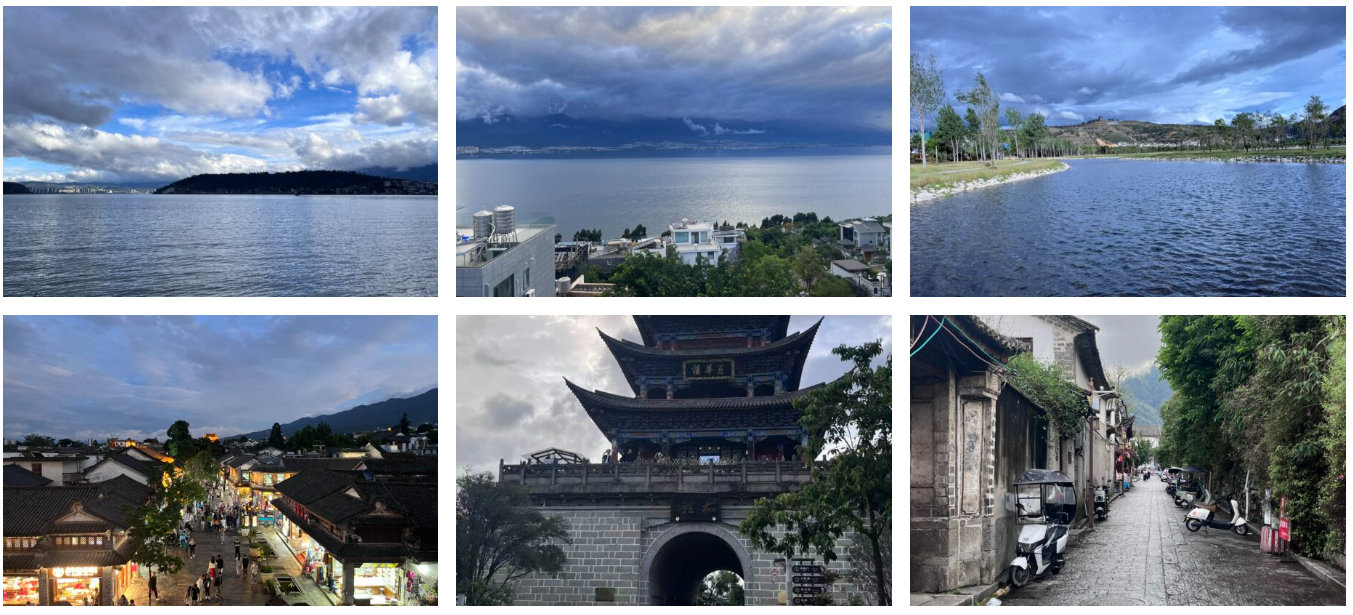
| 10:00-18:00 | Local Culture Experience Dali Ancient Town |
| June 04 (Wednesday) | |
| 9:00-12:00 | Local Culture Experience Kunming Flower Market |
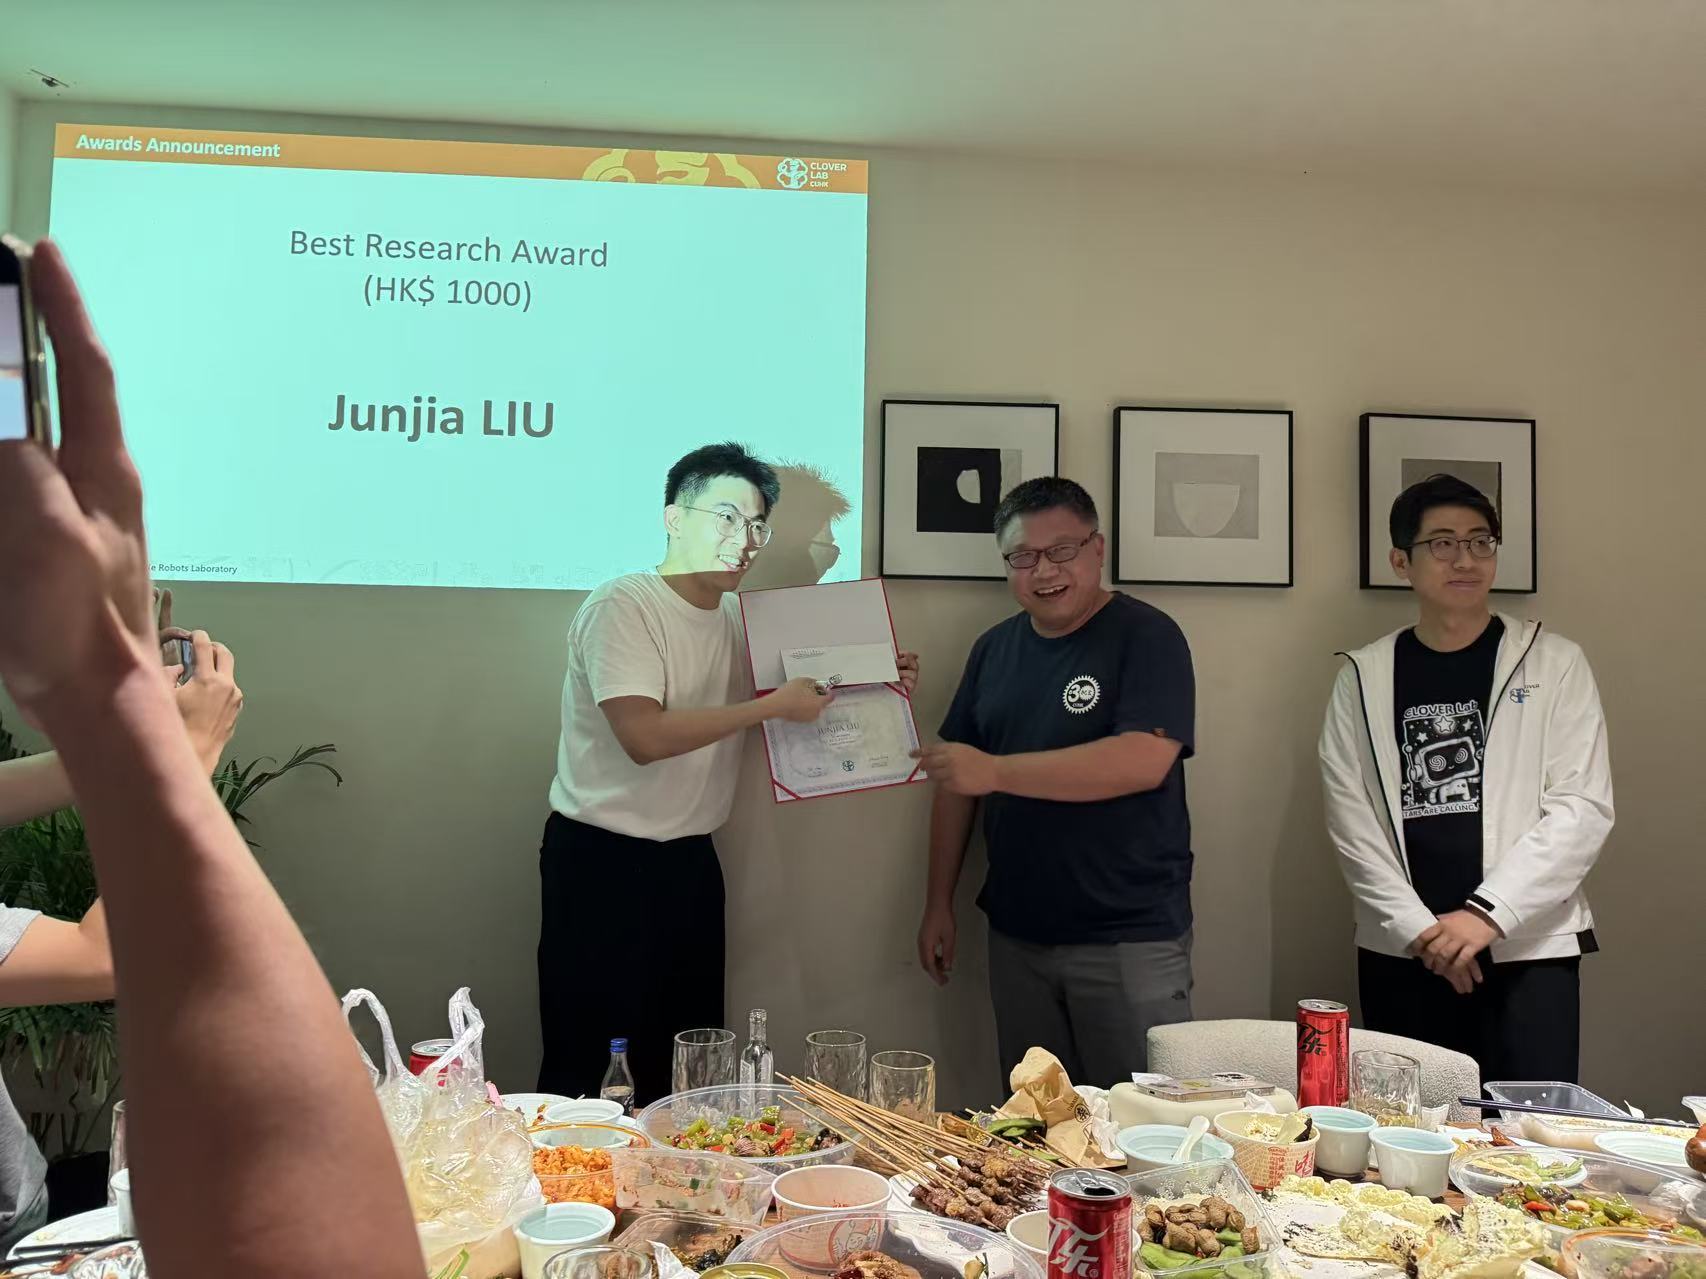
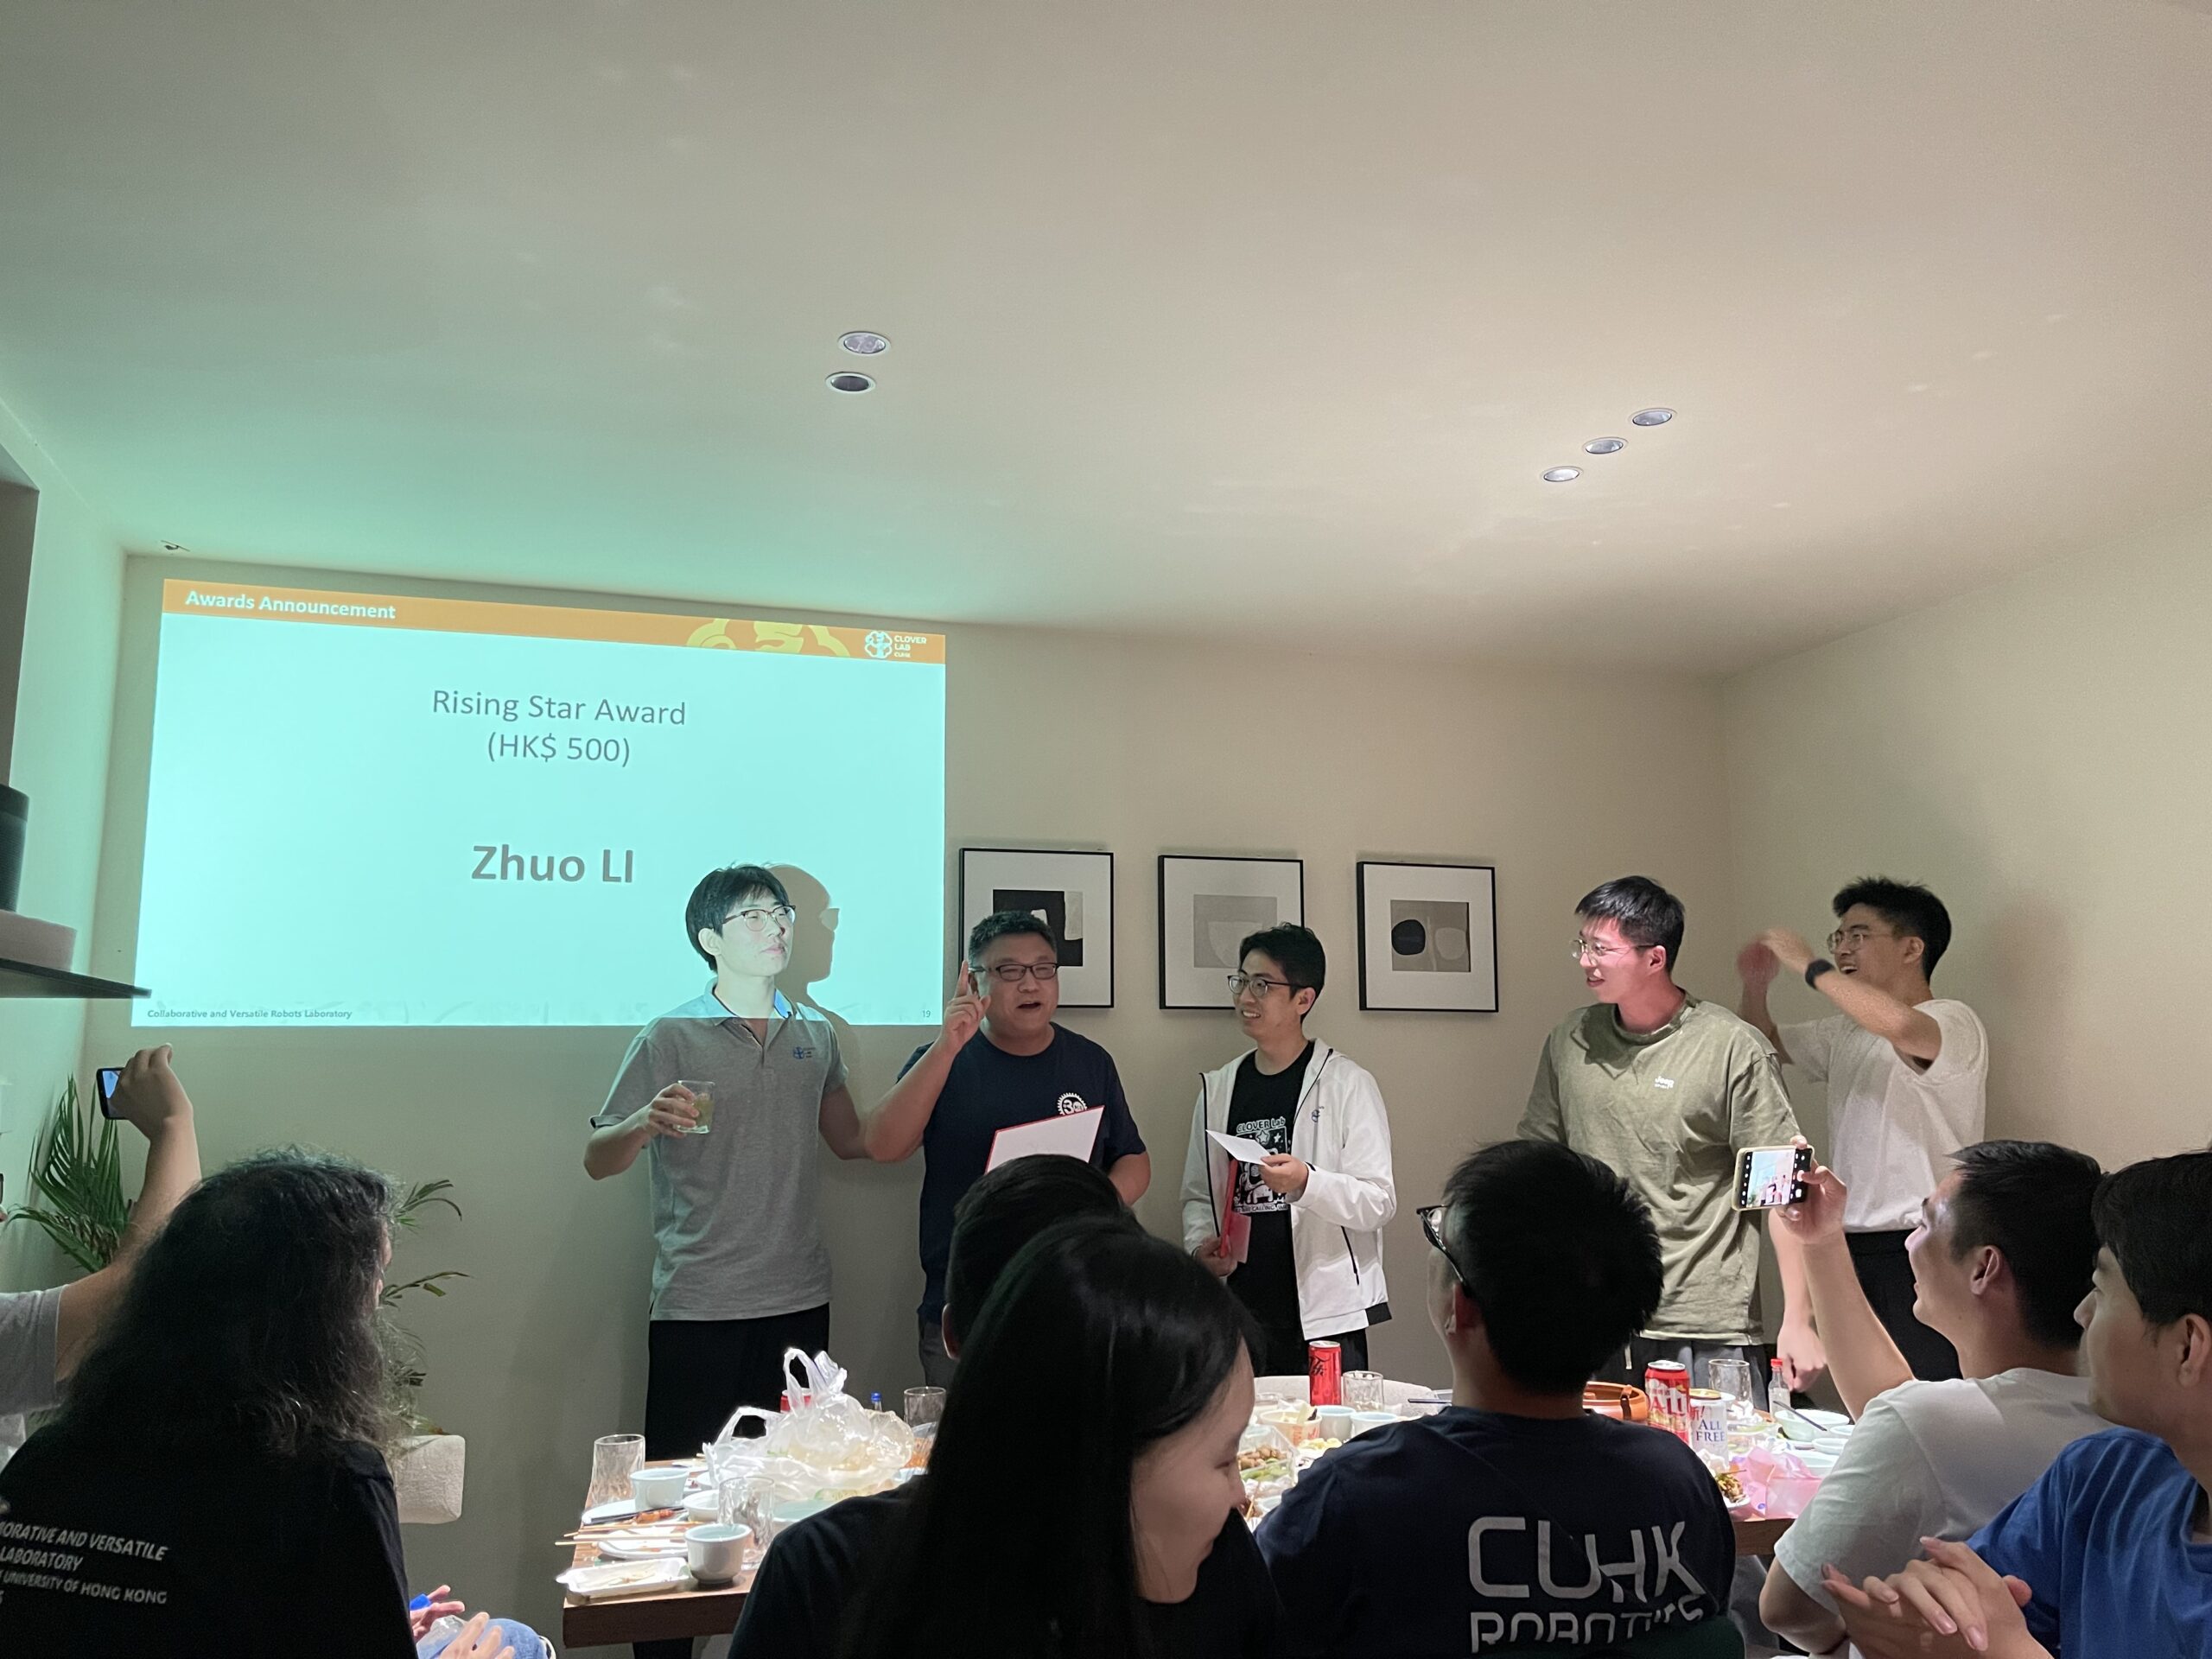
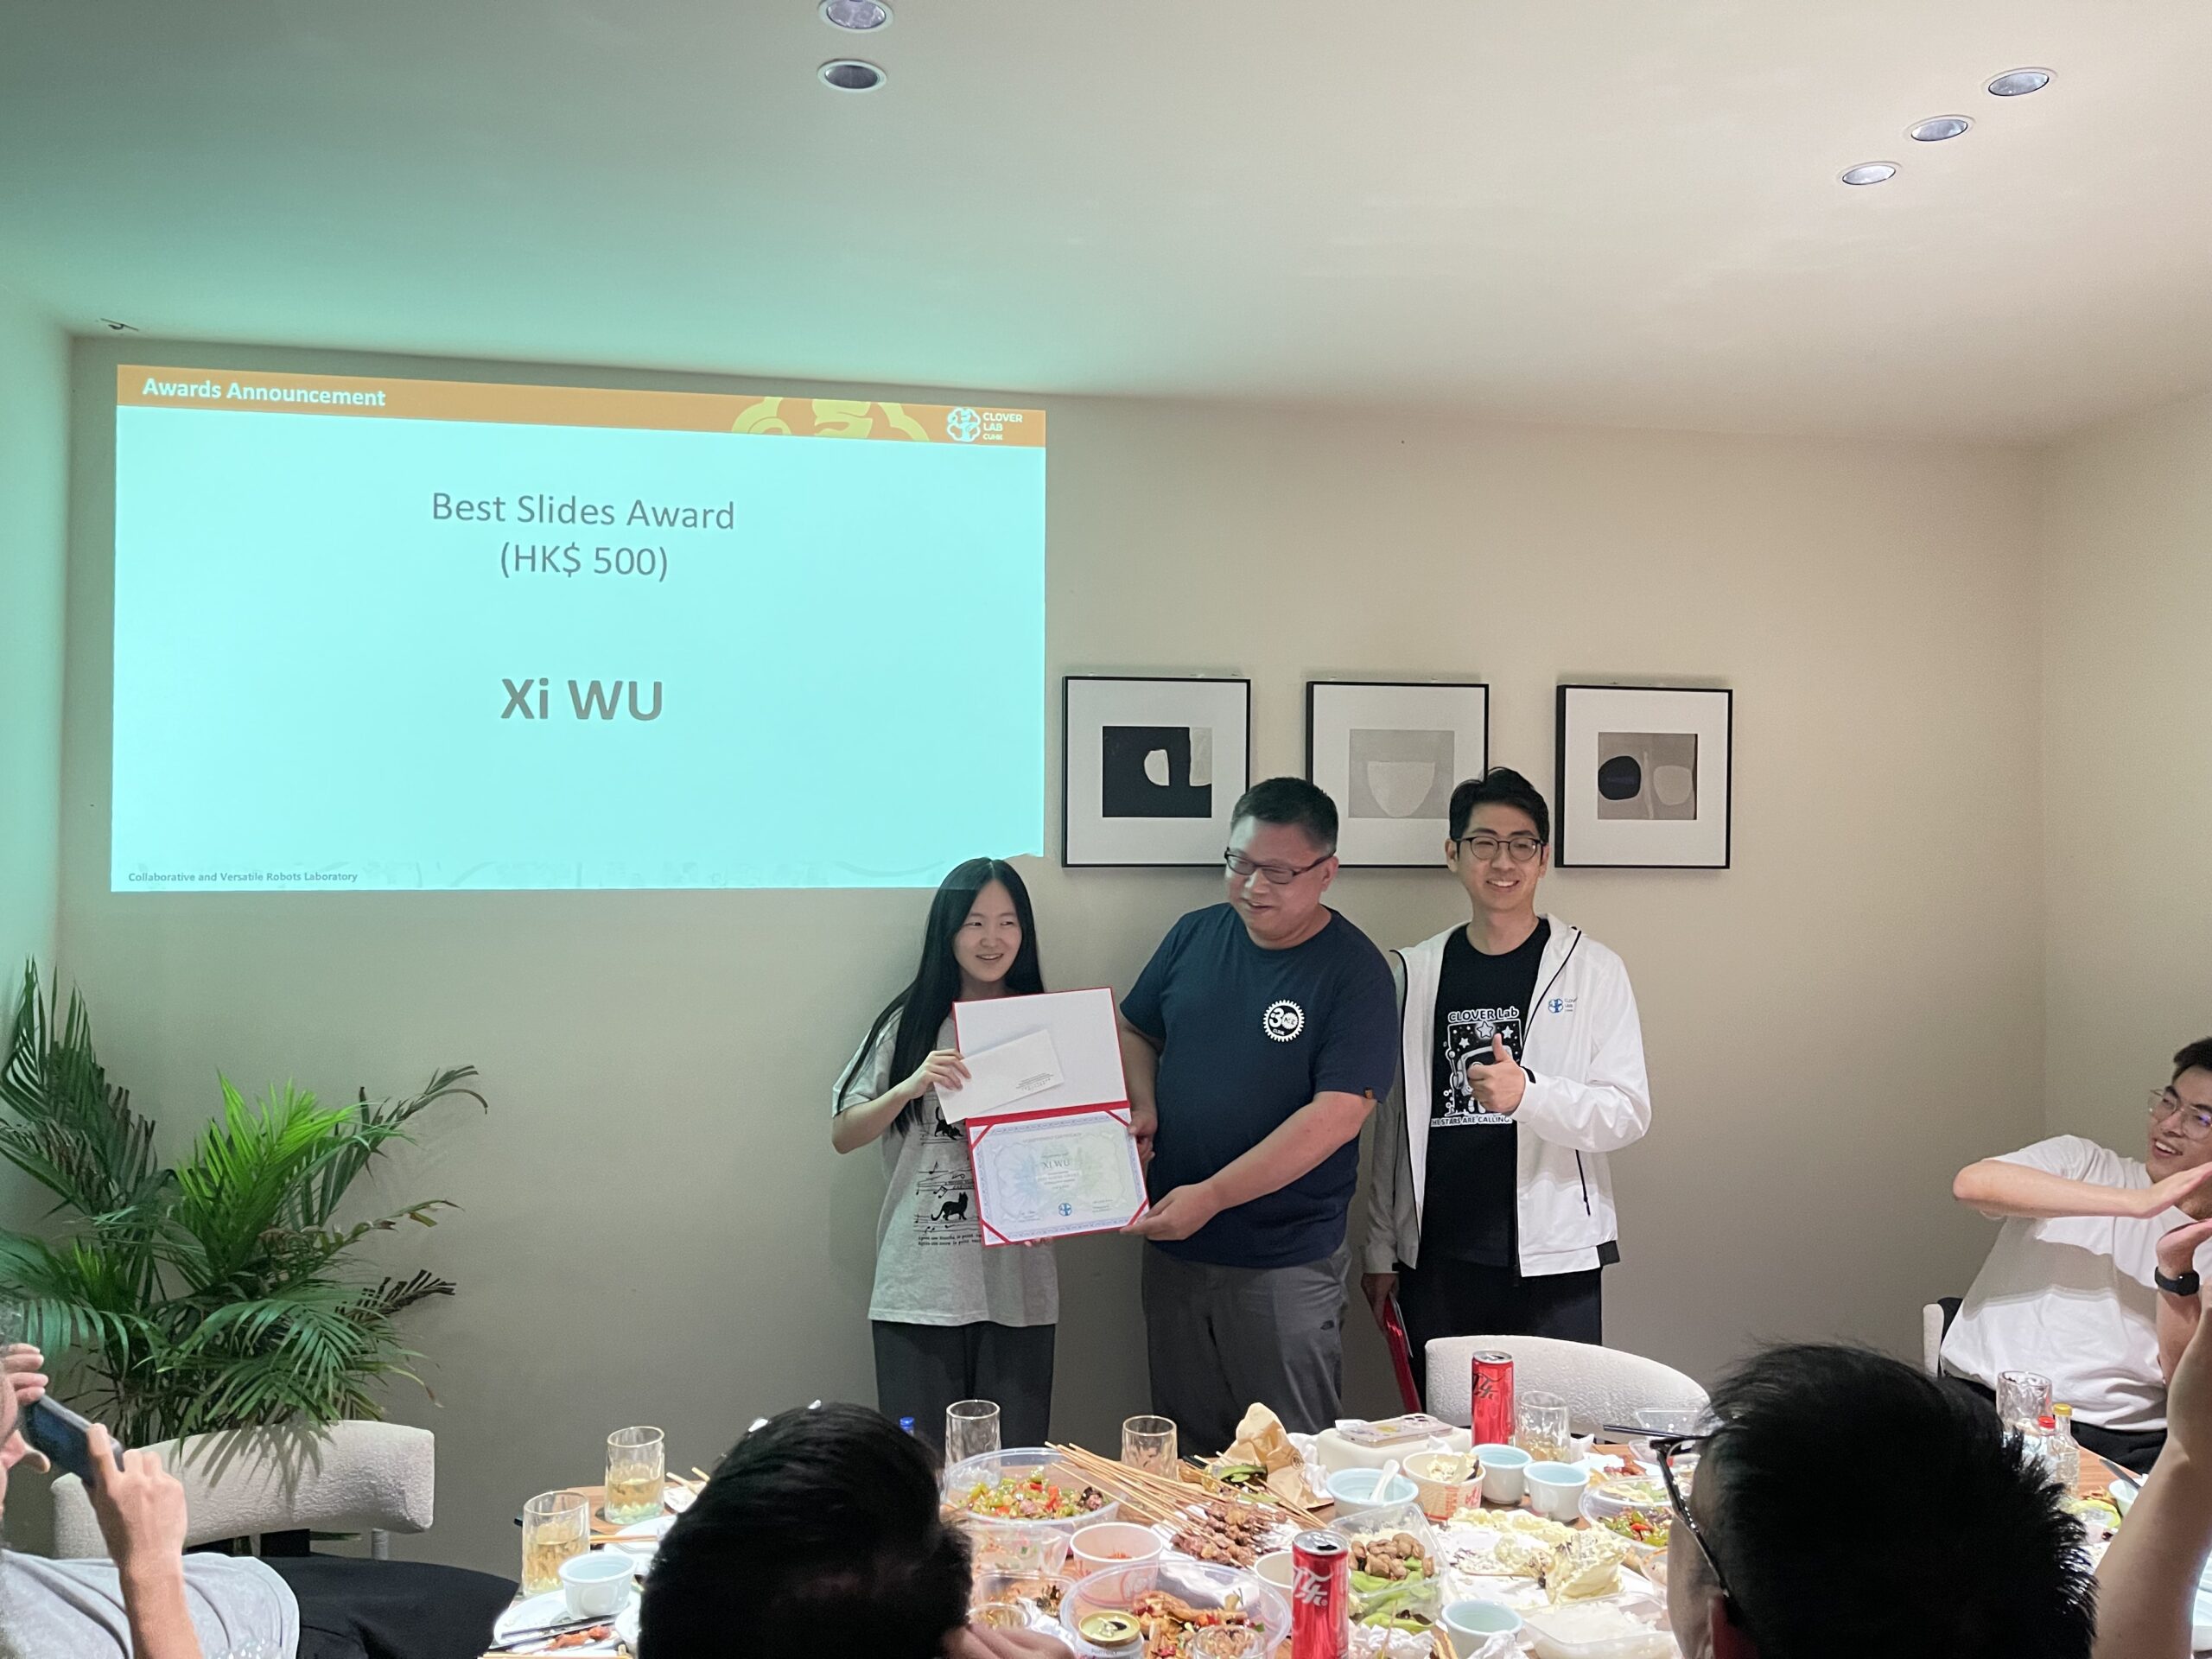
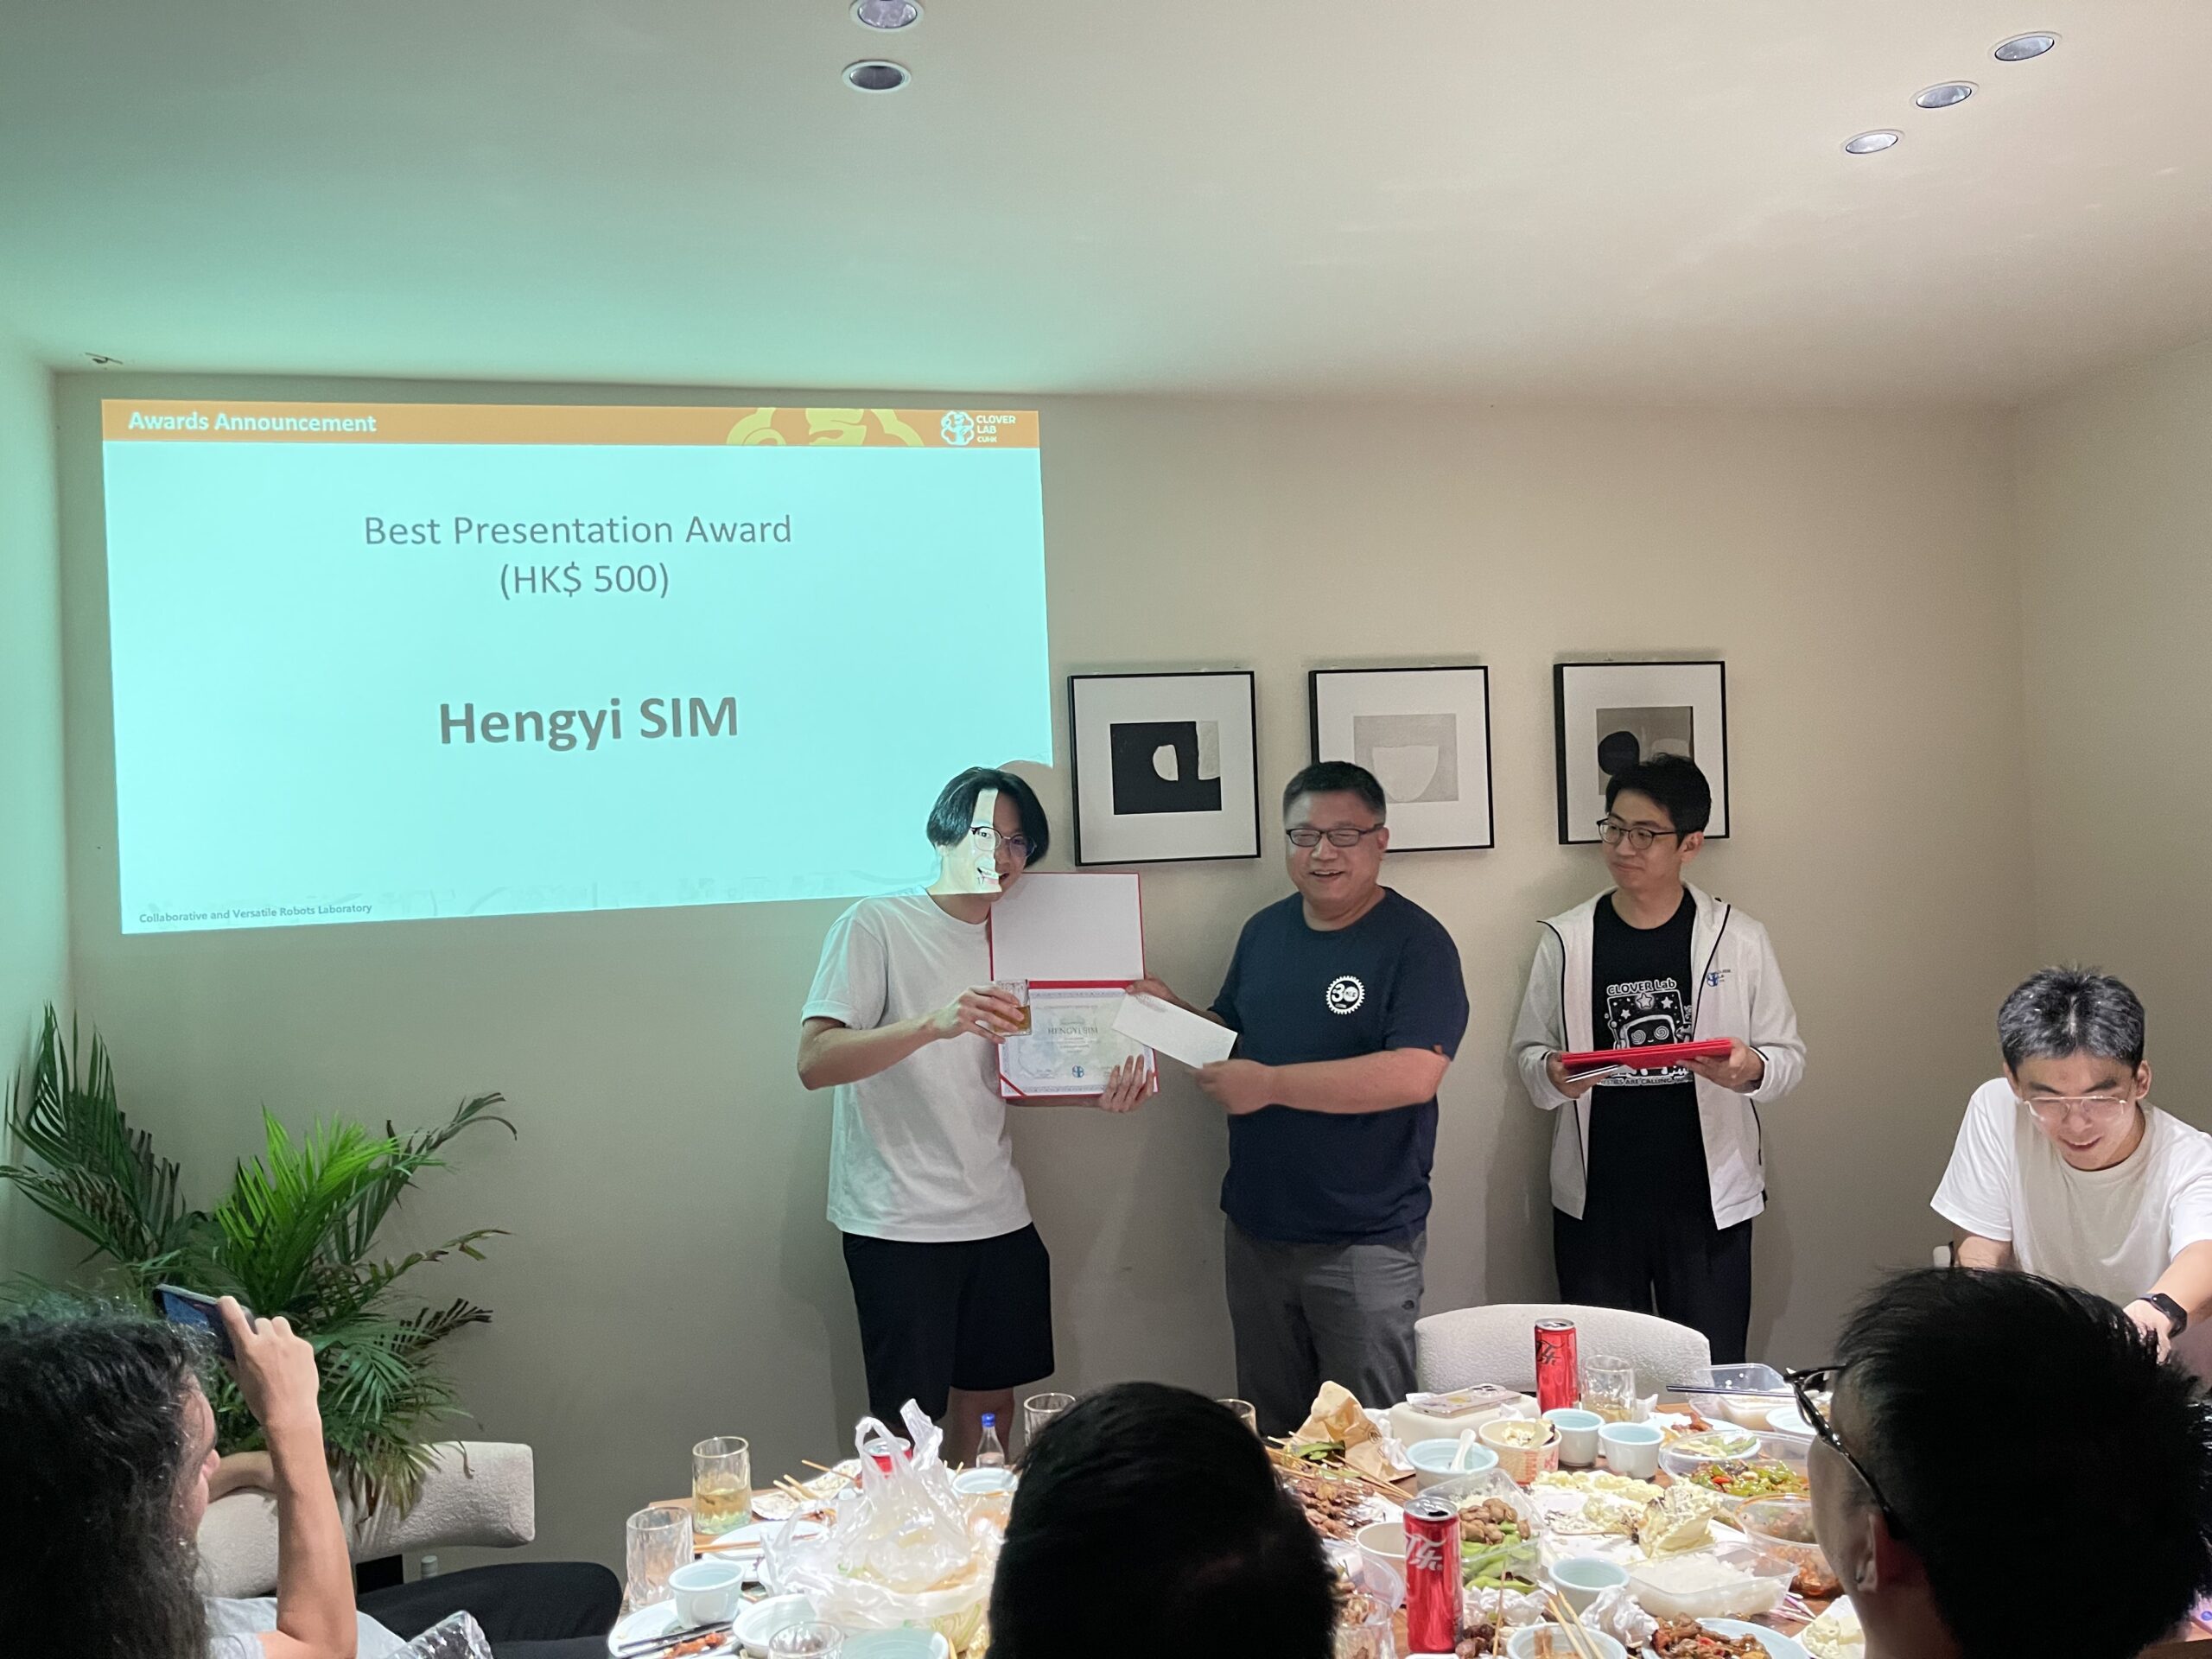
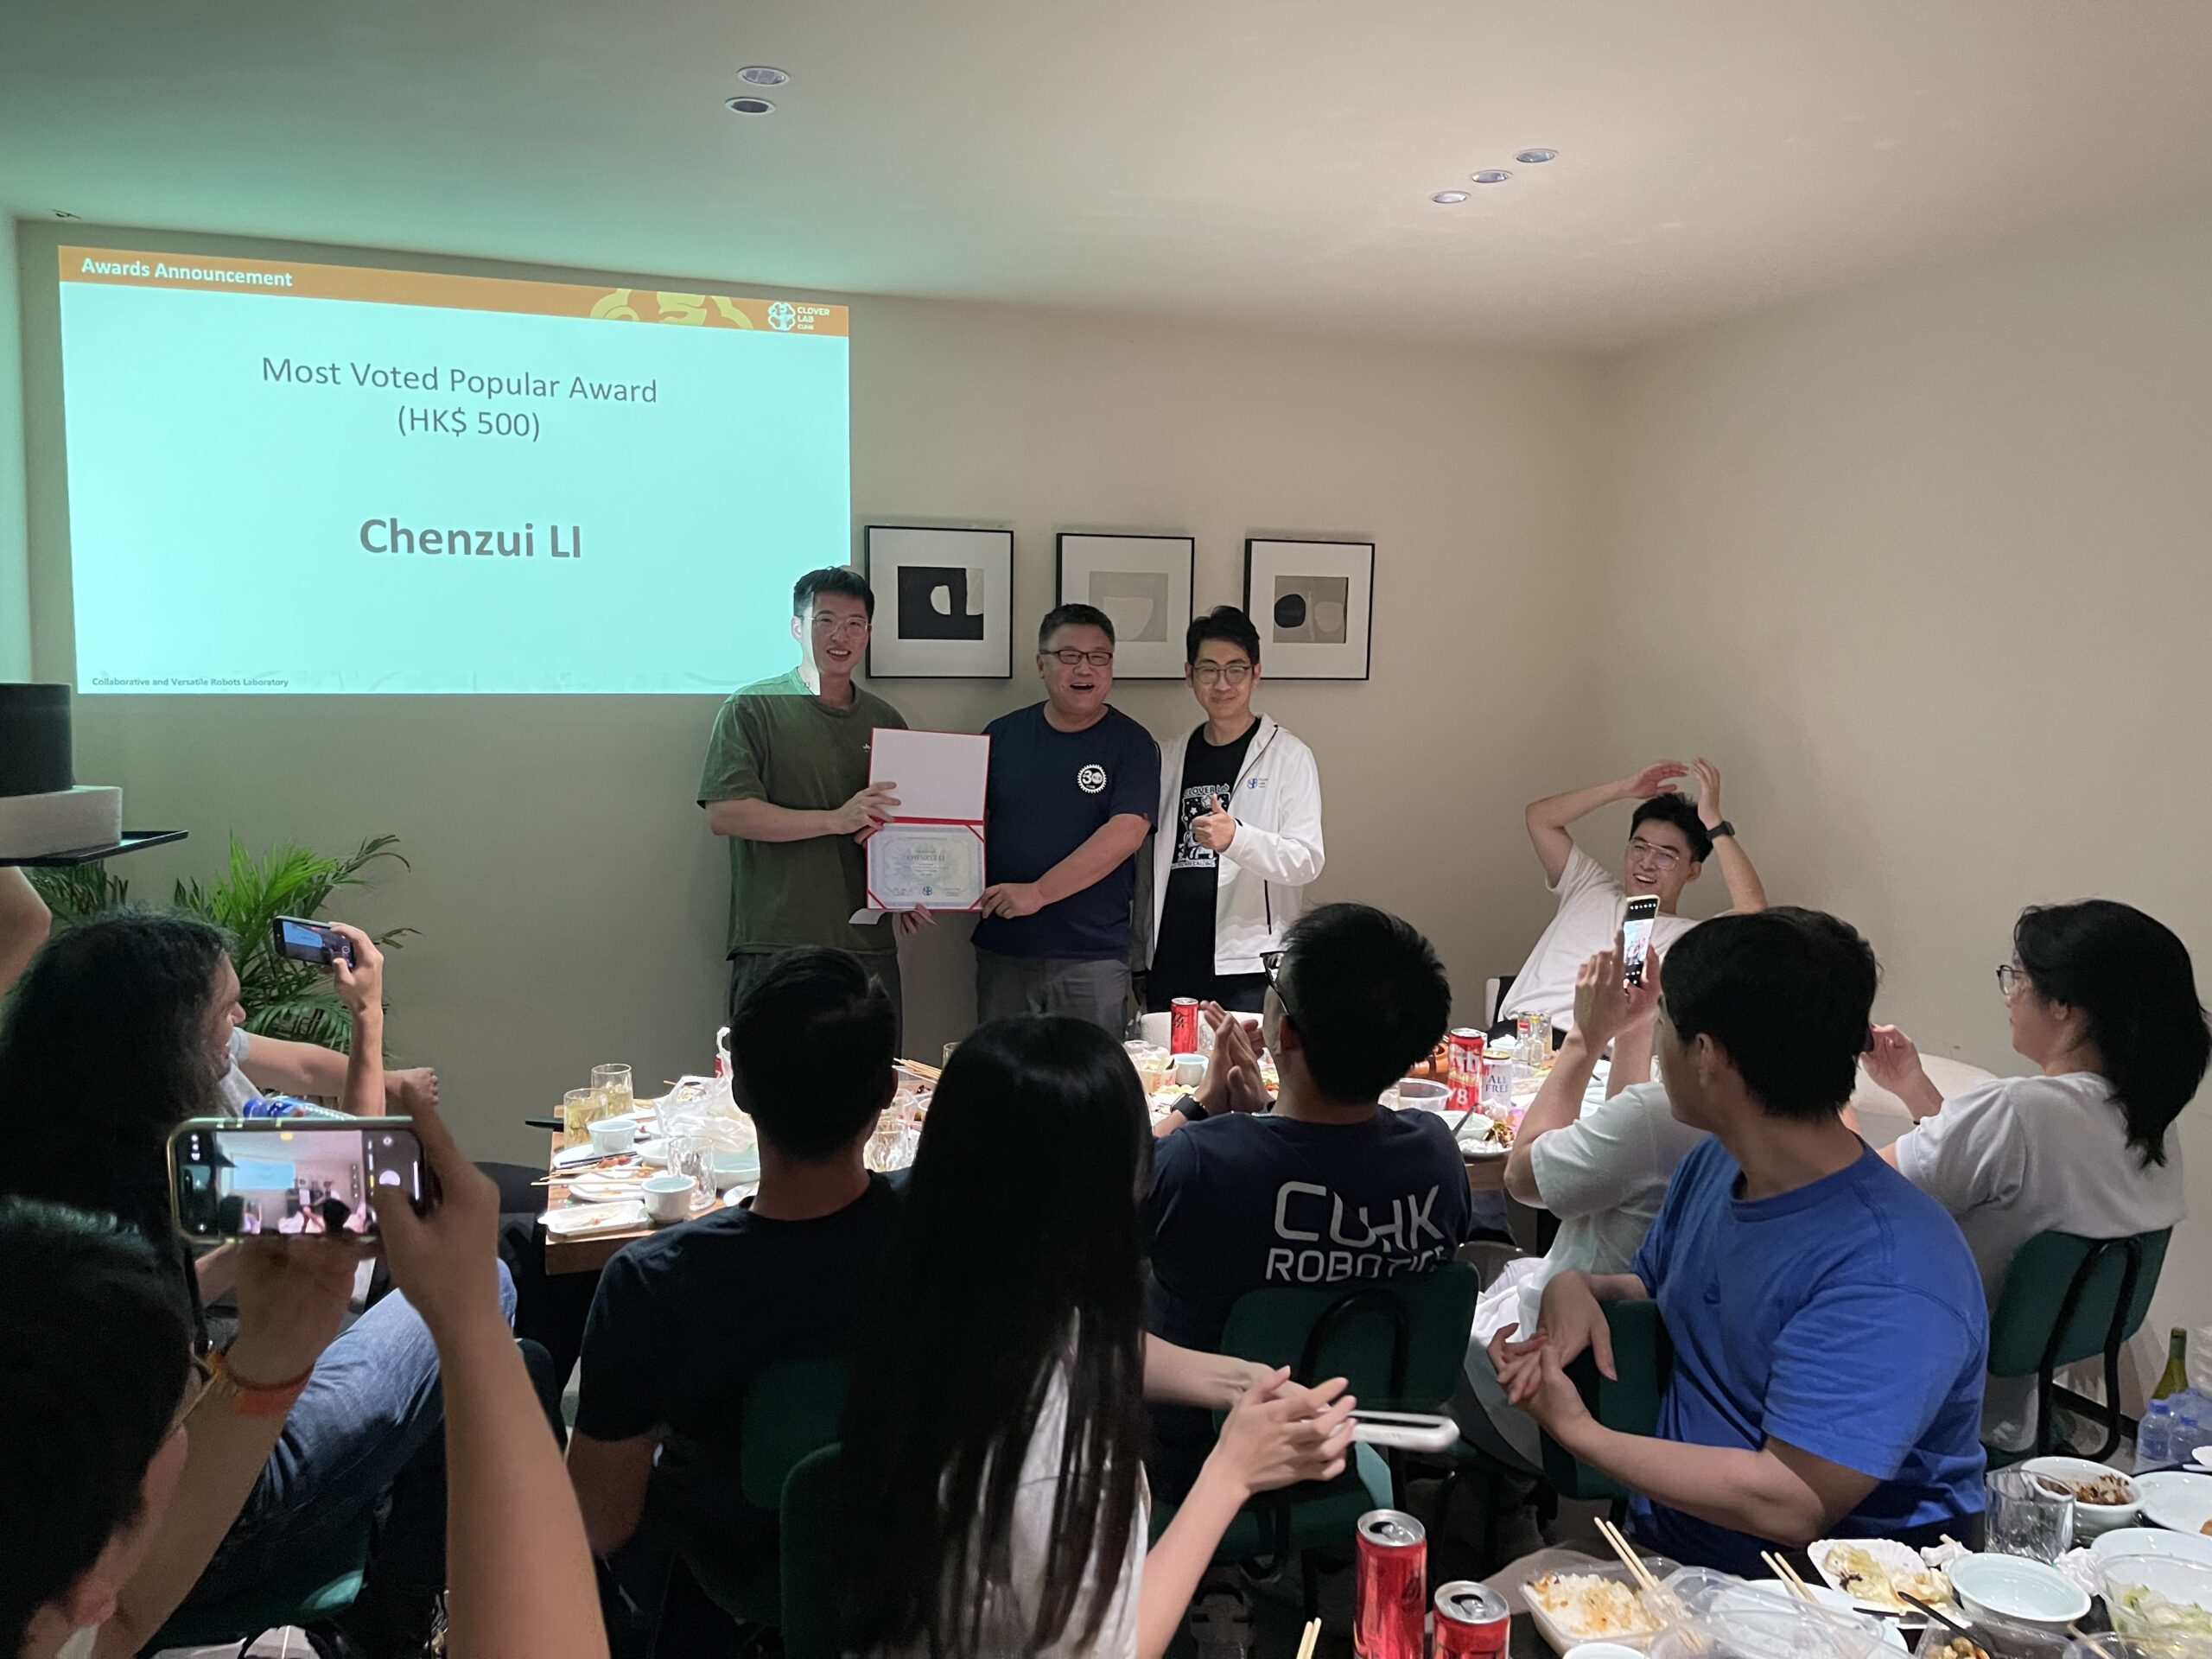
CLOVER Lab Annual Awards
Award Committee Prof. Fei CHEN Dr. Zhipeng DONG Dr. Tao TENG Dr. Quentin ROUXEL | Awardee of Year 2024 - 2025
|
Workshop Swag
 | 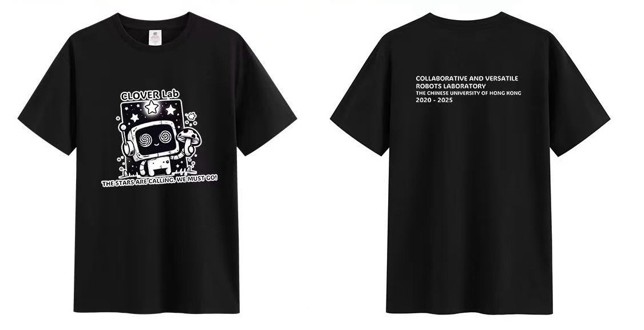 |
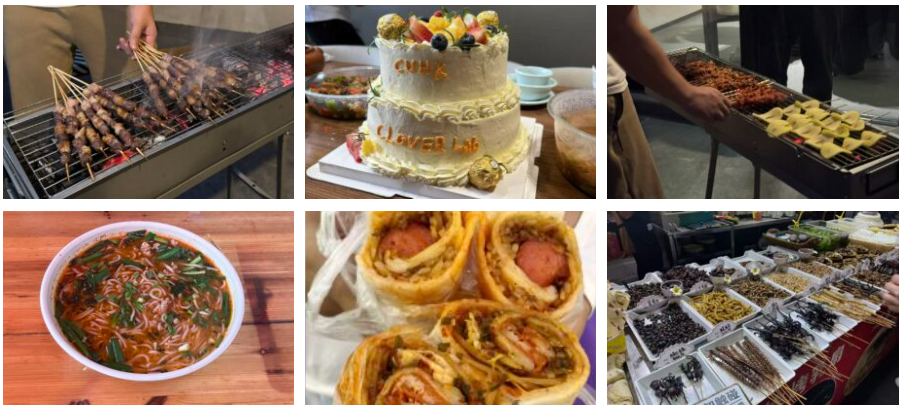
Activity Gallery
Sponsor